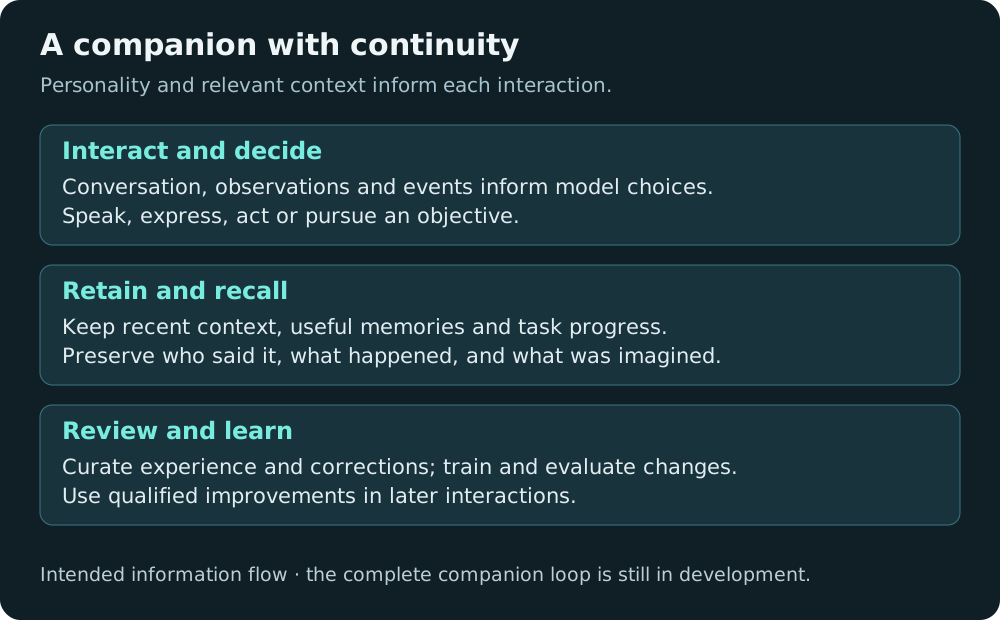
Ainekio as a Companion: Personality, Memory and Learning
Meet the robot familiar: how conversation, perception, personality, memory, inner activity and autonomous goals are intended to work together.
Understanding AinekioAinekio documentation
59 articles
References first, then journal entries.
Meet the robot familiar: how conversation, perception, personality, memory, inner activity and autonomous goals are intended to work together.
Understanding AinekioThe original Google Docs posts, restored in full: parts, firmware, software, design decisions, and the experiments that preceded the eight-servo robot.
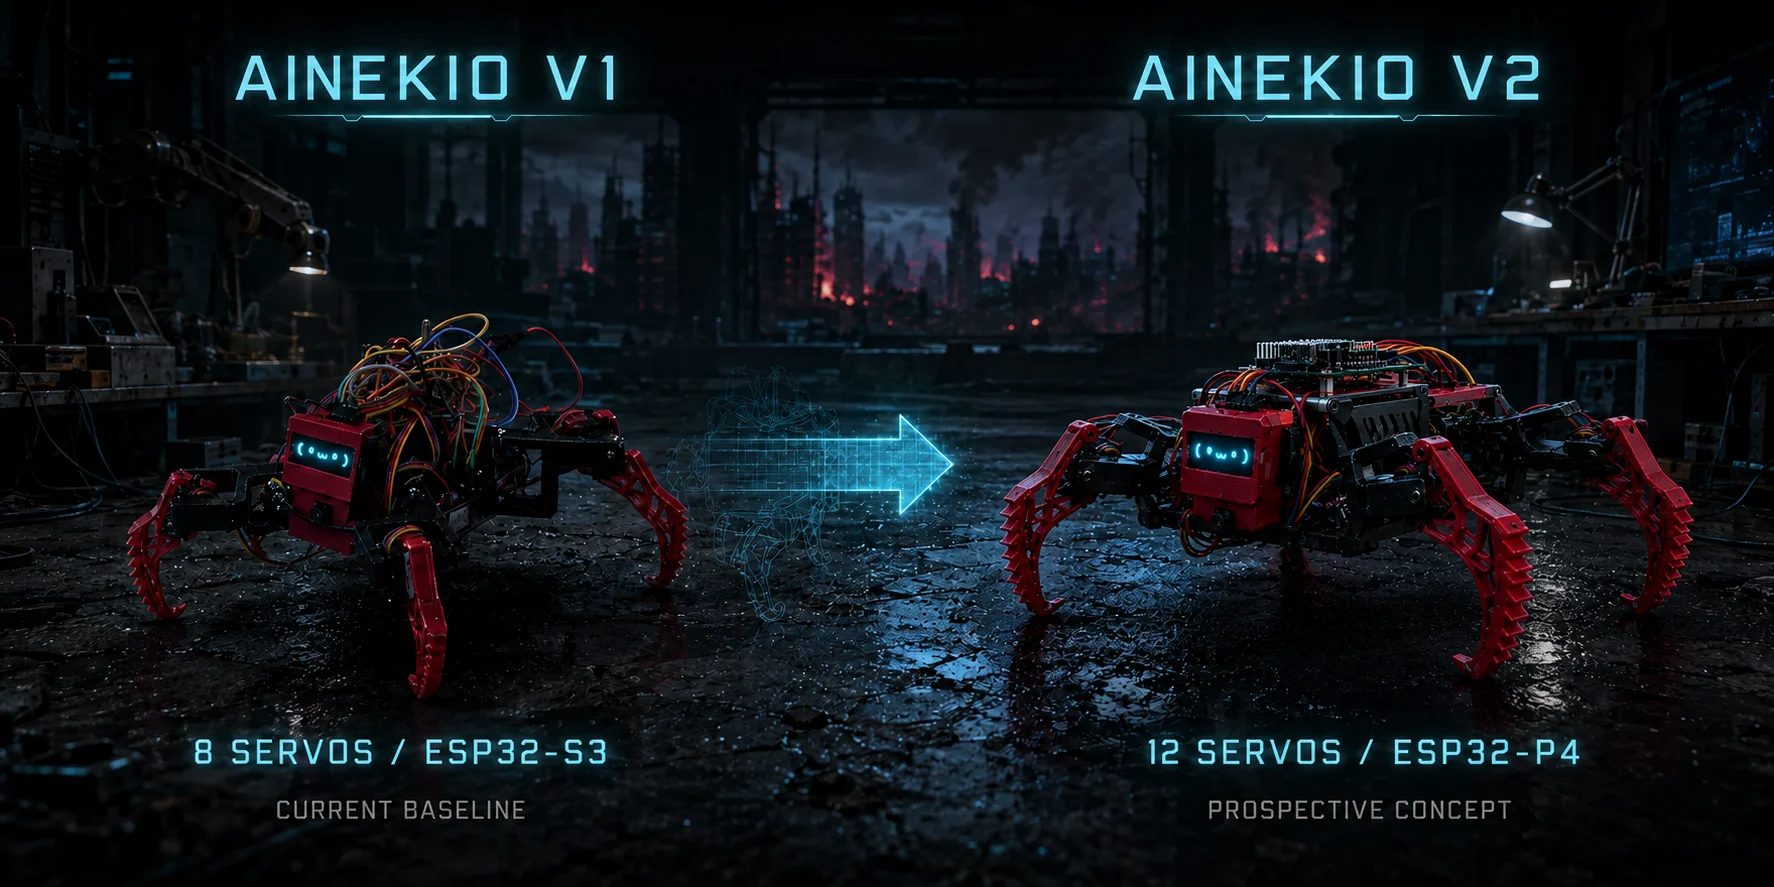
Original eight-servo robotEight versus twelve servos: motion generation, measured feedback, processors and the current 650 g V2 battery/charger assembly, alongside dated motion ranges.
Understanding AinekioGait and motion journal: V1/V2 geometry, loaded walking comparisons, Freestyle targets, measured shaft arrival and the latest Stand-training results.
Legs & gaitCurrent V2 hardware: 650 g assembly, 2S battery and USB-C charger, compact linkage geometry, feedback servos, training stand and dated physical trials.
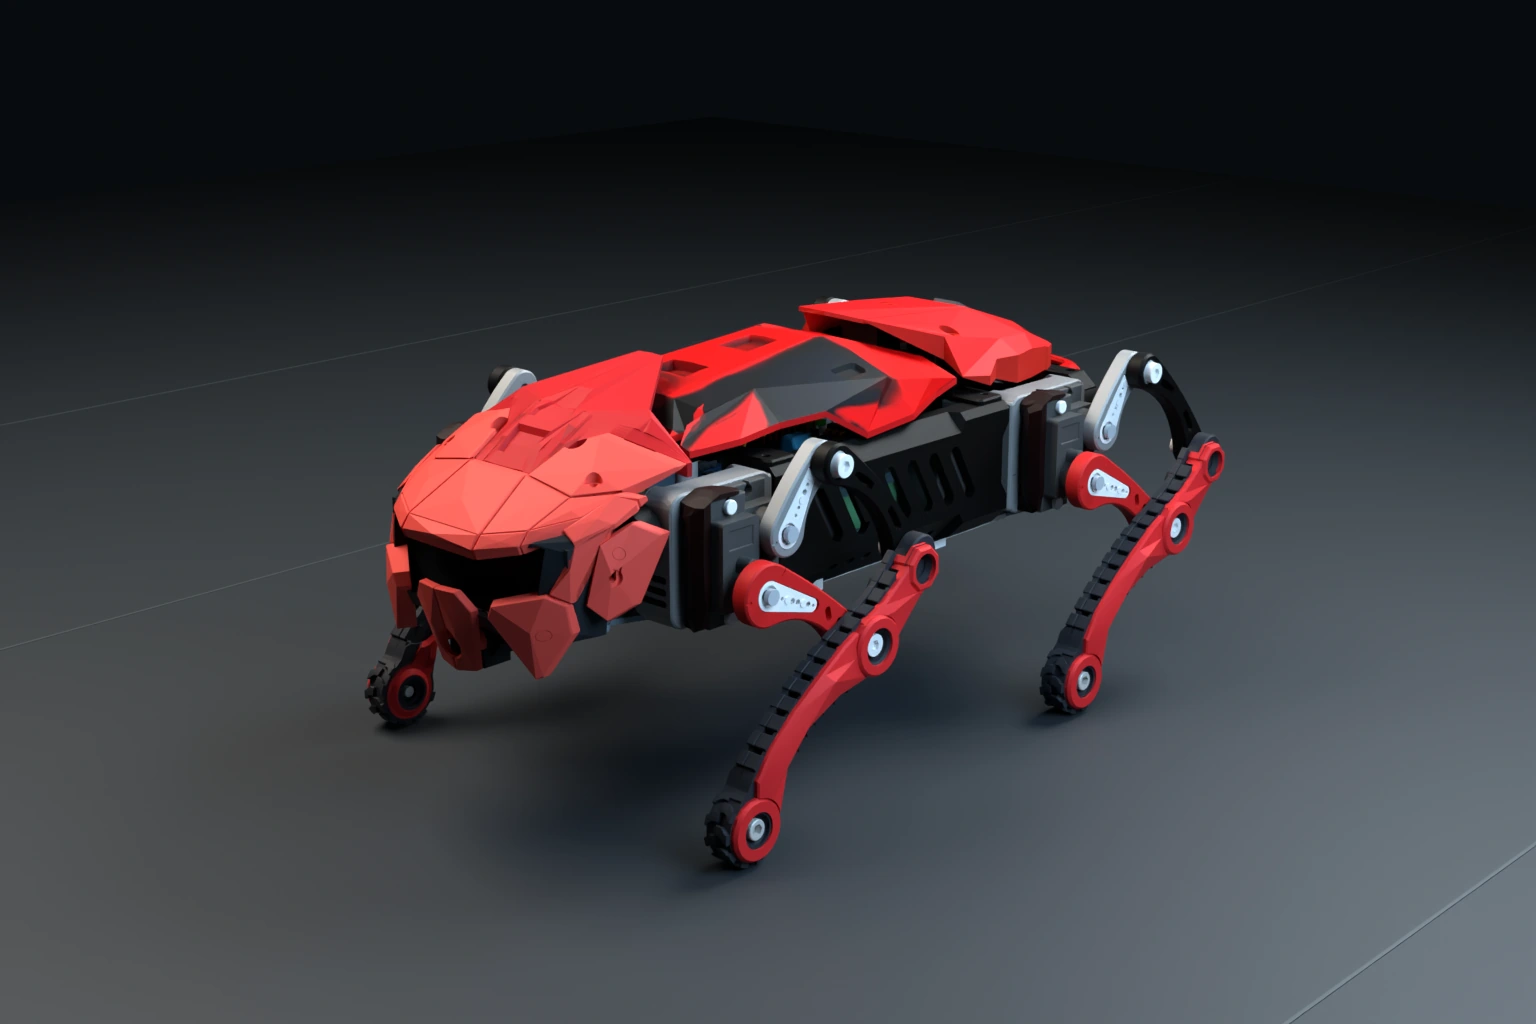
Chassis, shell & powerMeet Ainekio, a robot familiar combining conversation, personality, memory, perception and physical action, with two body designs and a continuing build journal.
Understanding AinekioThe eight-servo robot, its documented components and wiring, enclosure history, and the move to V2.
Original eight-servo robotMotion, camera, audio, provisioning, storage, and recovery on the current eight-servo controller.
Original eight-servo robotHow commands are validated, how results are reported, and how the robot handles interruption and connection loss.
Firmware & connectionsBody Control connections, event and leveling settings, SD video, Wi-Fi maintenance, and the retained command-recovery record.
Firmware & connectionsWhen Ainekio takes pictures, how they reach MetaHuman, and how an image is used to check a robot objective.
Vision, face & voiceMicrophone capture, wake detection, transcription, speech playback, and the remaining room tests.
Vision, face & voiceBody-event decisions, live IMU status, specialist planning and saved requests connected to Ainekio’s action results.
MetaHuman OSReactive, Semi, and Full behavior, result-driven choices, and how finite Desire plans give robot work a verifiable end.
MetaHuman OSThe new finite-event motion model, 339-example continuation, real-event recovery and a supported stretch trial with all nine positions verified.
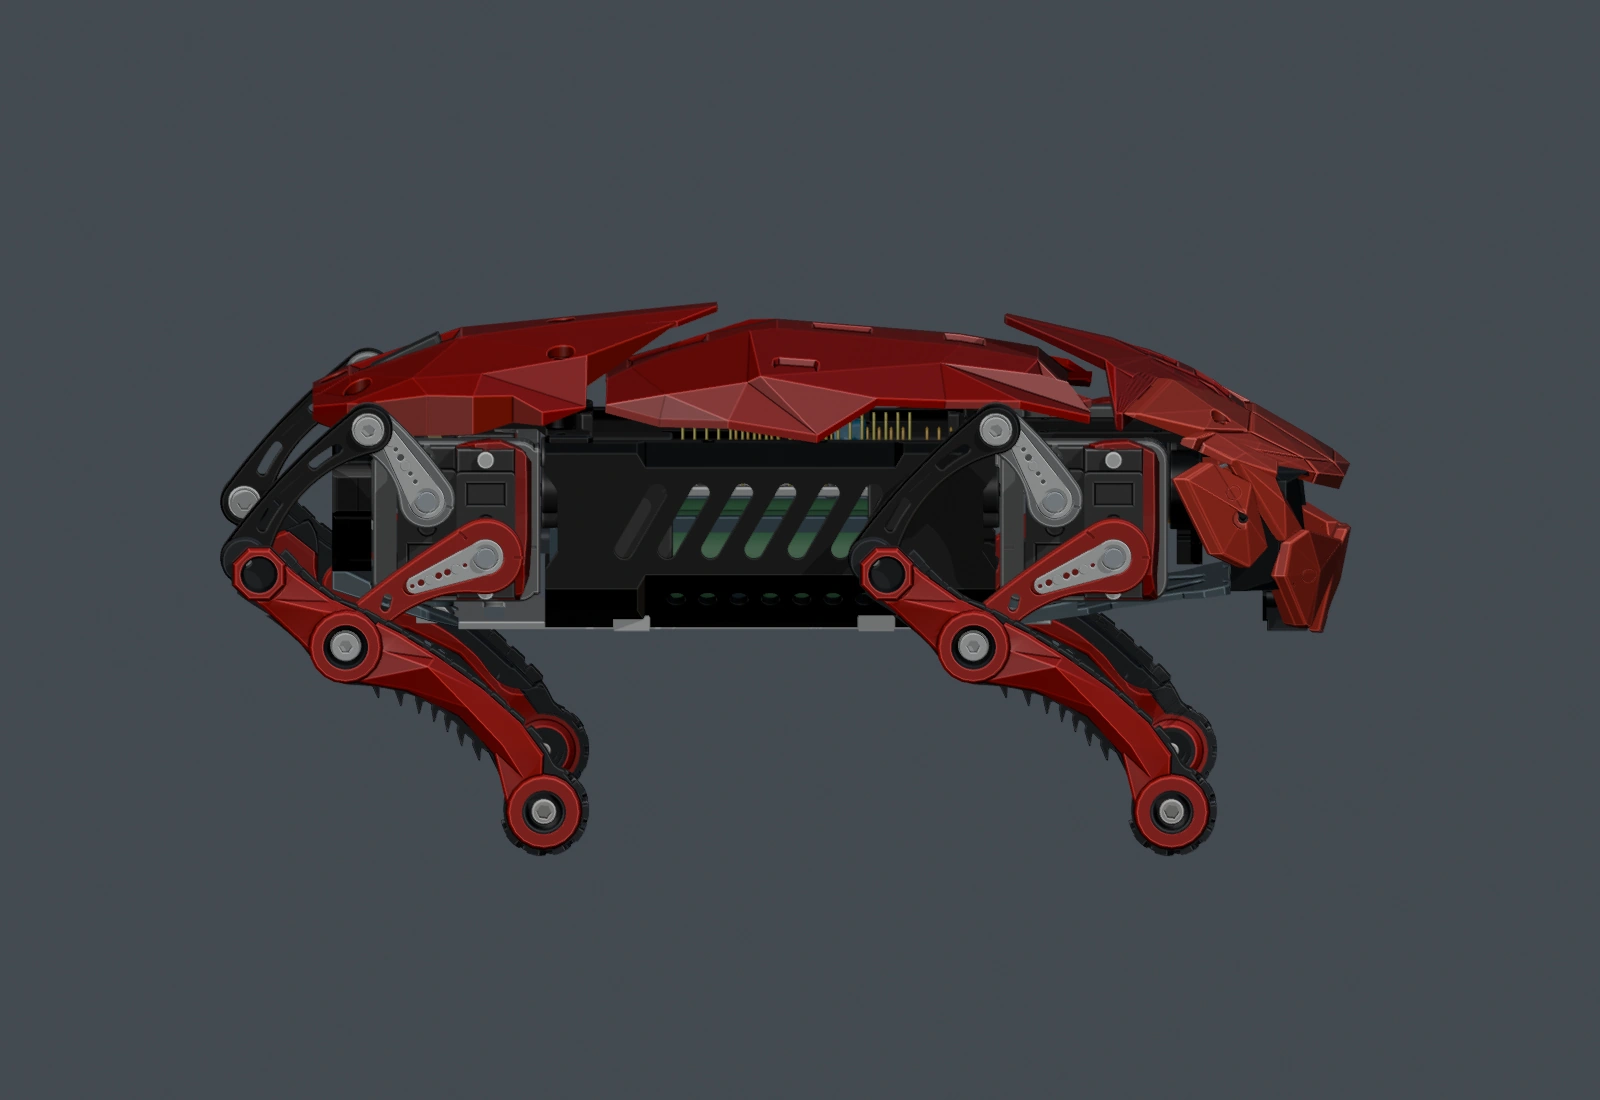
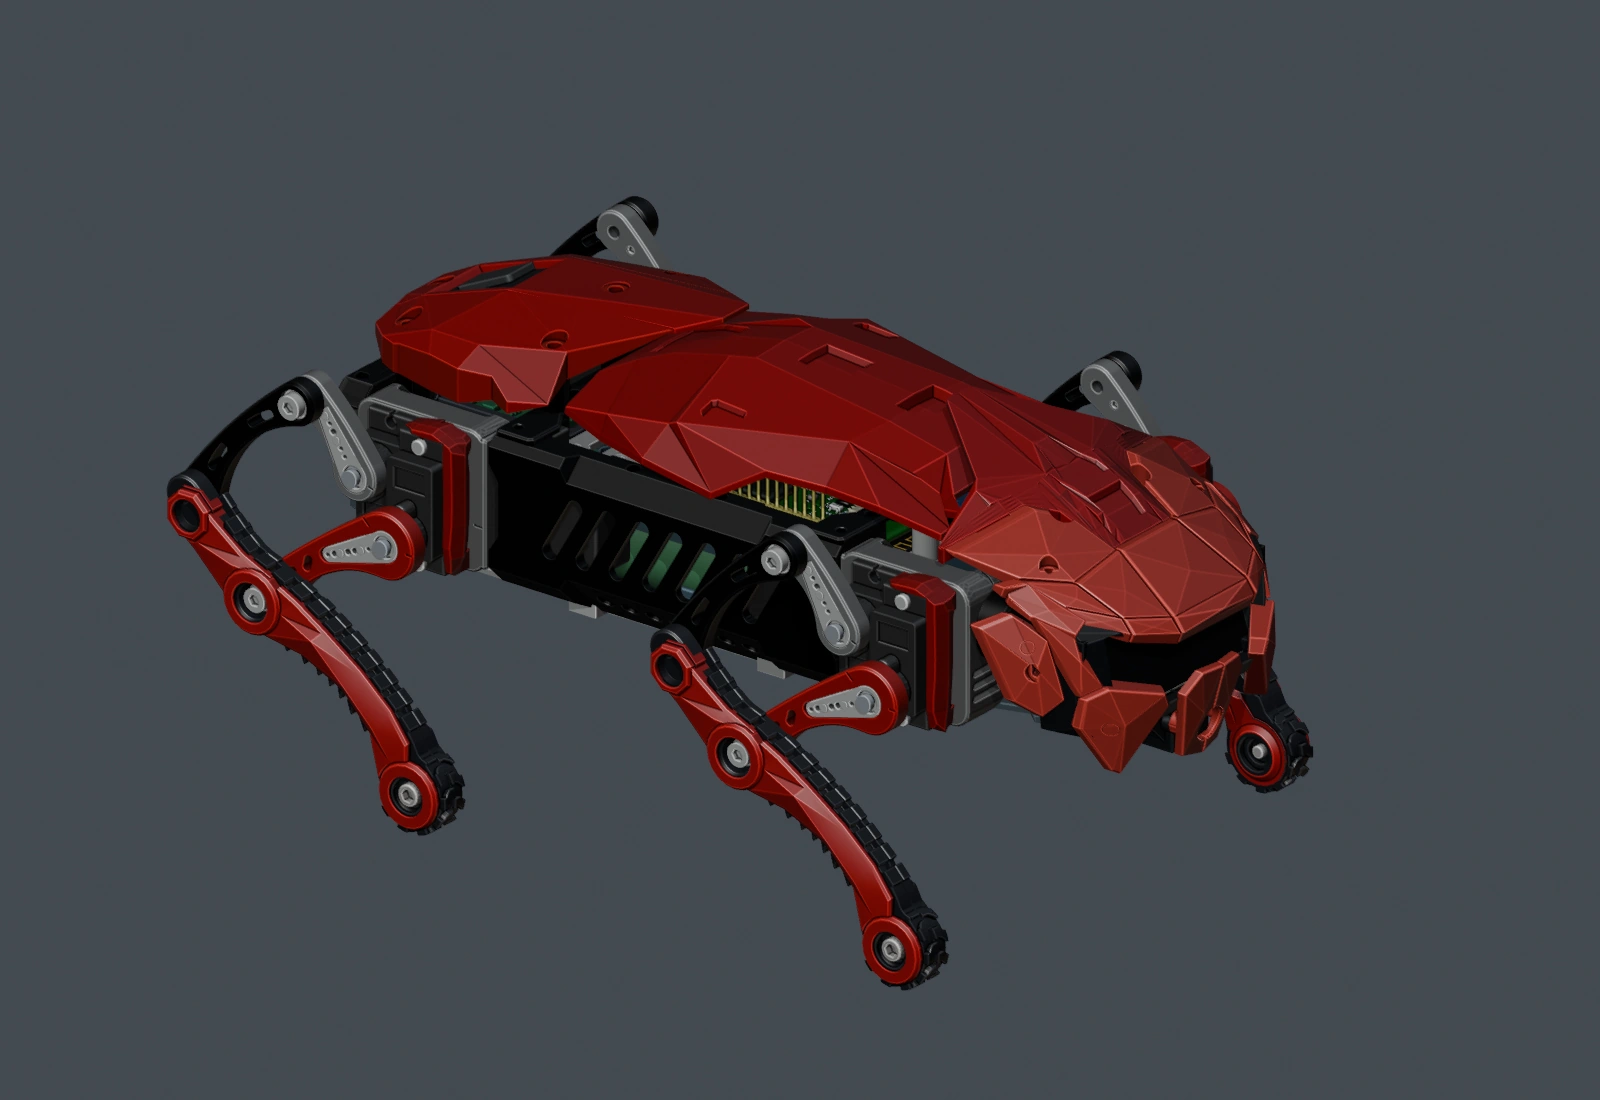
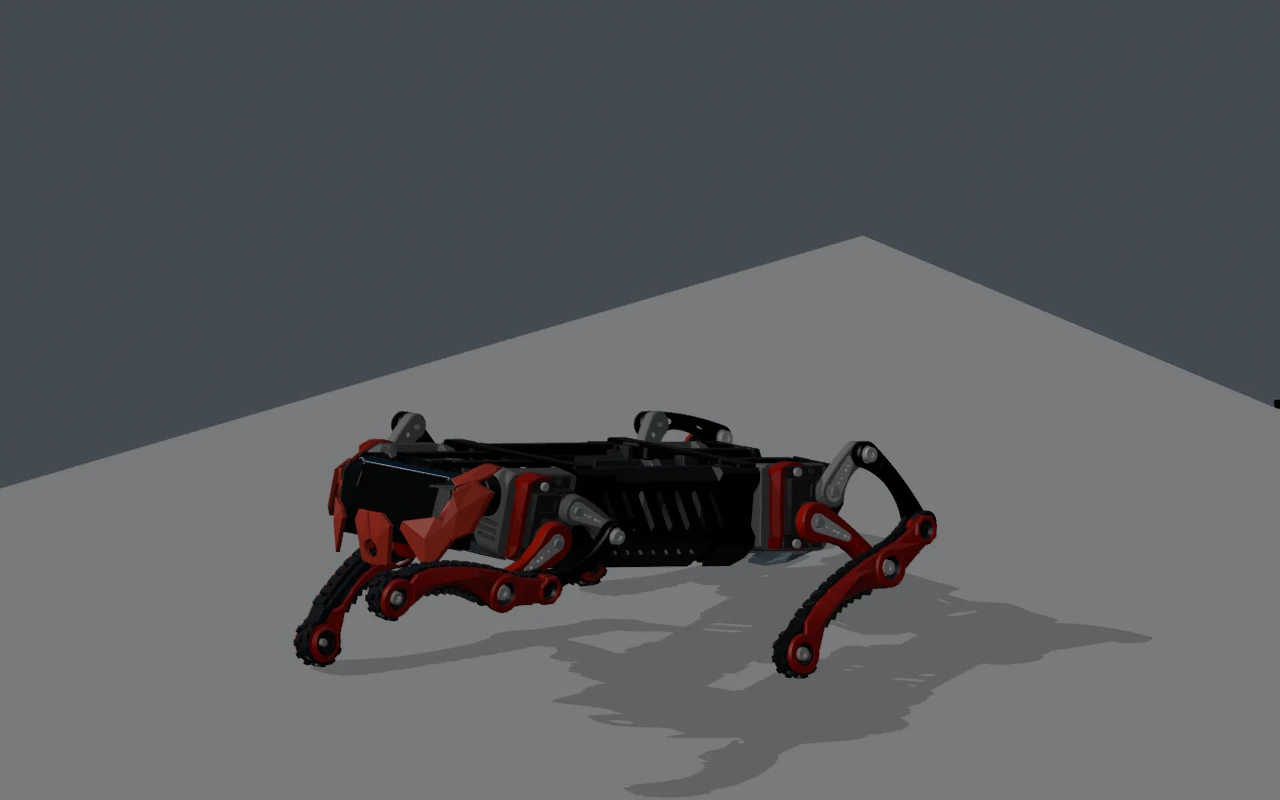
Legs & gaitThe current Blender assembly, battery and charger dimensions, printable support stand, and supported Stand/Walk firmware trials.
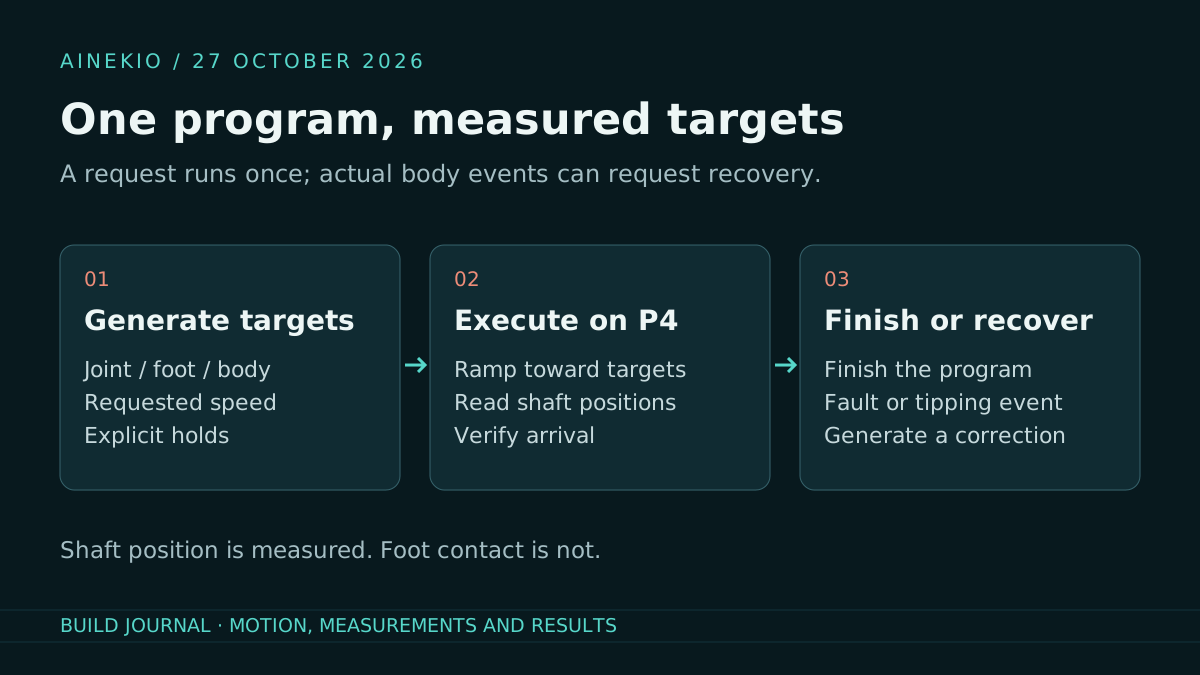
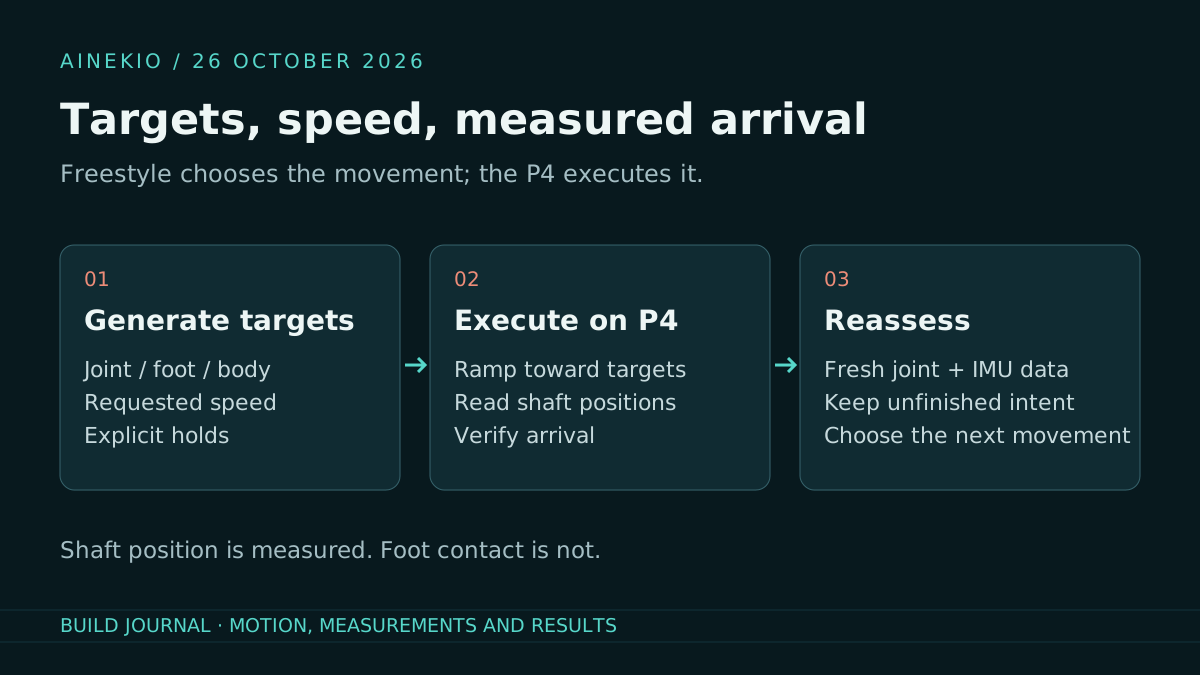
Chassis, shell & powerEditable motion examples, compact Qwen inference on the Q6A, measured shaft arrival, and the October 26 Stand-training results.
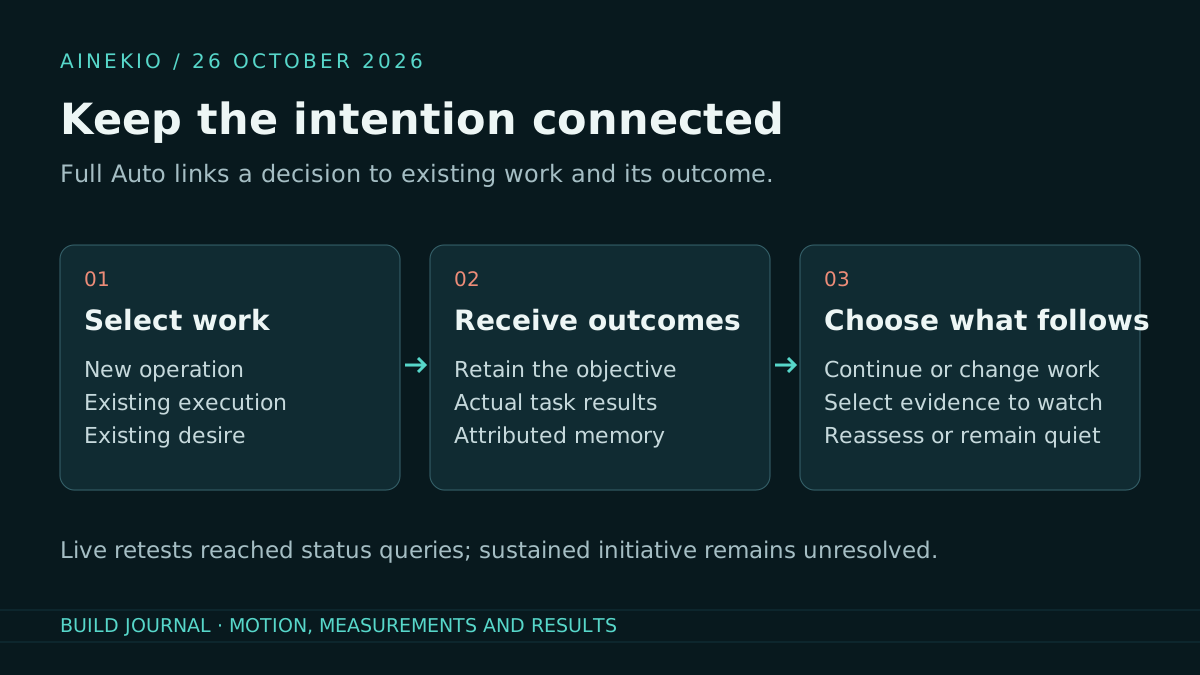
Legs & gaitFull Auto can continue existing work and request relevant memory; live trials expose the remaining initiative gap. Queue and on-demand model changes reduce avoidable overhead.
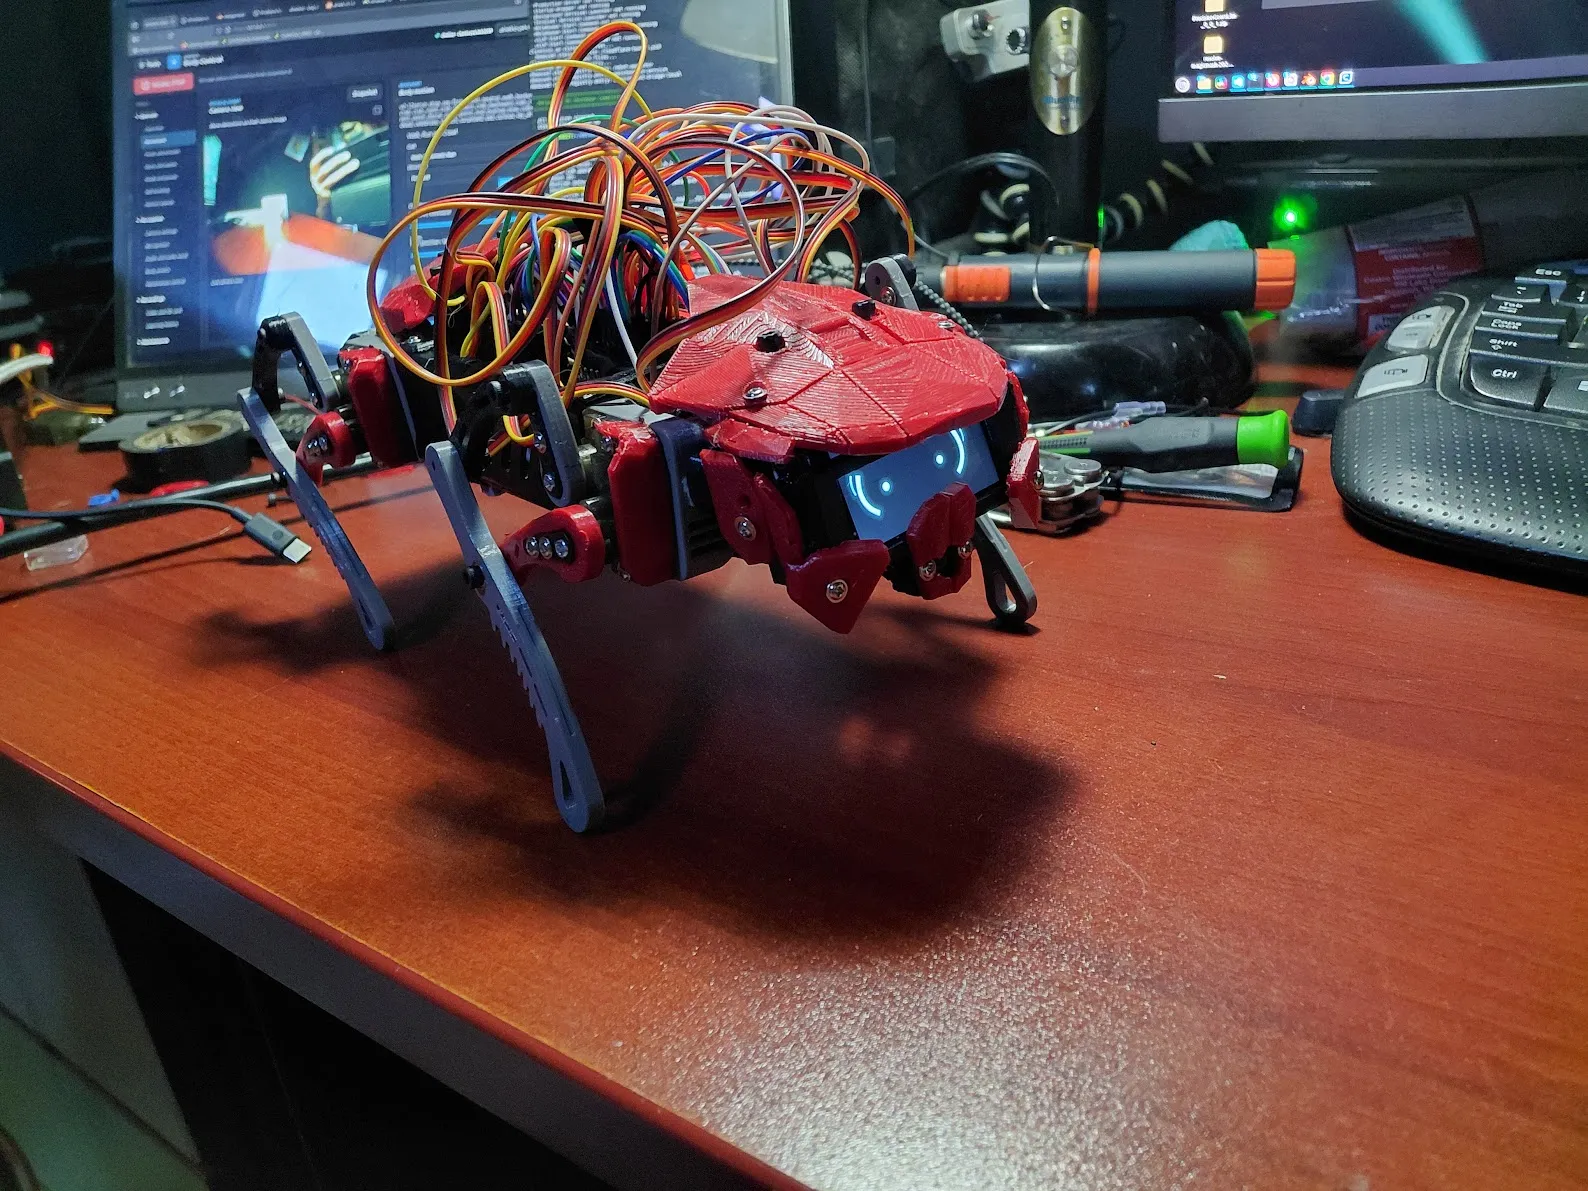
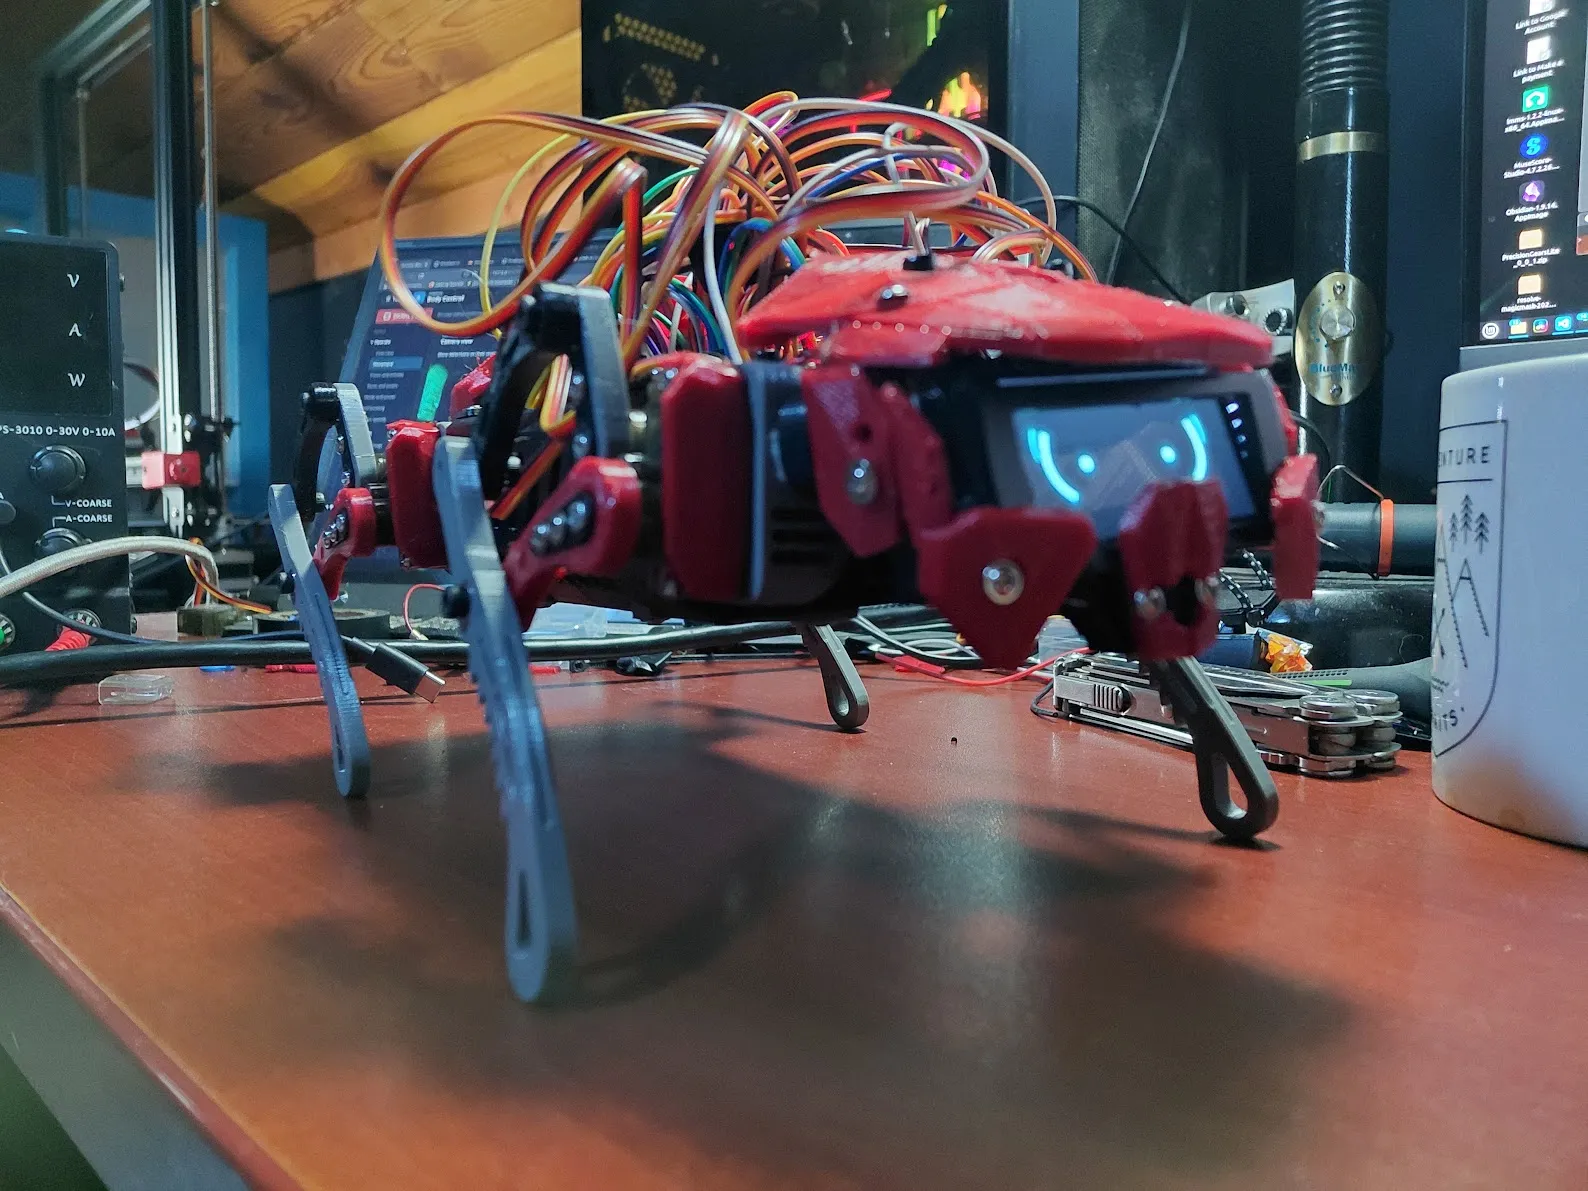
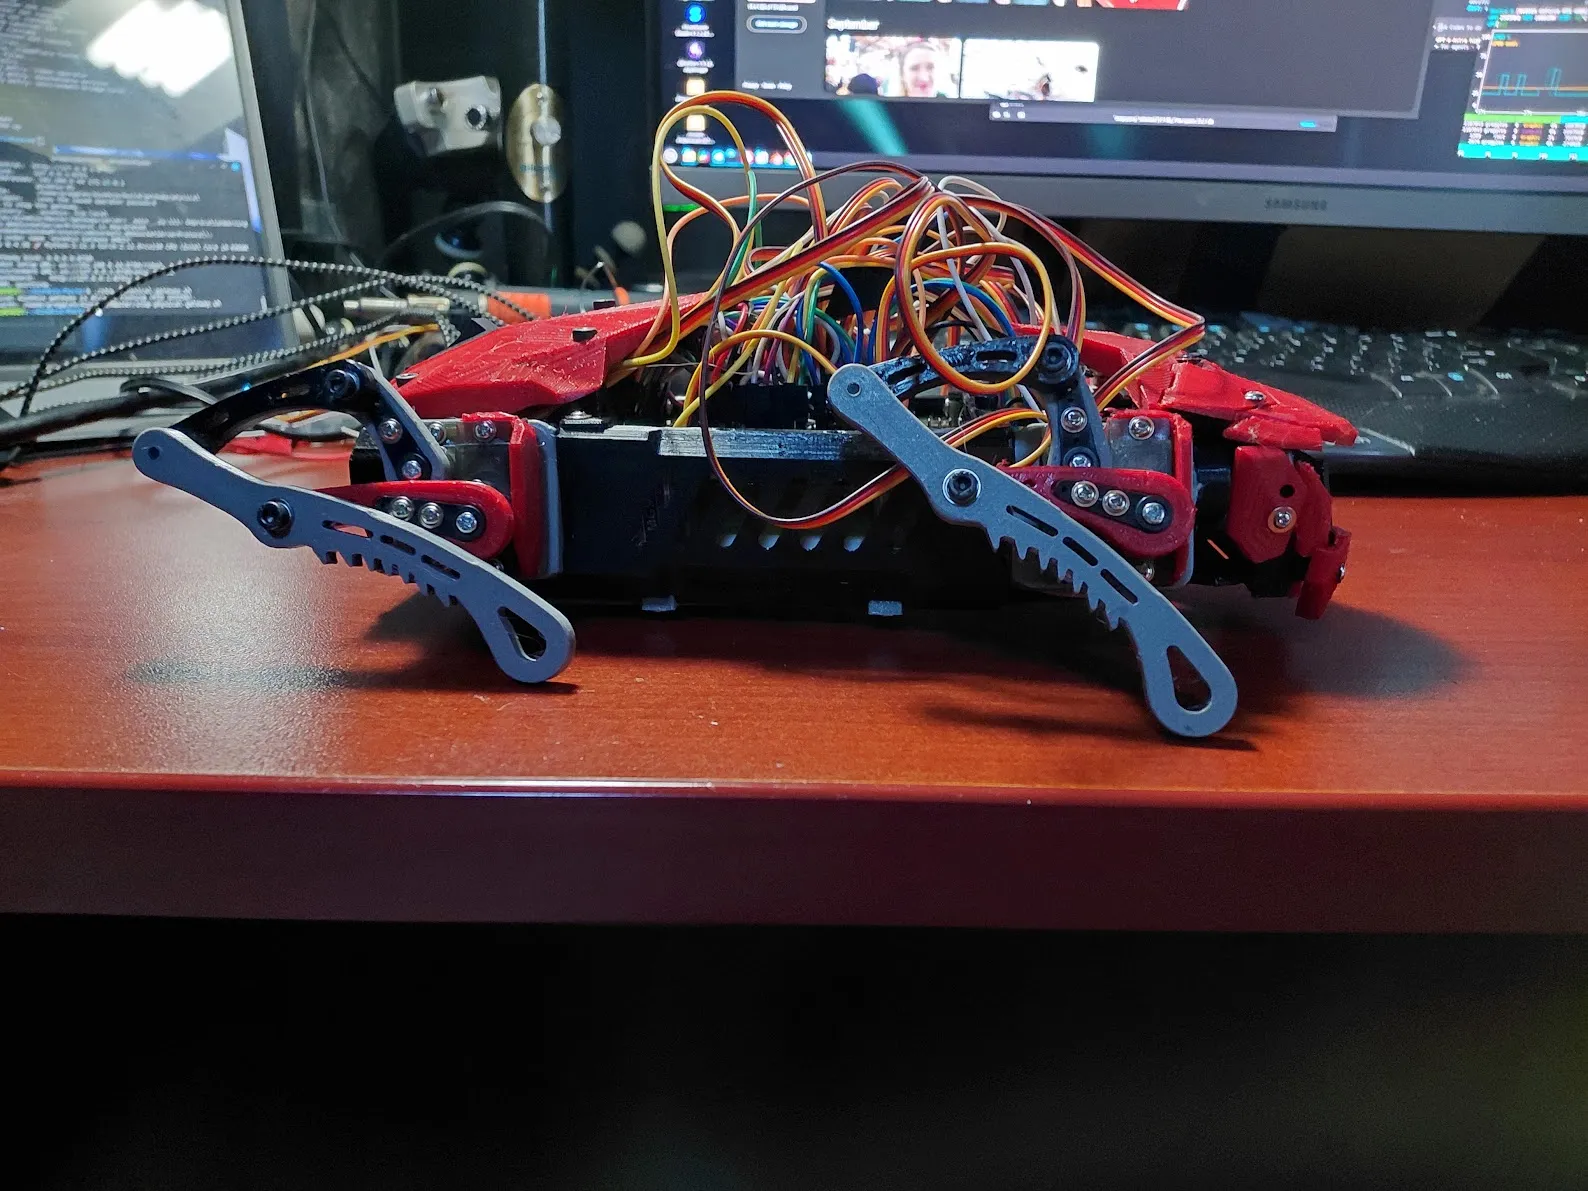
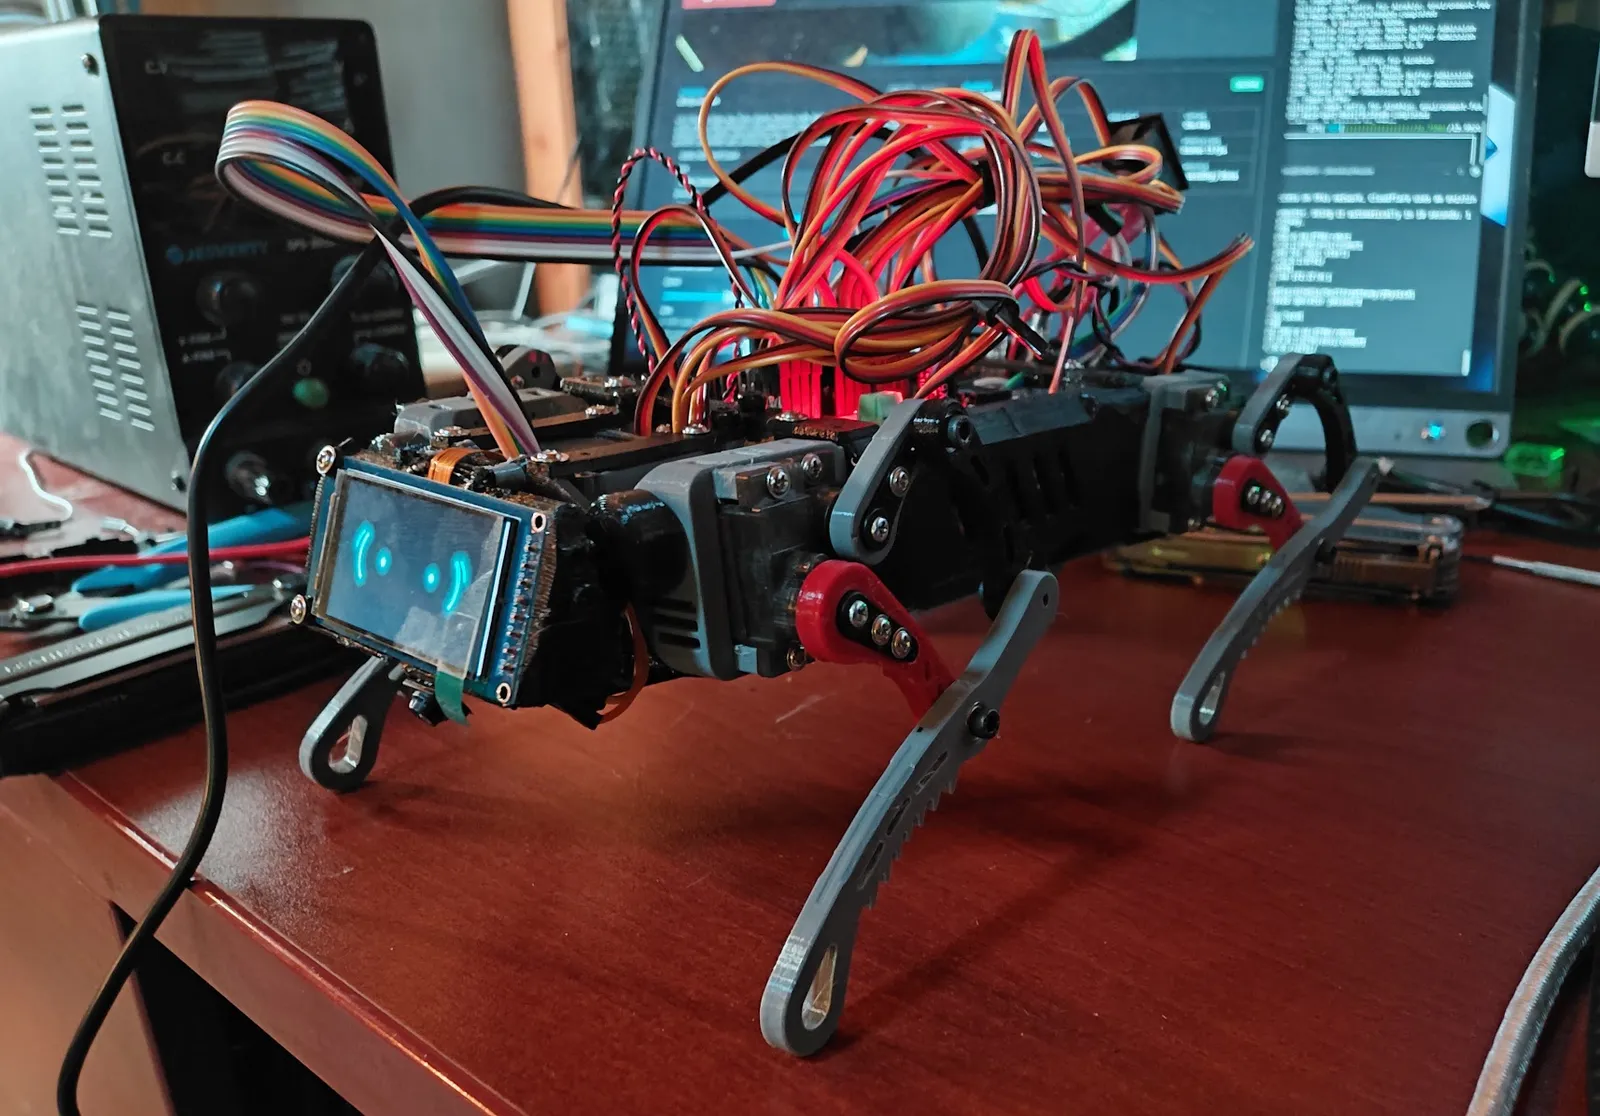
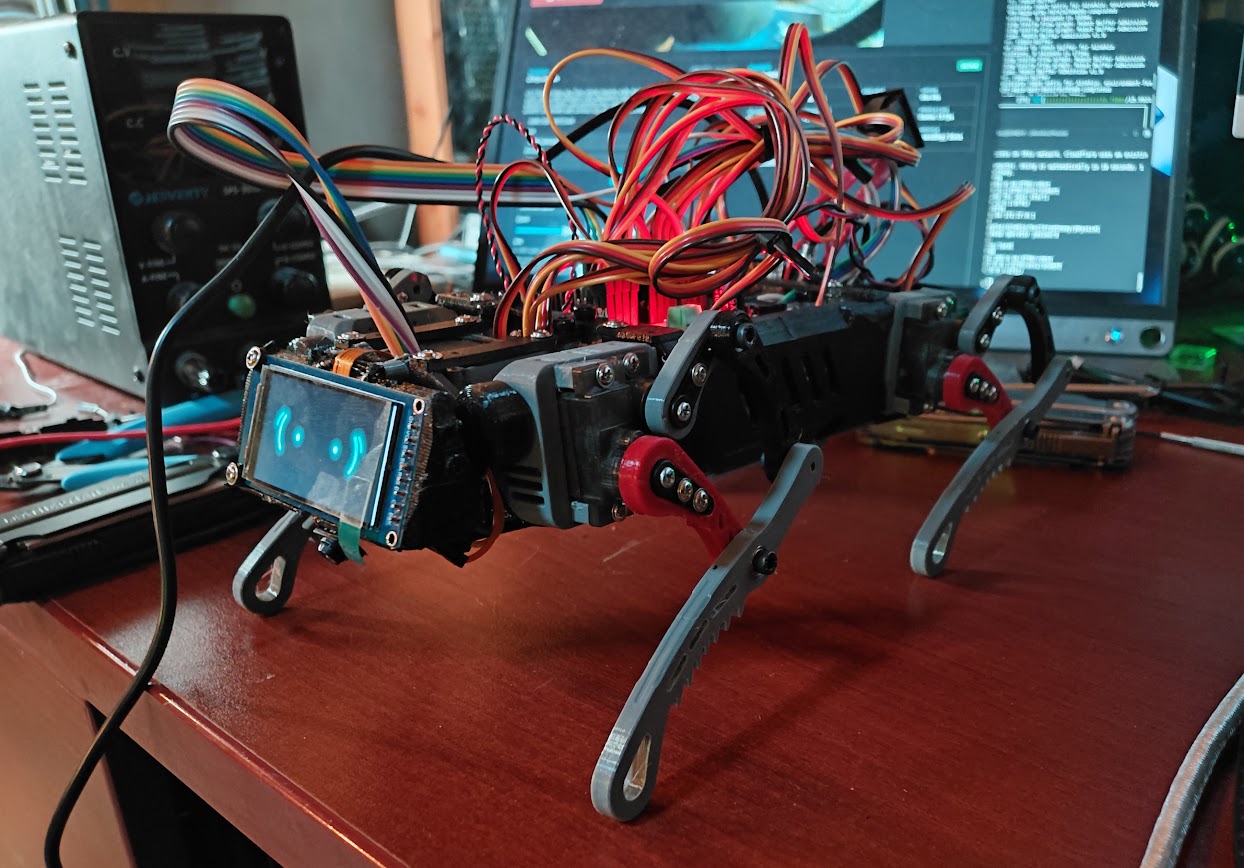
MetaHuman OSNew photographs show Ainekio's revised face and shell. Ground repair, final-pass Stand verification and connection-loss handling improve the body-control foundation.
Chassis, shell & powerAinekio now records ordinary walking, compares learned Walk and Run policies, and exposes learning history. Physical trials show modest tracking gains with important limits.
Legs & gaitA dedicated one-call tip/shake workflow, motion-aware event classification, completed-work recovery repairs and connected-recipient admission keep body events tied to real work.
MetaHuman OSTrained 2B Intent and Task models, experimental 9B autonomy, monitor performance repairs, and live tests of camera freshness and conversational memory.
MetaHuman OSTwelve modified servos, a CD74HC4067 multiplexer, measured-position tools and revised chassis parts give Ainekio a way to check what its joints actually did.
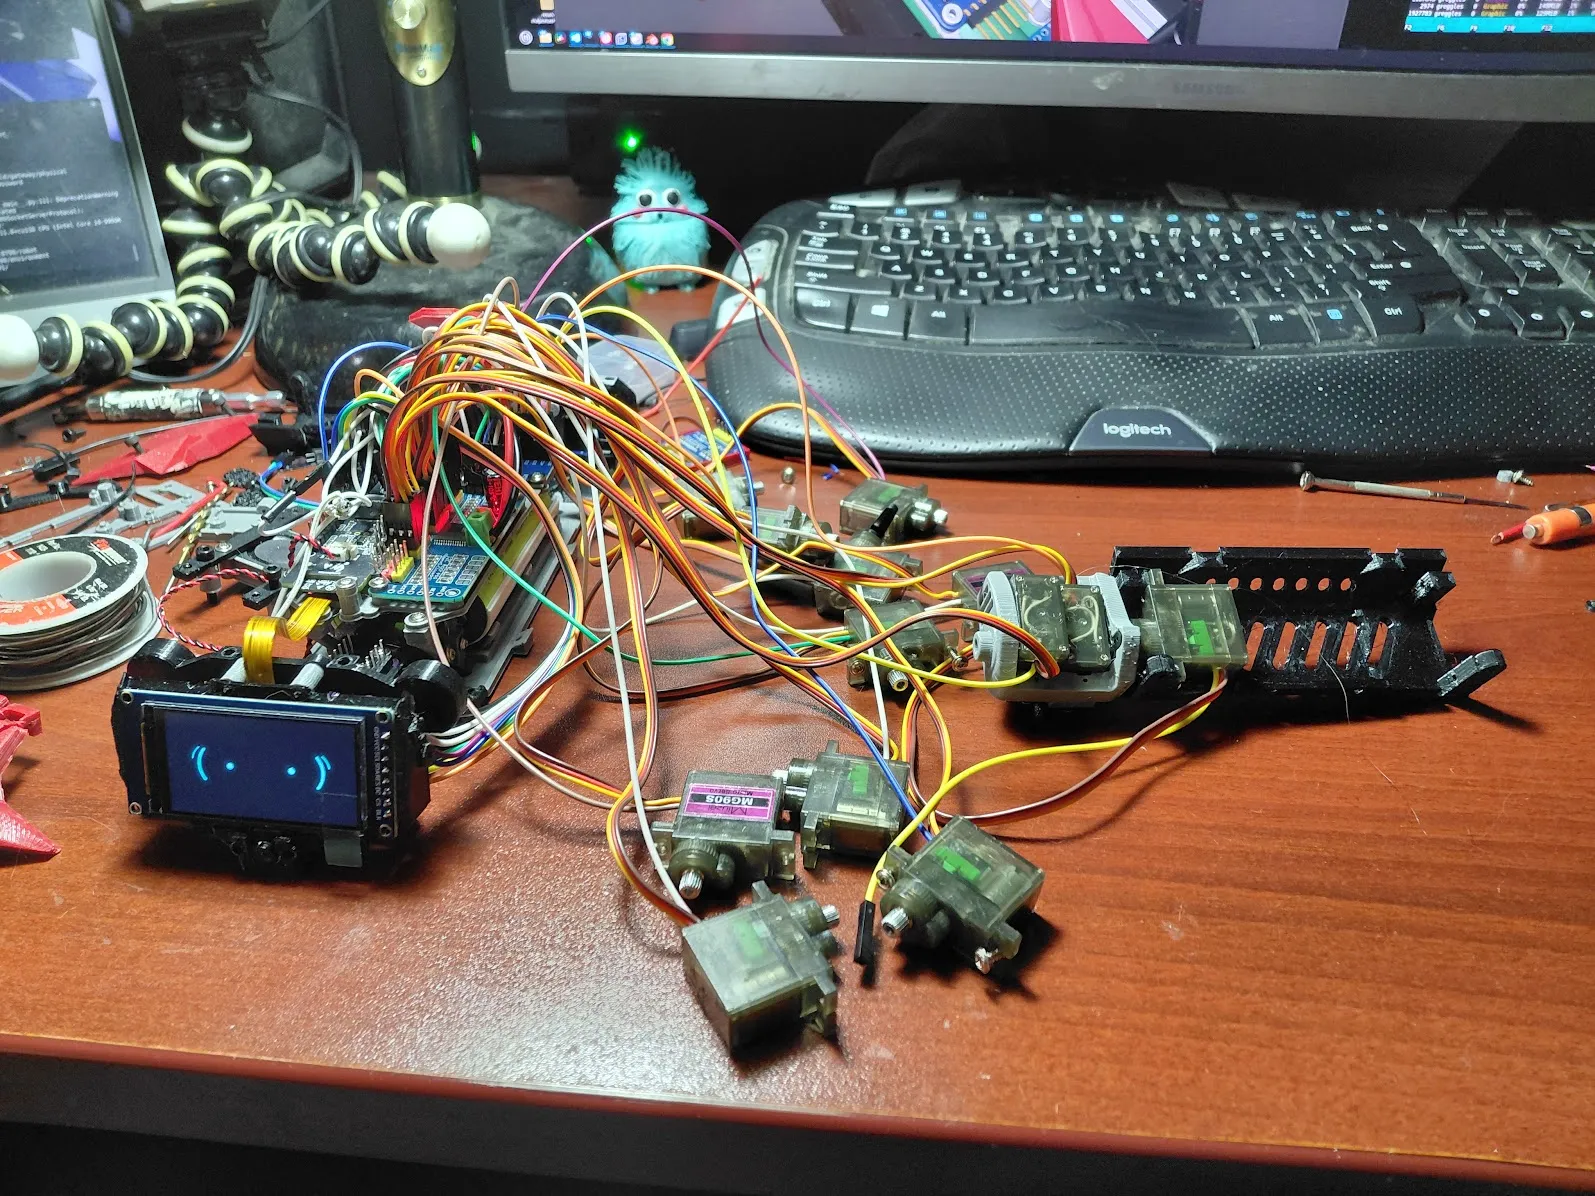
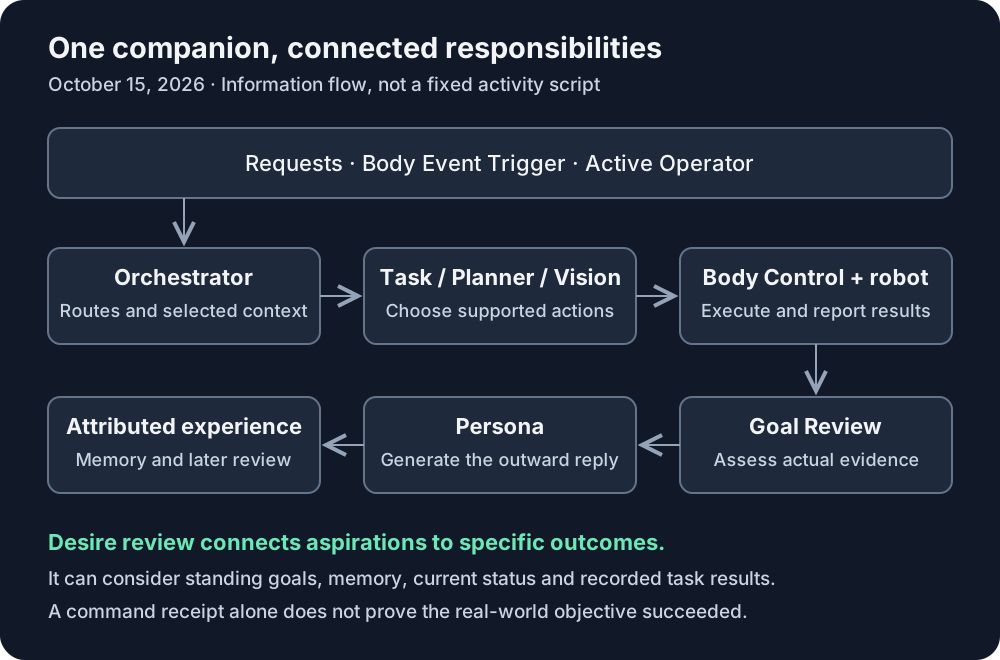
Chassis, shell & powerHow Active Operator, model categories, attributed memory and Desire review connect to task execution, with Persona now responsible for the spoken reply.
MetaHuman OSTwo small remote LoRA diagnostics tested autonomy and conversational personality, including actual serving comparisons. Neither candidate qualified for deployment.
MetaHuman OSMetaHuman's new locomotion contract connects distance, turn, approach, follow and visual goals to measured progress, with signed lateral control on the P4.
Firmware & connectionsRevised Walk, Run, Crawl, Crab and seated Wave, plus a level reference, per-leg feedback and stationary gyro calibration in Body Control.
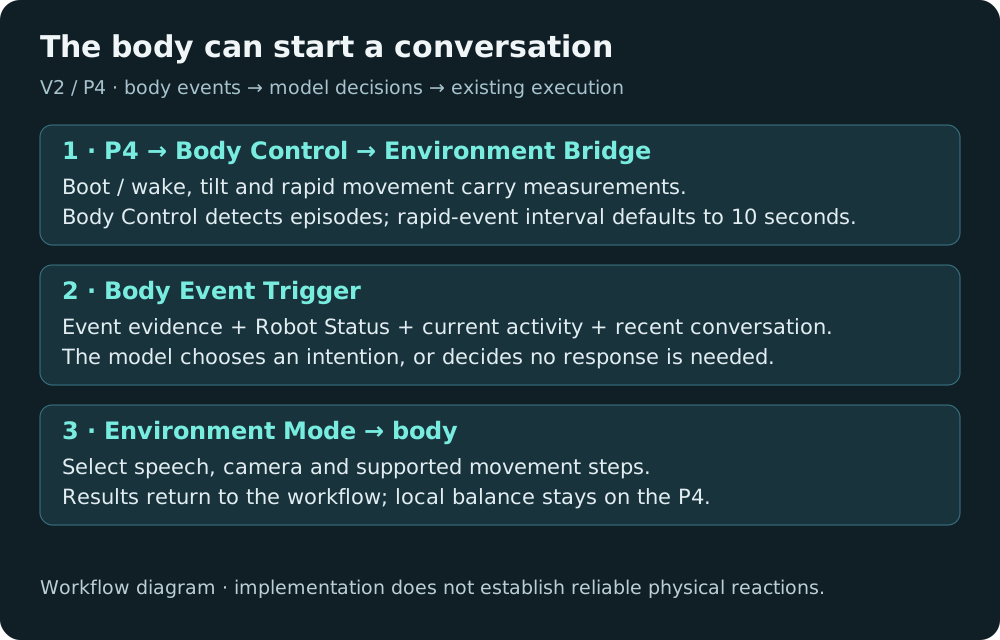
Legs & gaitWake, tilt and rapid-movement events now travel from Body Control to a dedicated MetaHuman workflow, with editable detection settings and model-selected reactions.
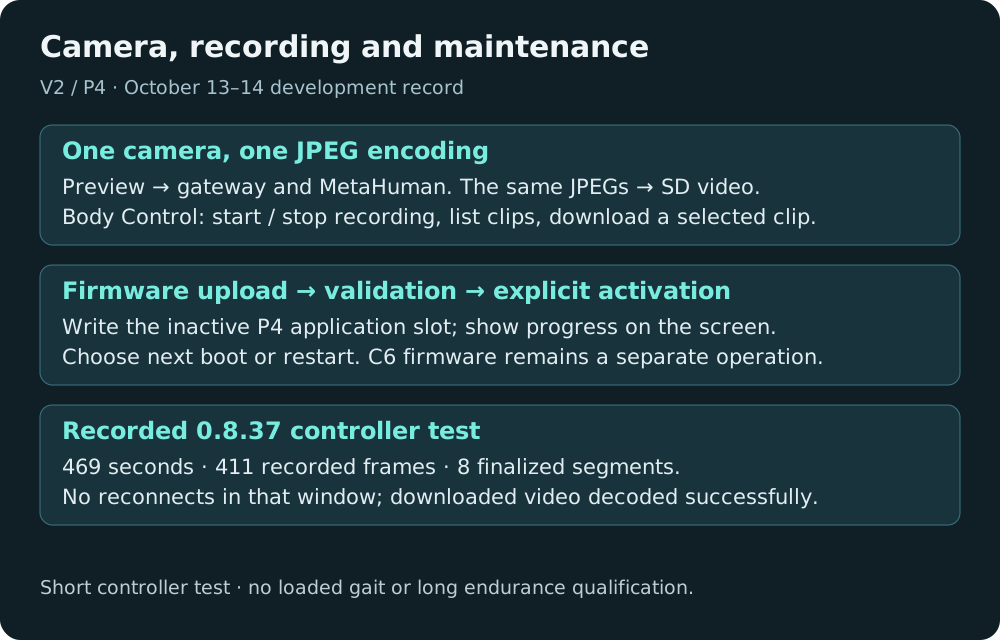
MetaHuman OSBody Control gains SD video recording and downloads, staged P4 firmware updates, robot logs and a measured short Wi-Fi recovery run.
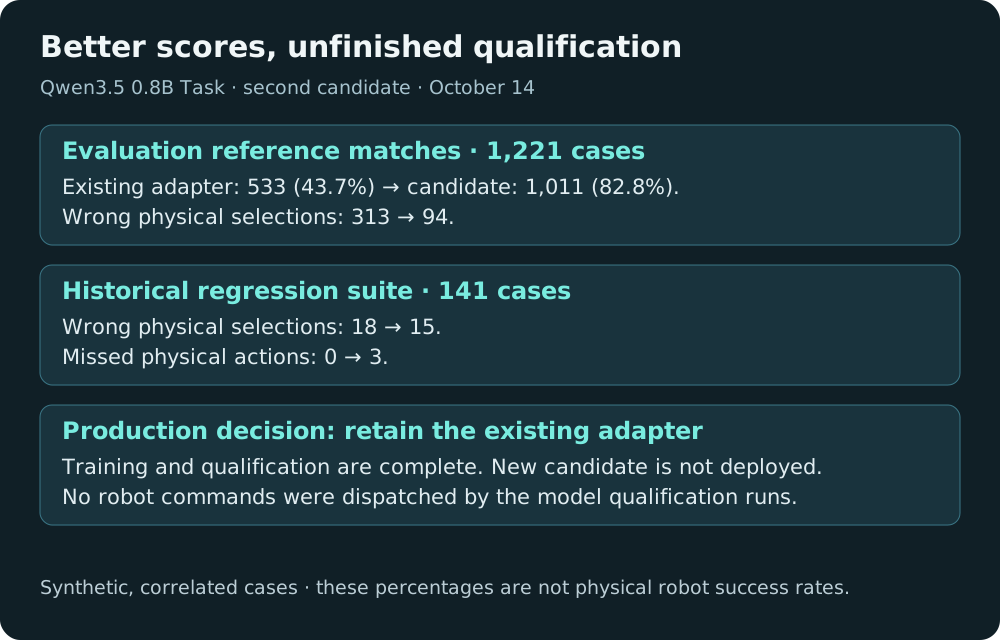
Firmware & connectionsTwo new 0.8B Task LoRA candidates address speech/action confusion. Both improve aggregate scores; neither replaces the deployed adapter after qualification.
MetaHuman OSA staged startup rise, saved self-leveling controls, a 566 g build report and a geometry calculator, with installed firmware separated from loaded-motion results.
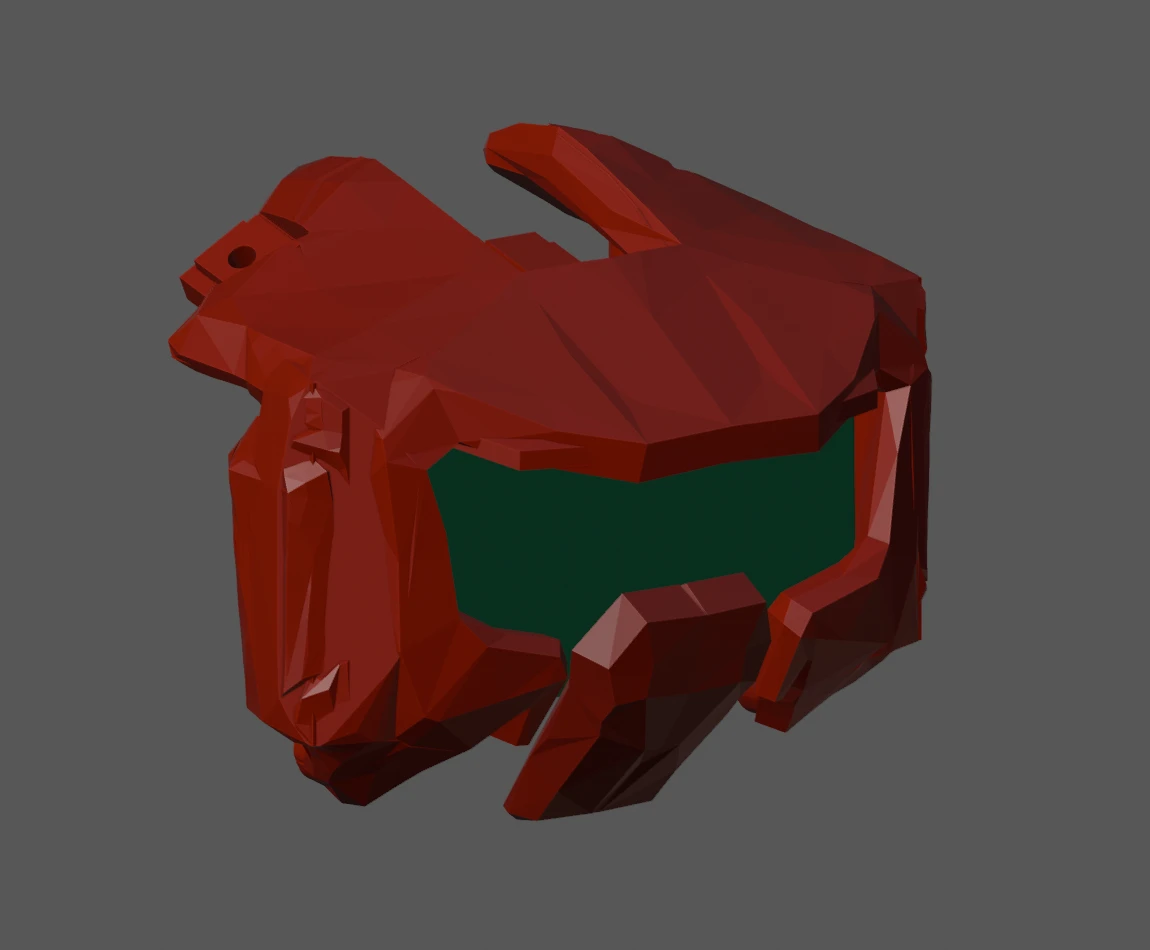
Legs & gaitExterior printing has begun. Follow the Blender shell and camera-mount exports, the new power-supply direction, and revised foot placement for Lay Down and Play Dead.
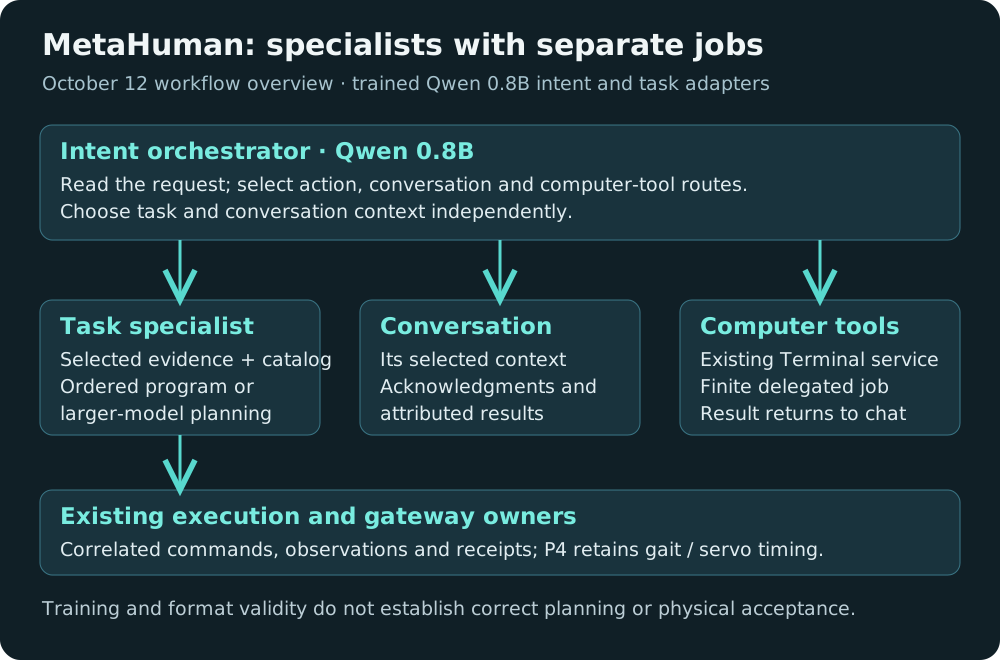
Chassis, shell & powerQwen 0.8B specialists, node-workflow changes, computer-task delegation and a side-by-side record of a rejected goal-planning candidate.
MetaHuman OSA desktop YOLOE pilot now searches and tracks using the robot camera. Follow the live chair result, exact-frame selection, model limitations, and remaining integration work.
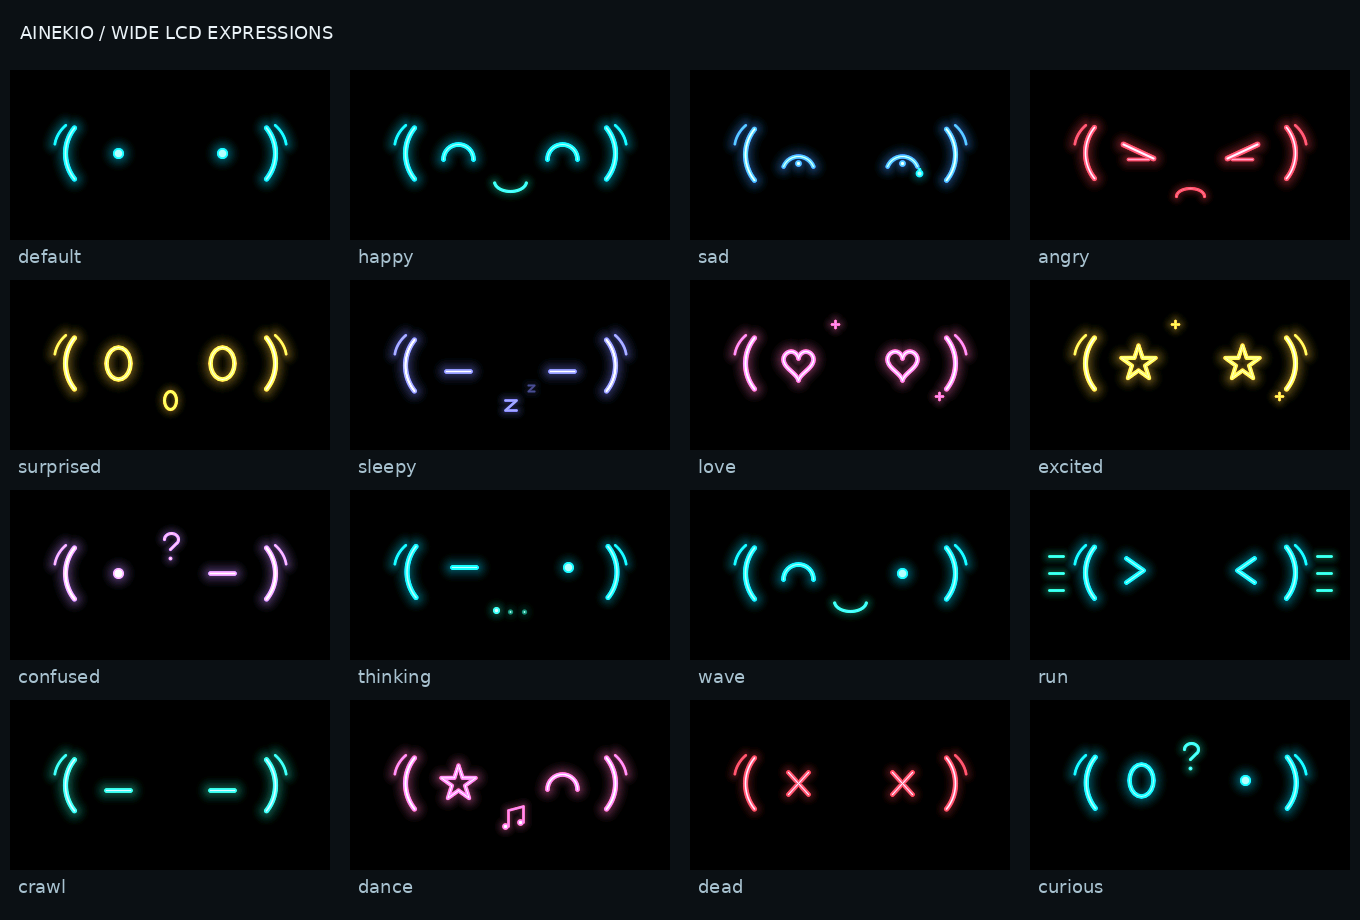
Vision, face & voiceThe physical robot has an illuminated wide LCD. Explore actual renderer previews, recorded camera and speaker checks, and the expression and speech work still in development.
Vision, face & voiceMetaHuman now separates request routing, task planning and conversation. Body Control gains connection choices, while perception and speech refinements remain under review and Active Operator is untested on the robot.
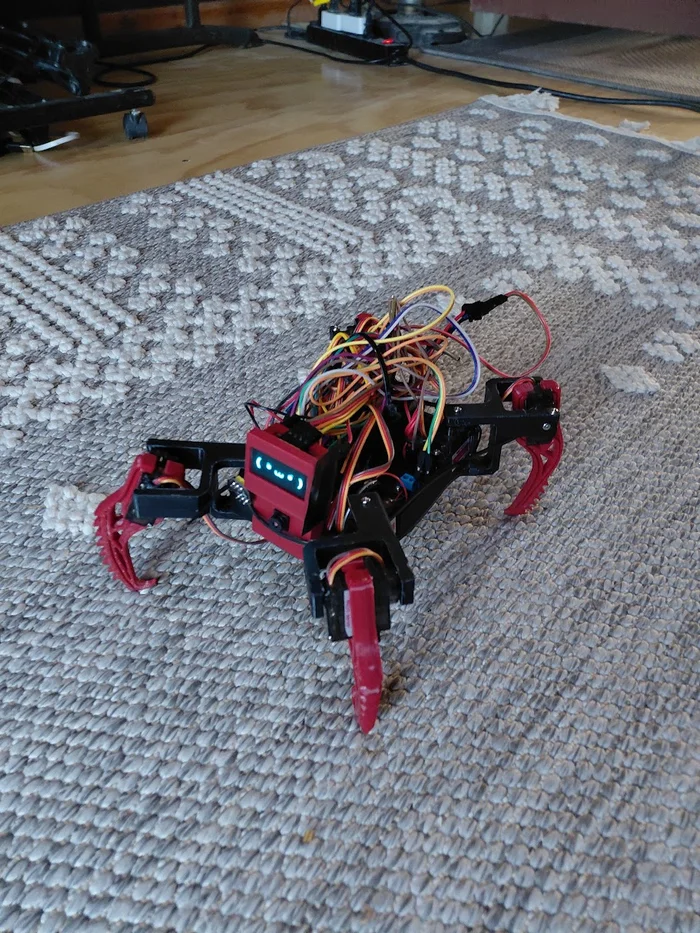
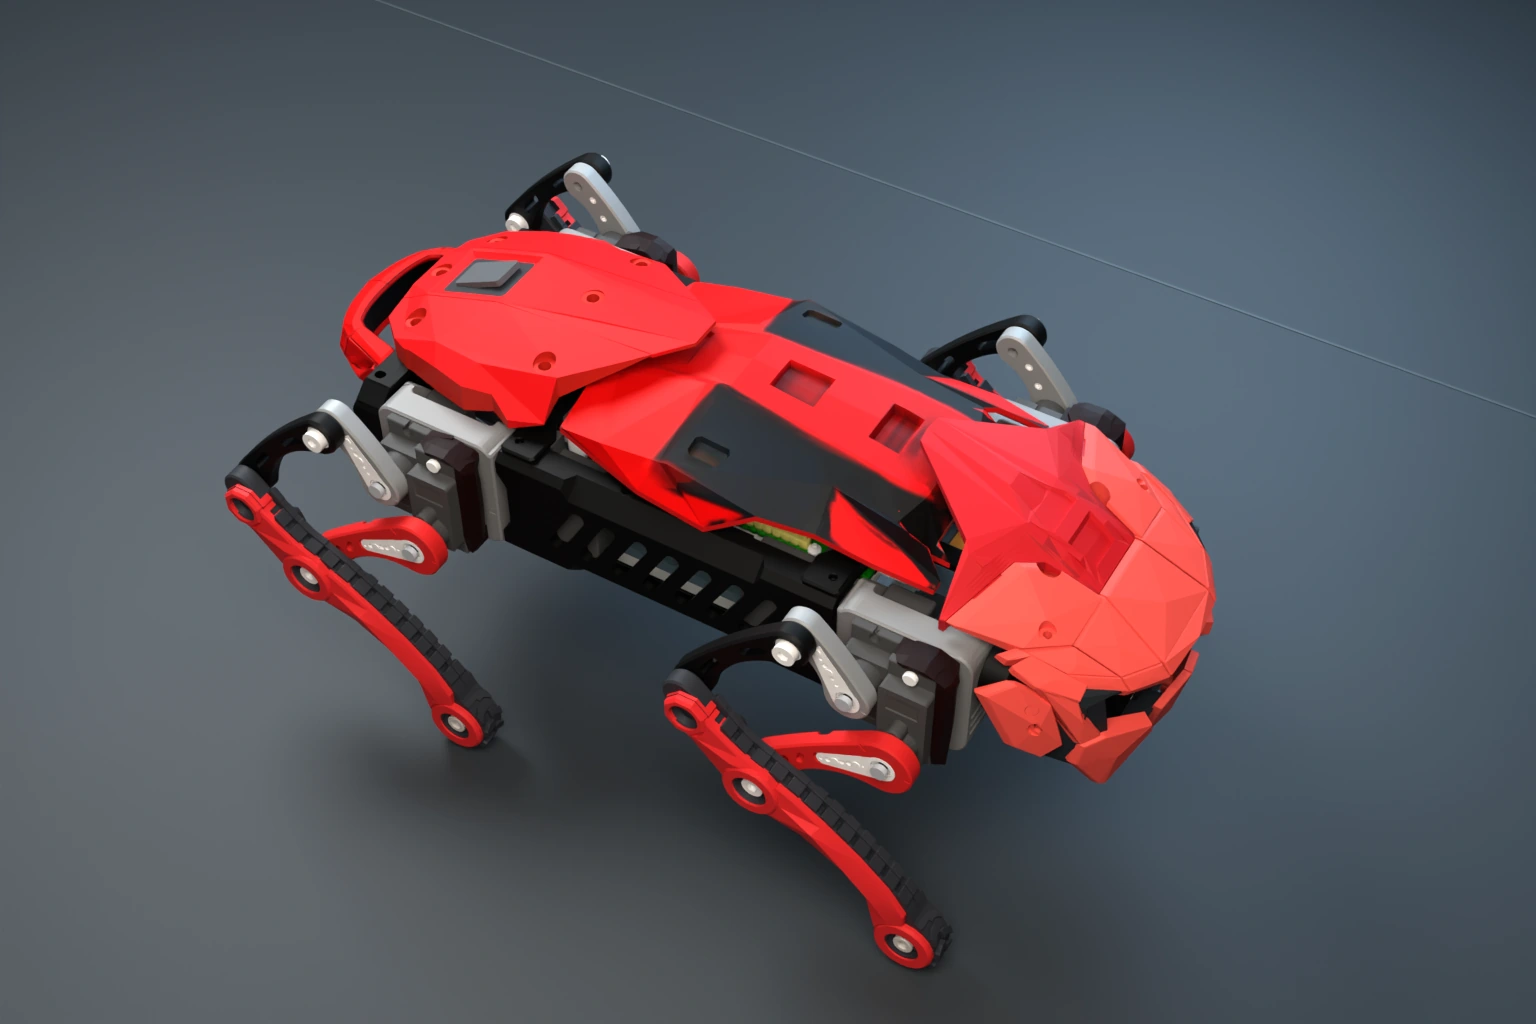
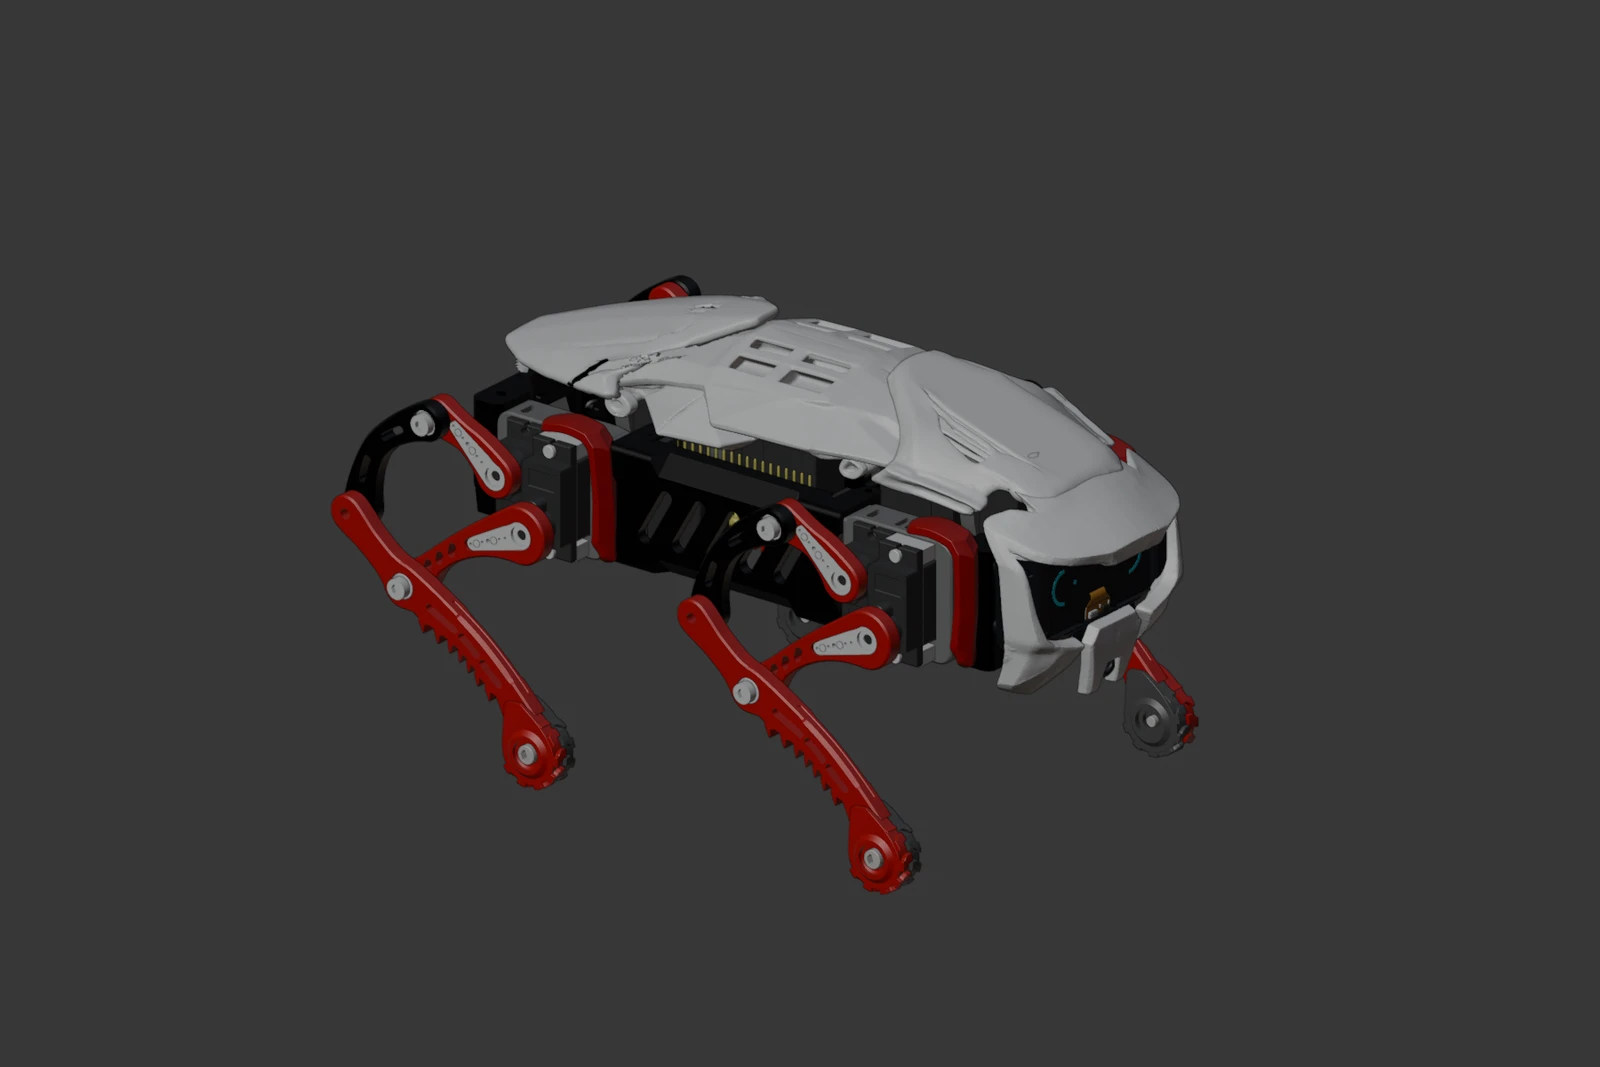
Firmware & connectionsThe revised twelve-servo robot can stand, walk and respond to commands. A current build photograph, the October 6 comparison, and the latest mounting-part exports.
Legs & gaitThe 35 mm carrier candidate has a complete offline motion library, with explicit changes to foot placement, reduced Upright reach and unresolved servo travel.
Legs & gaitThe printed chassis could not stand on its MG90 servos. The next iteration keeps those servos, removes weight, replaces the battery bank and revises the legs.
Chassis, shell & powerContinuous steering, camera profiles, recognition interfaces and an IMU estimator have progressed. Live balance control and sustained wireless reliability still need work.
Firmware & connectionsQ6A integration, the revised Ainekio v2 chassis, and the first pieces of a more active perception and control loop.
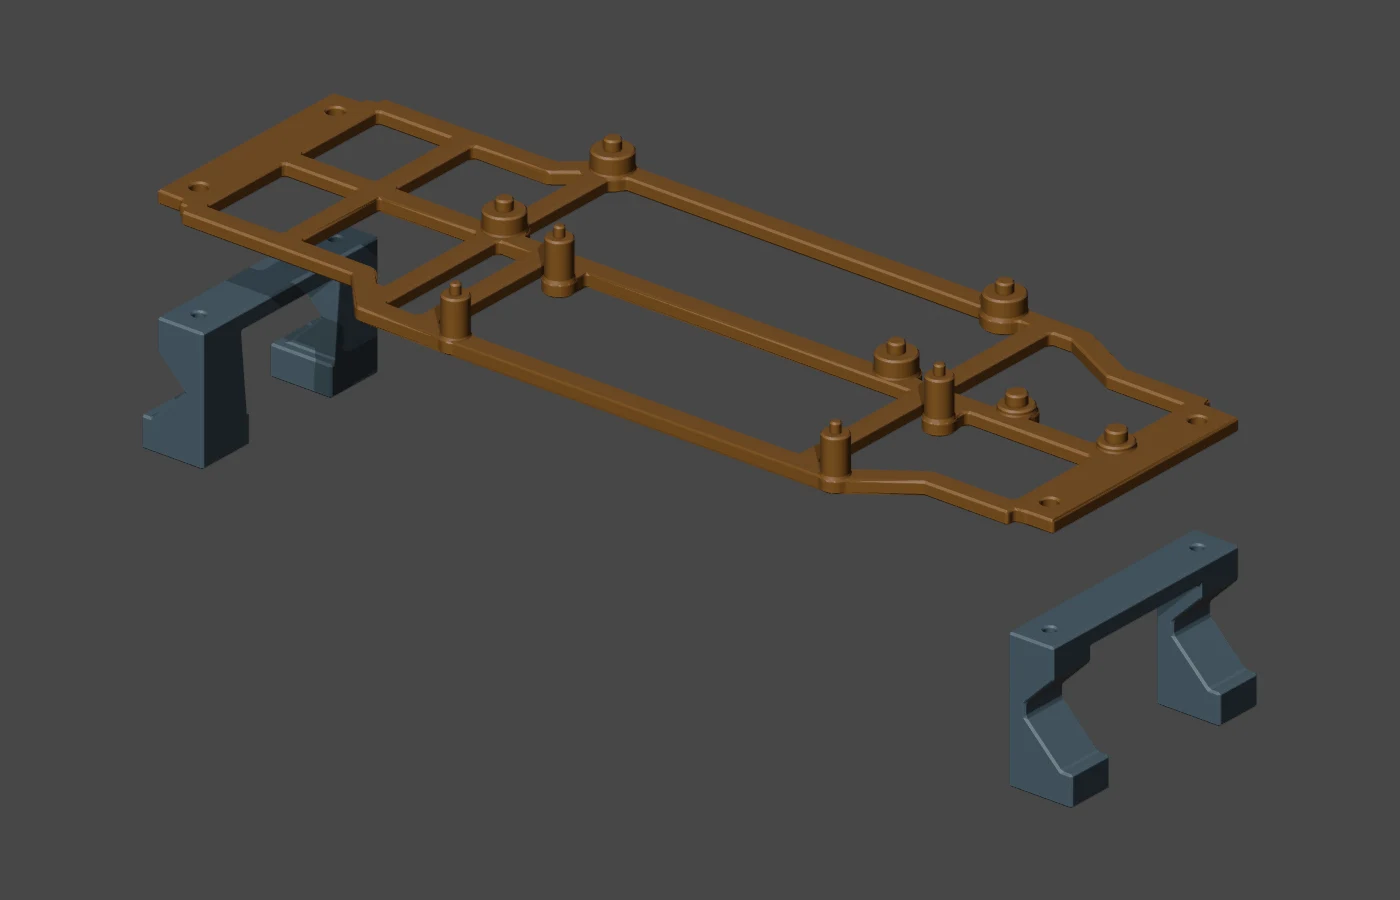
Chassis, shell & powerIndependent Wired and Wireless Blender designs, an 82.5 mm Wireless frame, revised front-leg placement, rear carrier relief, a fitted LCD carrier and assembly reference marks.
Chassis, shell & powerAinekio splits into an onboard-Q6A Wired build and an offboard-Q6A Wireless build. ROS 2, local IMU feedback and the new battery budget have distinct implementation stages.
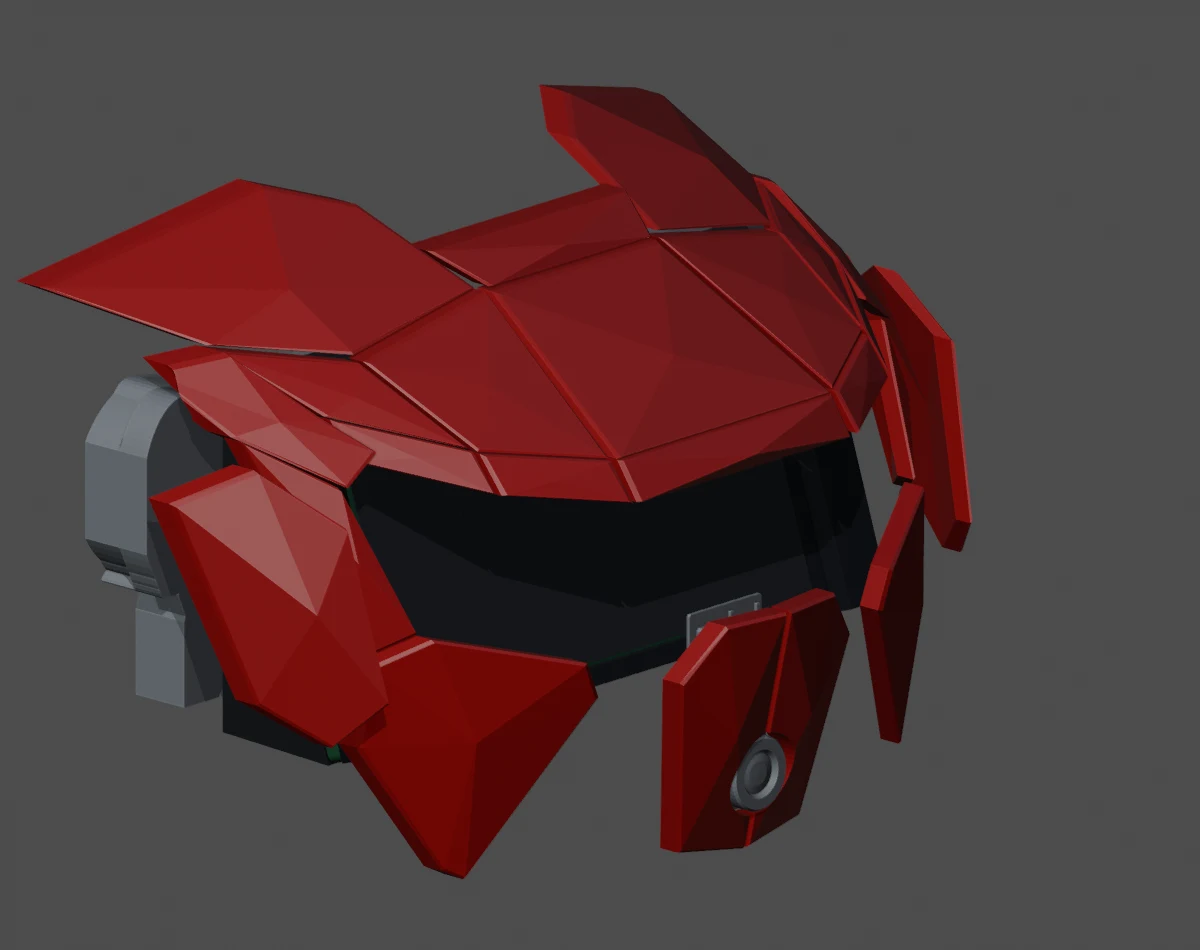
Firmware & connectionsA red shell, revised mask mounts, reinforced printed tabs and an 80 mm chassis placement: fitting a removable 10,000 mAh Anker bank beneath Ainekio V2.
Chassis, shell & powerThe 103-to-51.2 mm chassis revision, board-clearance measurements, and a camera-cable recess moved beneath the face.
Chassis, shell & powerComparing the 24/41/60 and 22/36/55 mm legs, retaining tested articulation, and correcting a horn cavity after a failed printed fit.
Legs & gaitAinekio's evolving face, collar, roof and fins, with actual CAD views and a record of accepted and rejected design iterations.
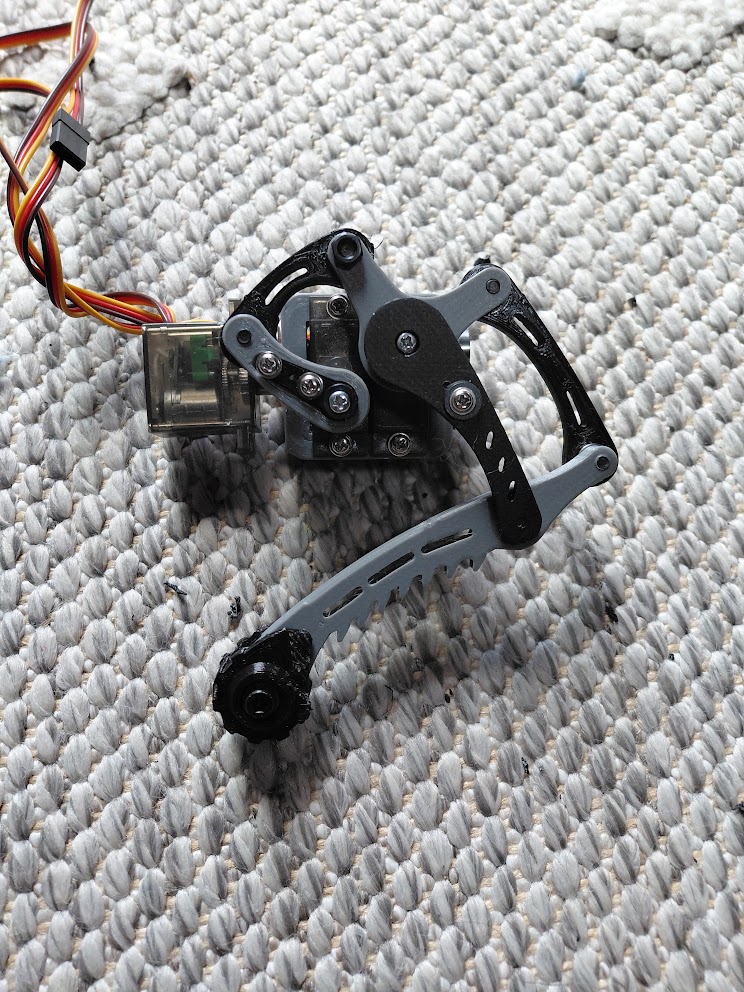
Chassis, shell & powerPrinted leg prototypes with expressive movement, revised linkage geometry, horn pockets sized from real hardware, and fit lessons for the next iteration.
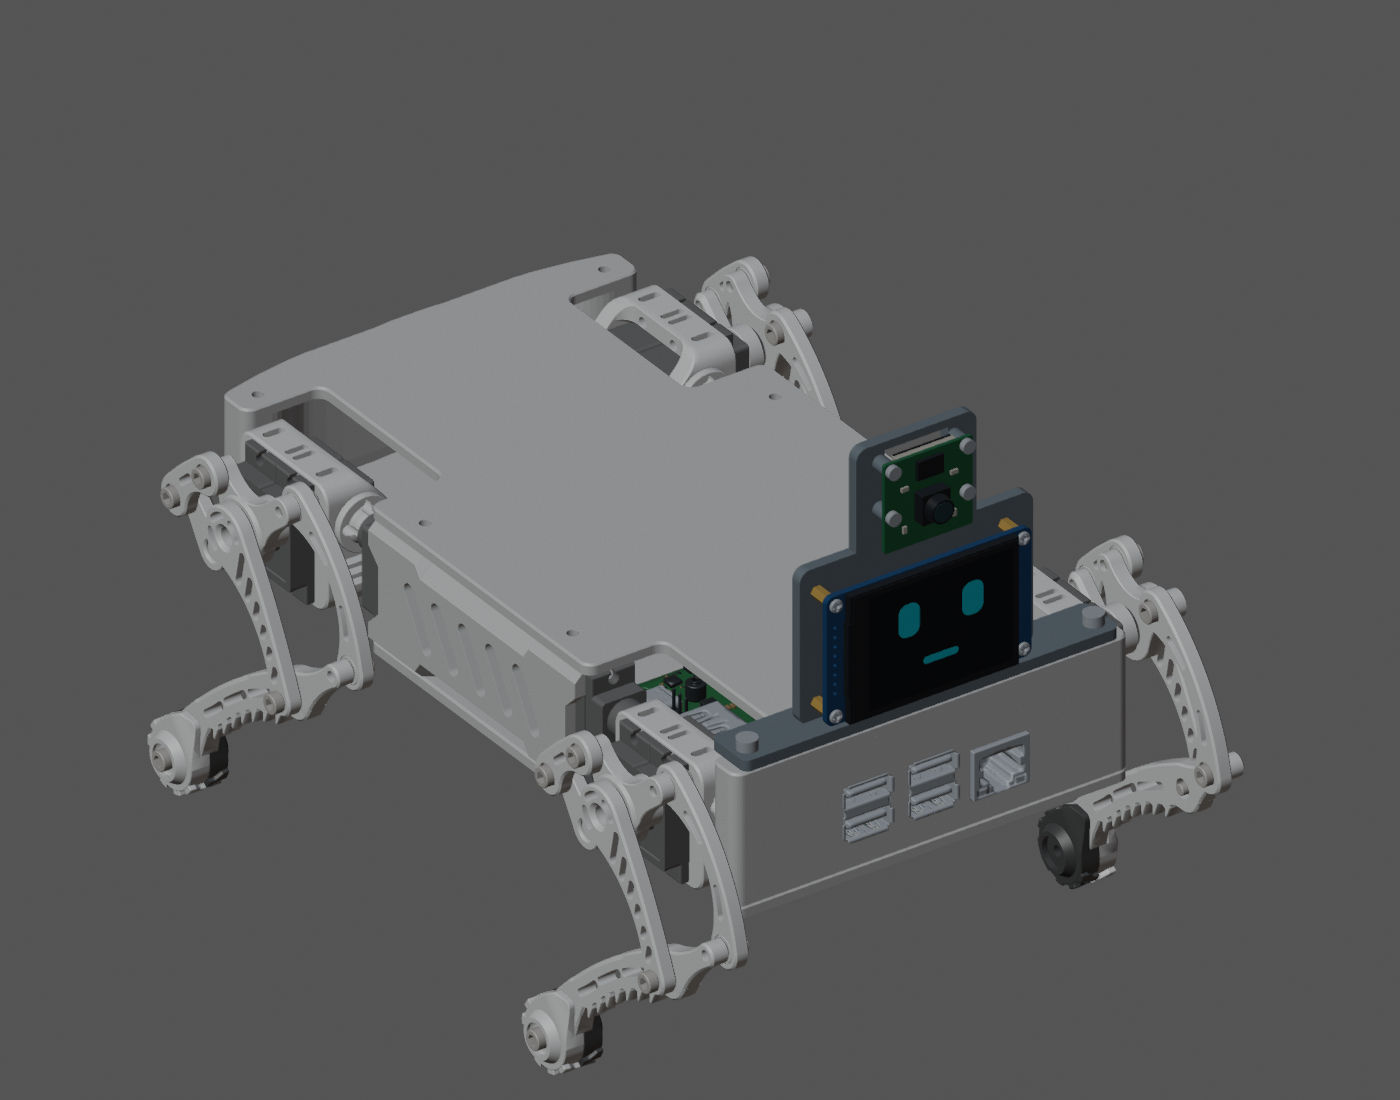
Legs & gaitFourteen CAD revisions: chassis, electronics, linkages, covers, and a camera/display carrier, with a brief MetaHuman OS refinement update.
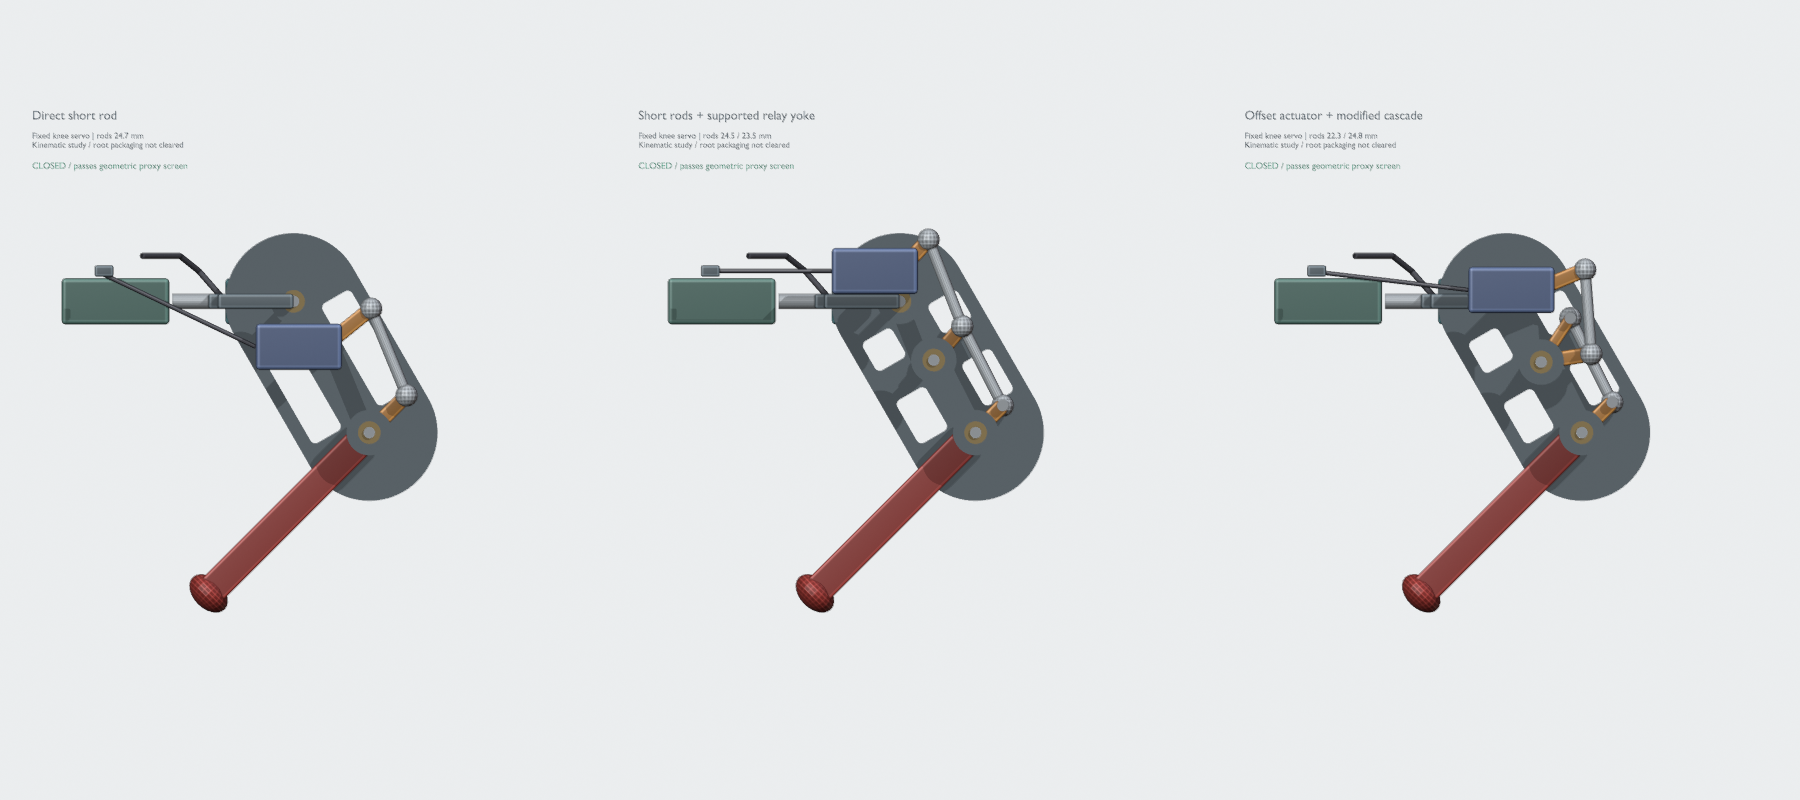
Chassis, shell & powerA direct pushrod, a supported relay yoke, and an offset cascade compared by rod length, modeled range, pose coverage, and interference.
Legs & gaitSaved workflows, robot-command recovery, finite Desire plans, and the latest live-run evidence alongside the V2 hardware work.
Understanding AinekioThe July ESP32-S3 firmware record: eight servo outputs, startup, safety, media, and build steps.
Original eight-servo robotThe original software architecture, cognition, command bridge, validation, and development plans.
Original eight-servo robotThe original eight-servo parts, power, wiring, fitment, and shopping-list document.
Original eight-servo robotThe original July 10 progress snapshot and reading map, preserved as an early project record.
Original eight-servo robotOriginal design deliberations: controller alternatives, power, communications, fitment, and early Generation 2 candidates.
Original eight-servo robotHistorical notes on the early Megameal conversation bridge, its test results, and its original implementation.
Original eight-servo robotThe unsuccessful simulator project: its original command bridge, discarded hardware plans, and reported July tests.
Original eight-servo robotThe original project introduction, its ambitions, MetaHuman brain, firmware boundary, and Sesame-derived body.
Original eight-servo robotNo articles match these filters. Try another topic, version, or search phrase.