The build, in pictures
Meet the robot
Printed parts, exposed wiring, experiments on the floor—and the design work behind them. This is Ainekio as it takes shape.
The latest photographs show the October 21 assembly. Read about the rebuilt body, new face and measured standing.
From the workbench
Real photographs of the build: the October rebuild, leg prototypes and the earlier robot.
Photograph ·
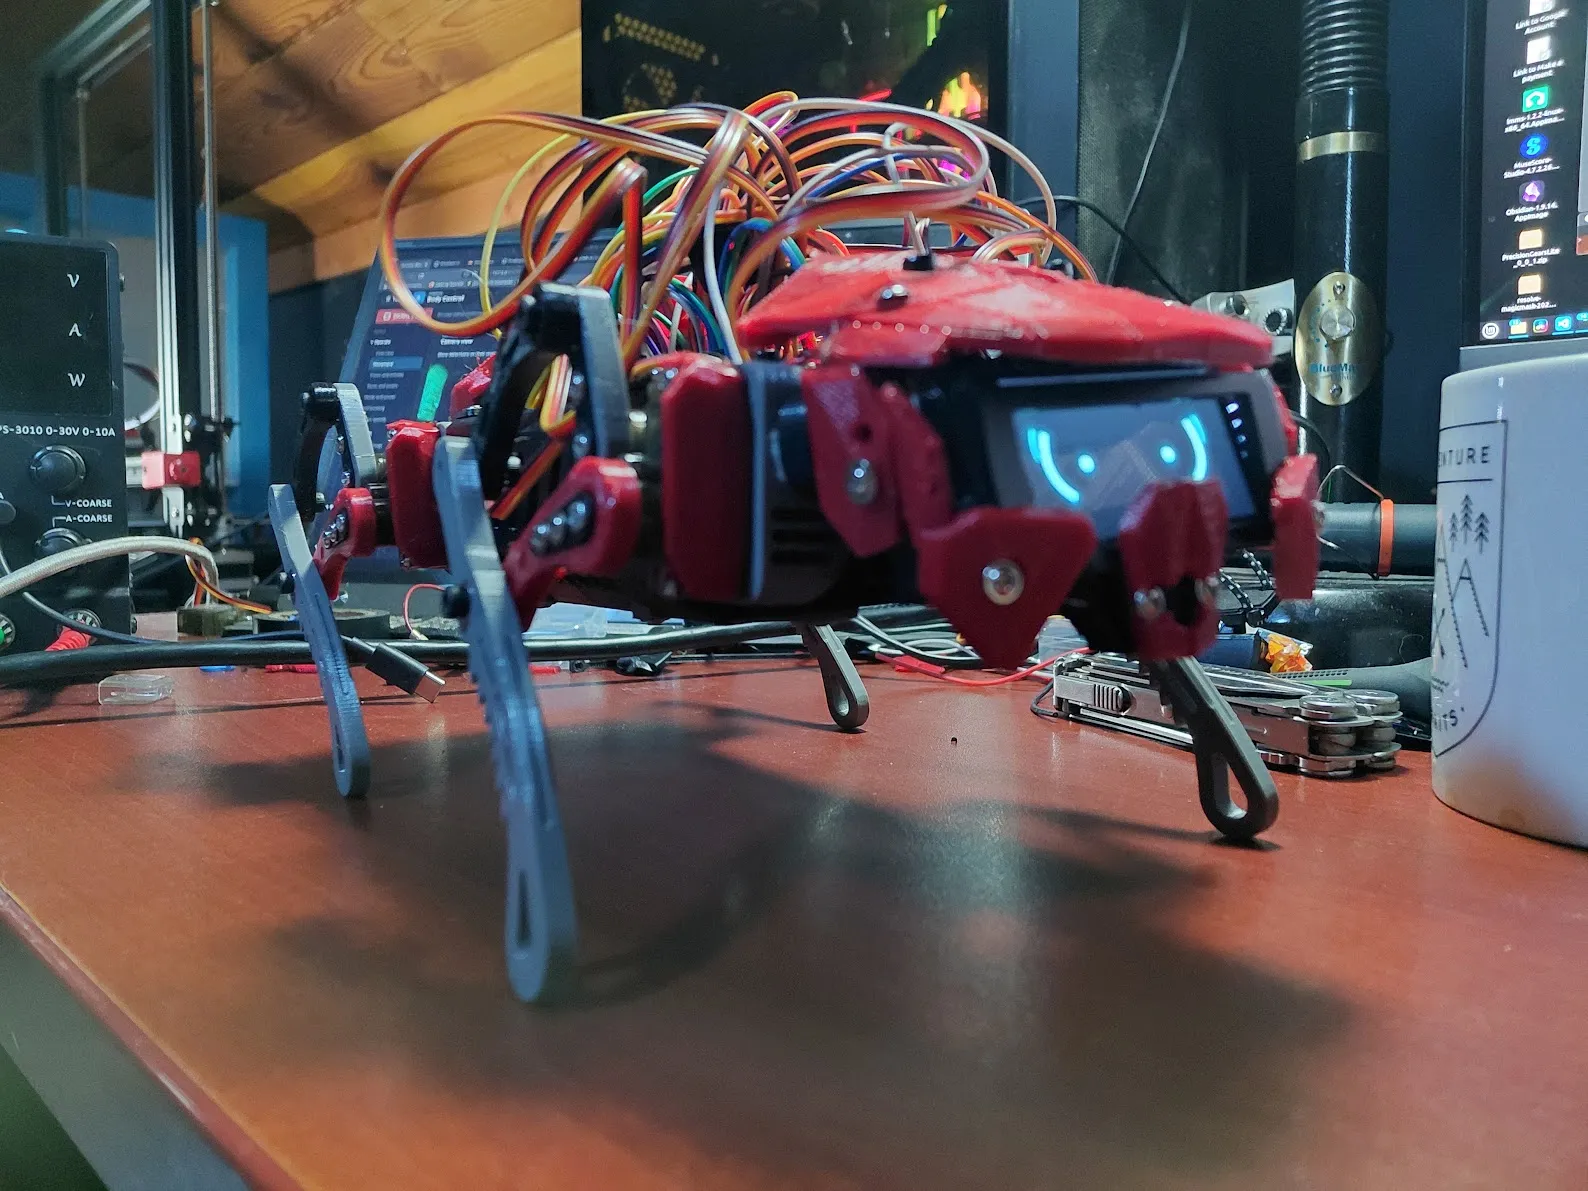
The rebuilt robot, front view
The assembled V2 prototype on the October 21 workbench, with its red face surround, illuminated display and exposed upper wiring.
Photograph ·
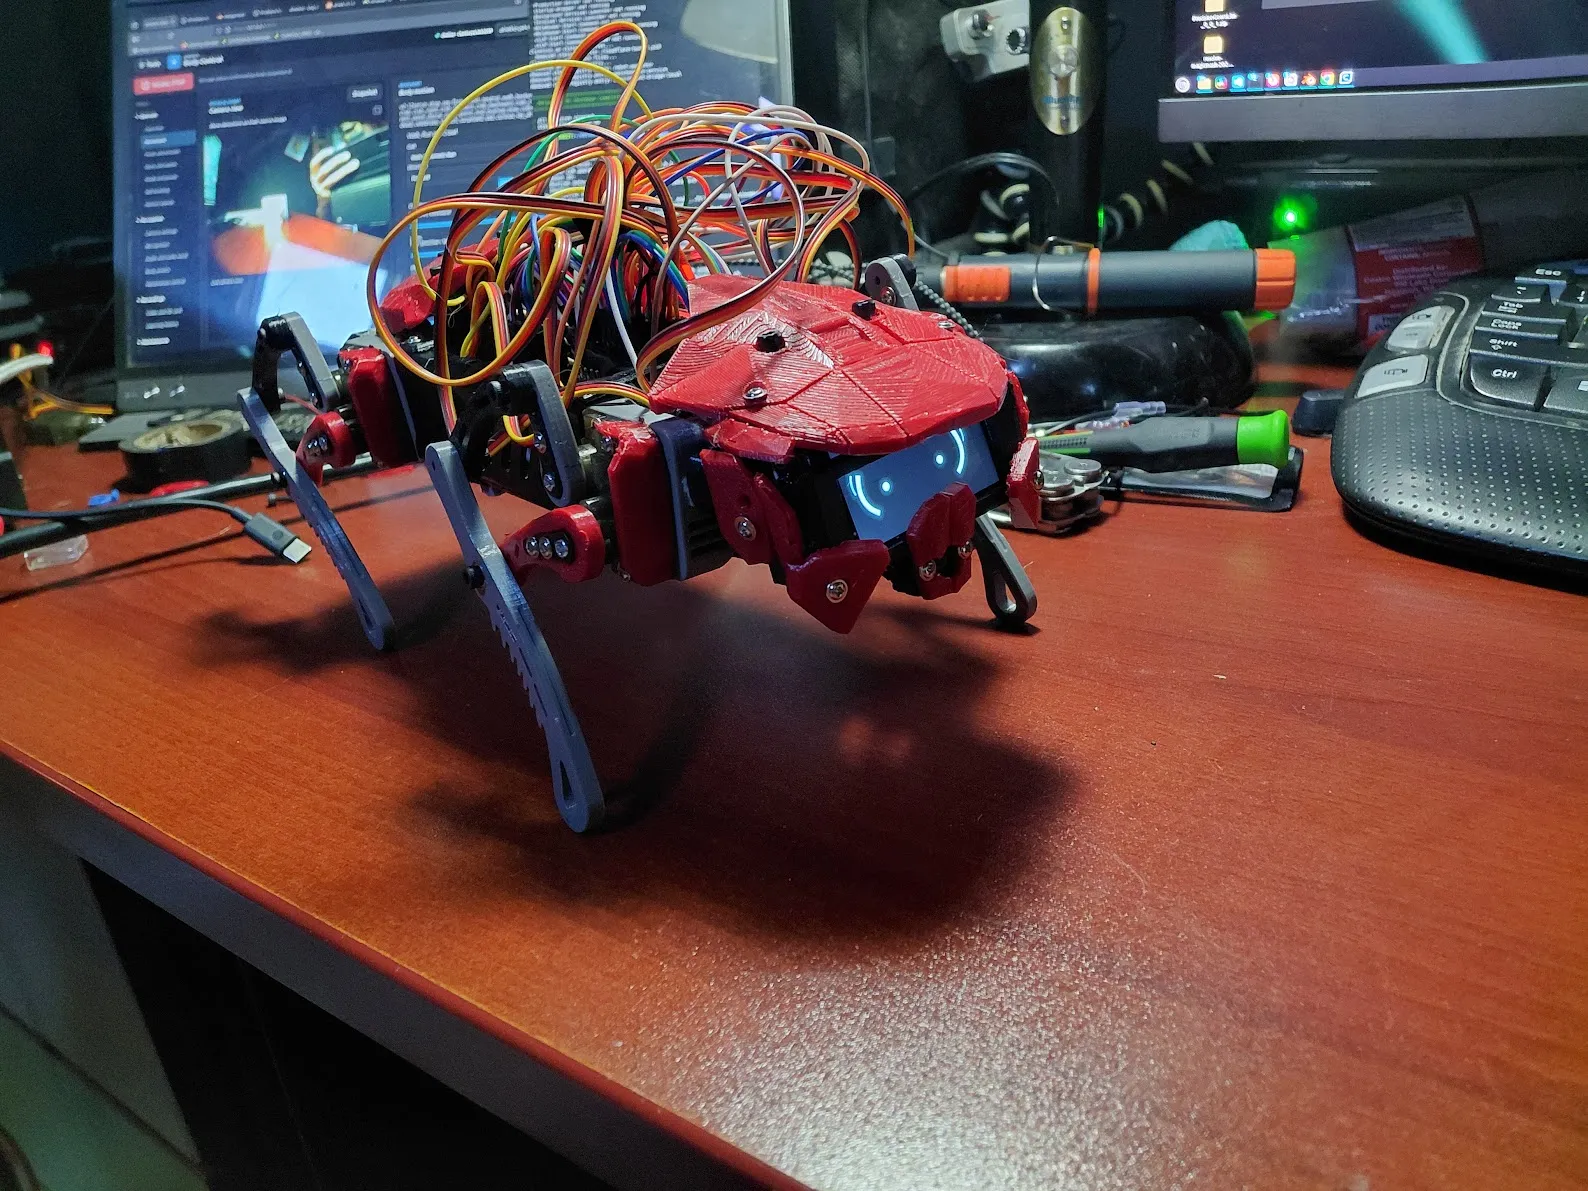
Red shell and revised face
A three-quarter view of the rebuilt body and its four linkage legs on the workbench.
Photograph ·
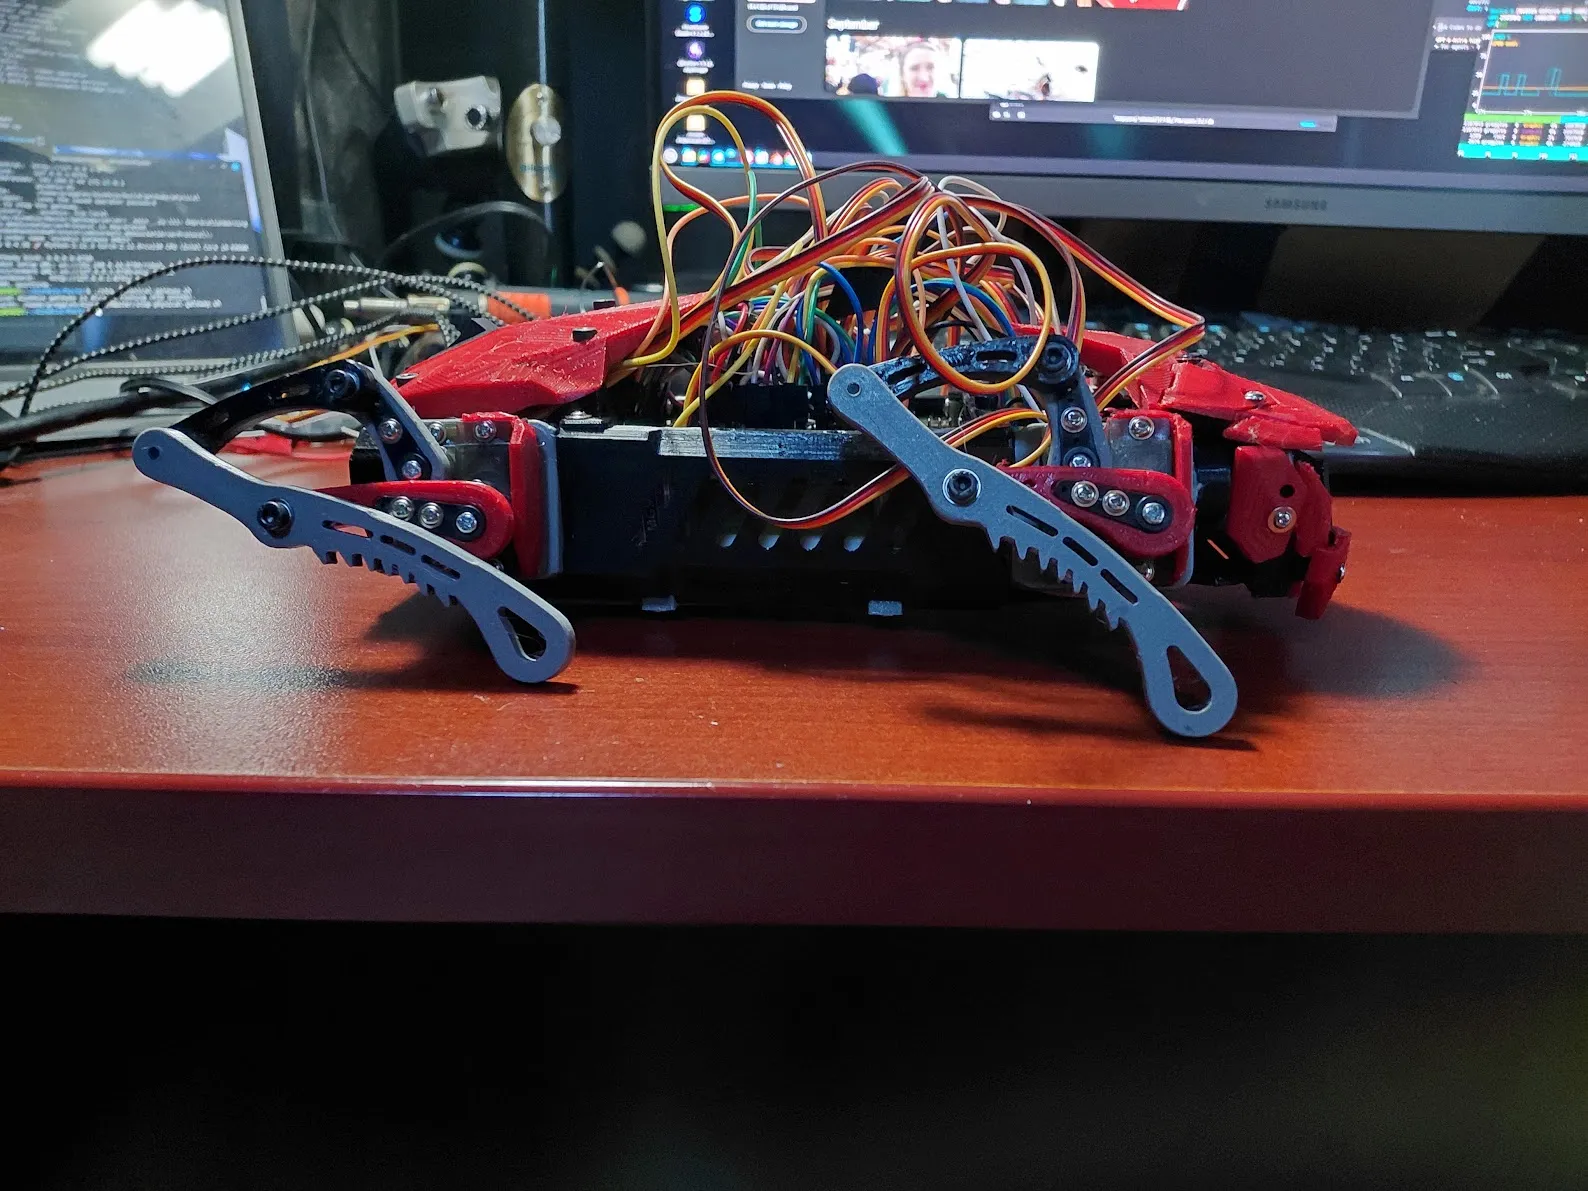
A low stance, from the side
The October 21 prototype in a low stance, showing its side frame, leg mechanisms and new red body pieces.
Photograph ·
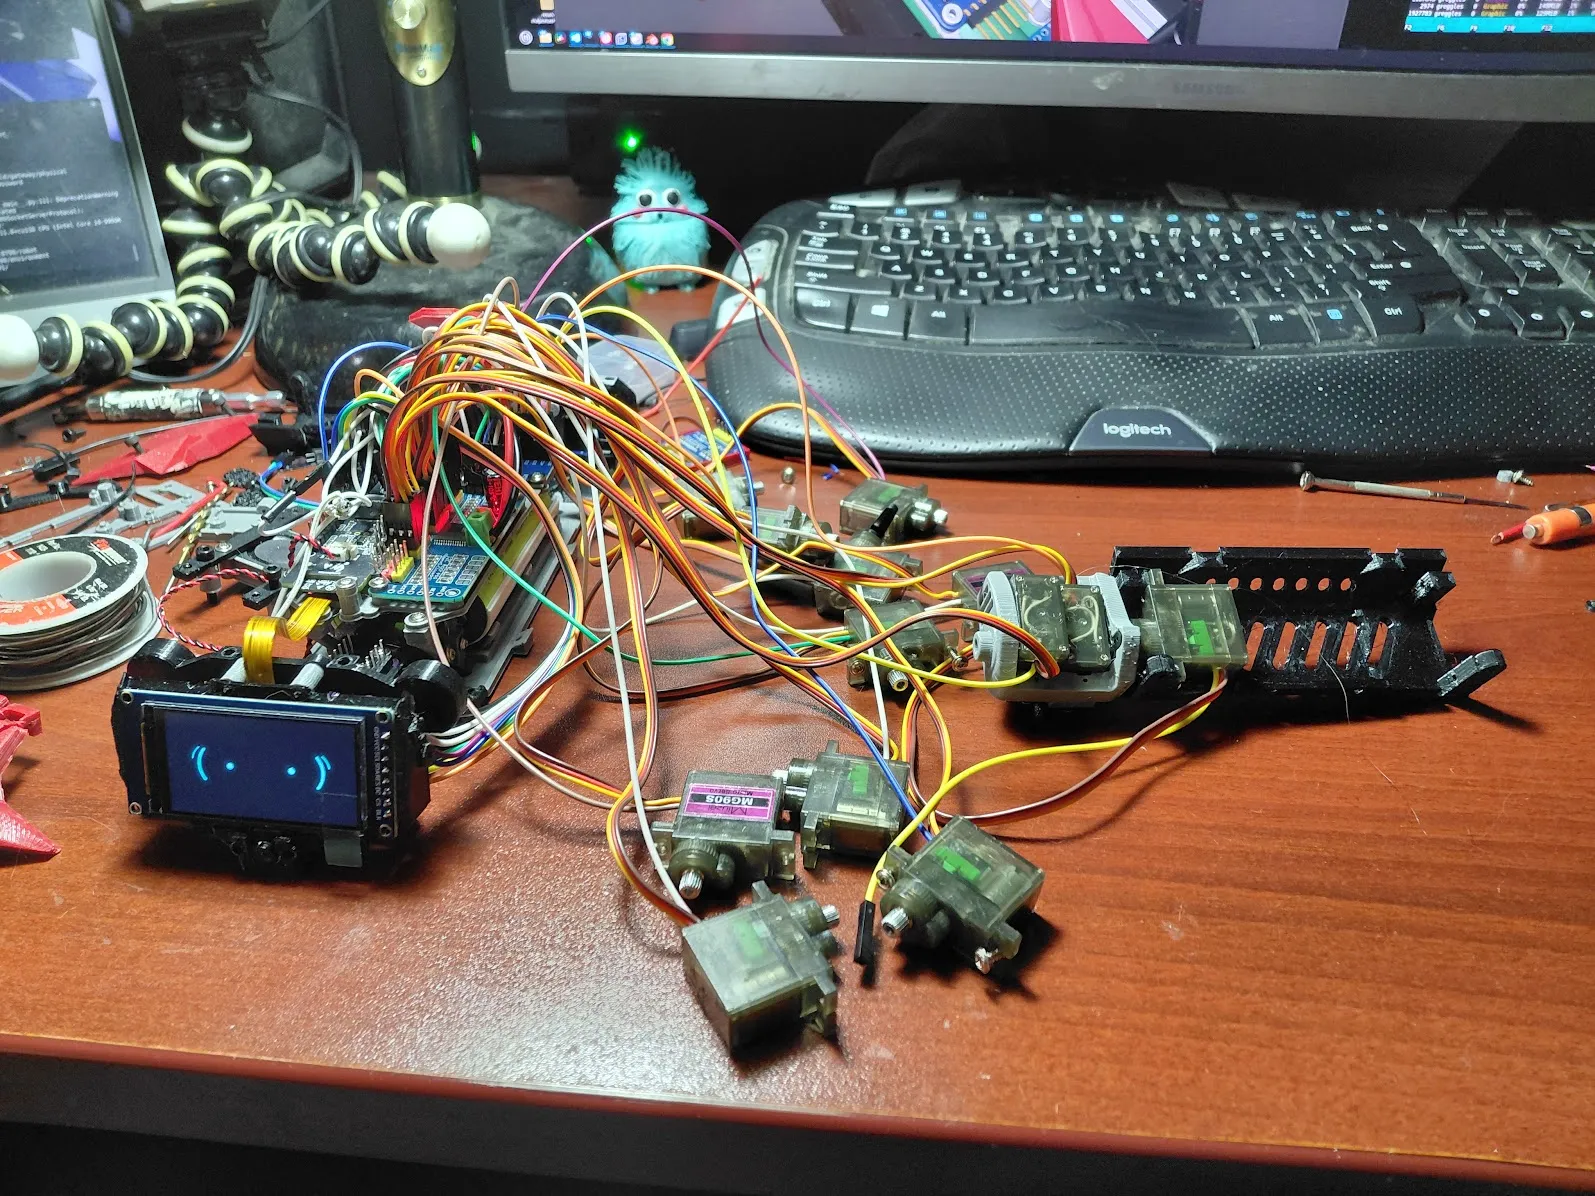
Servo wiring on the workbench
The open body, wiring and servos laid out during the feedback-servo rebuild.
Photograph ·
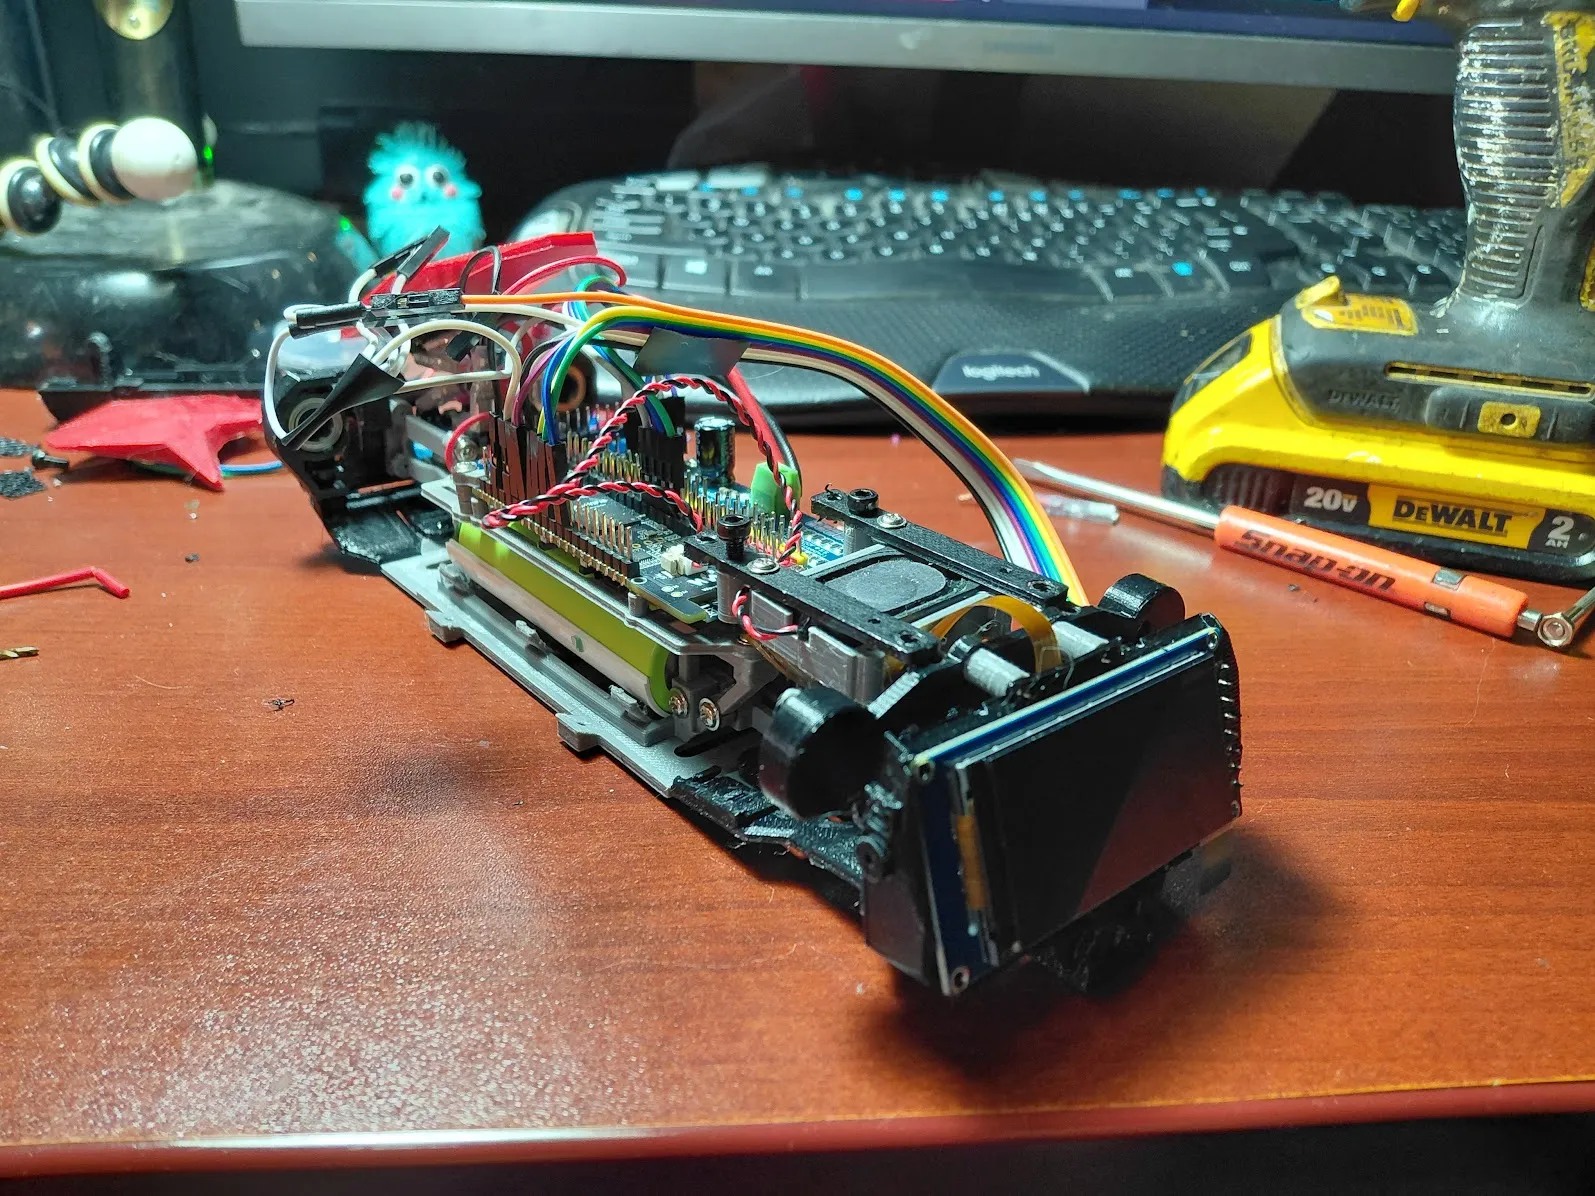
Inside the revised chassis
The open chassis on the workbench, with its display, electronics and wiring exposed.
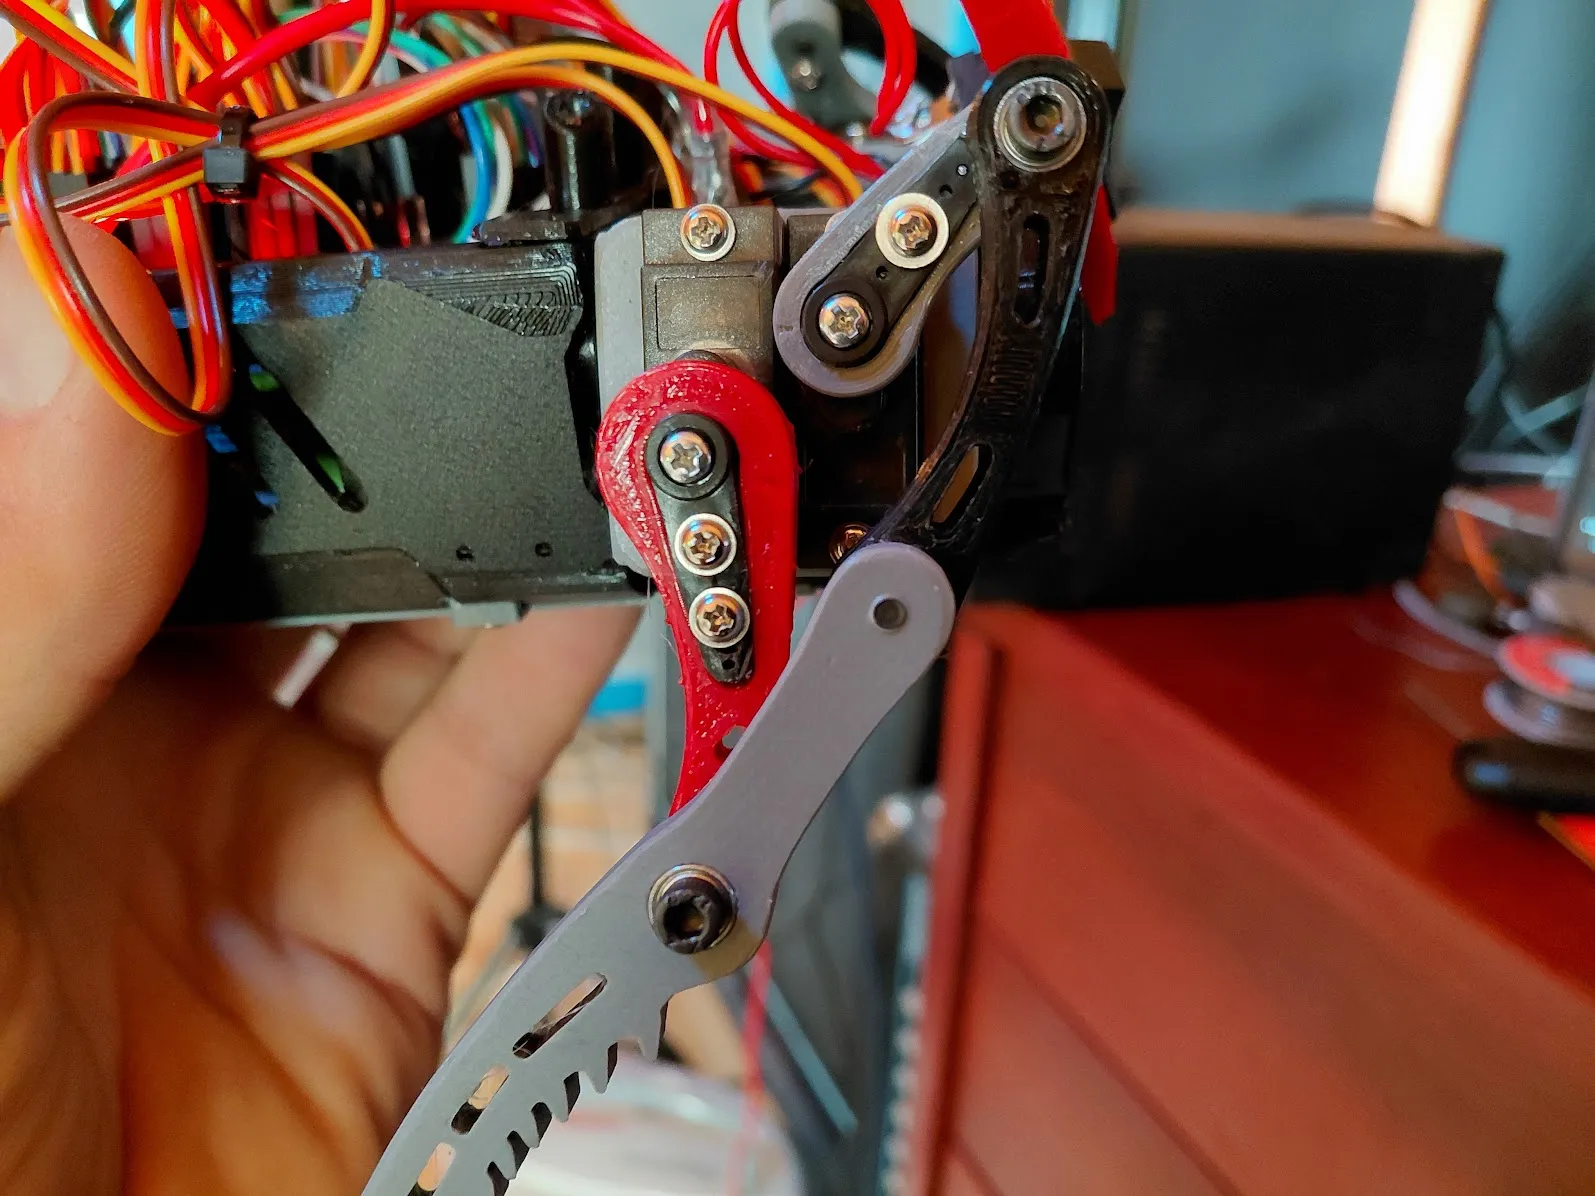
Photograph ·
A closer look at the leg
A hand-held view of the printed leg carrier, linkage and lower leg.
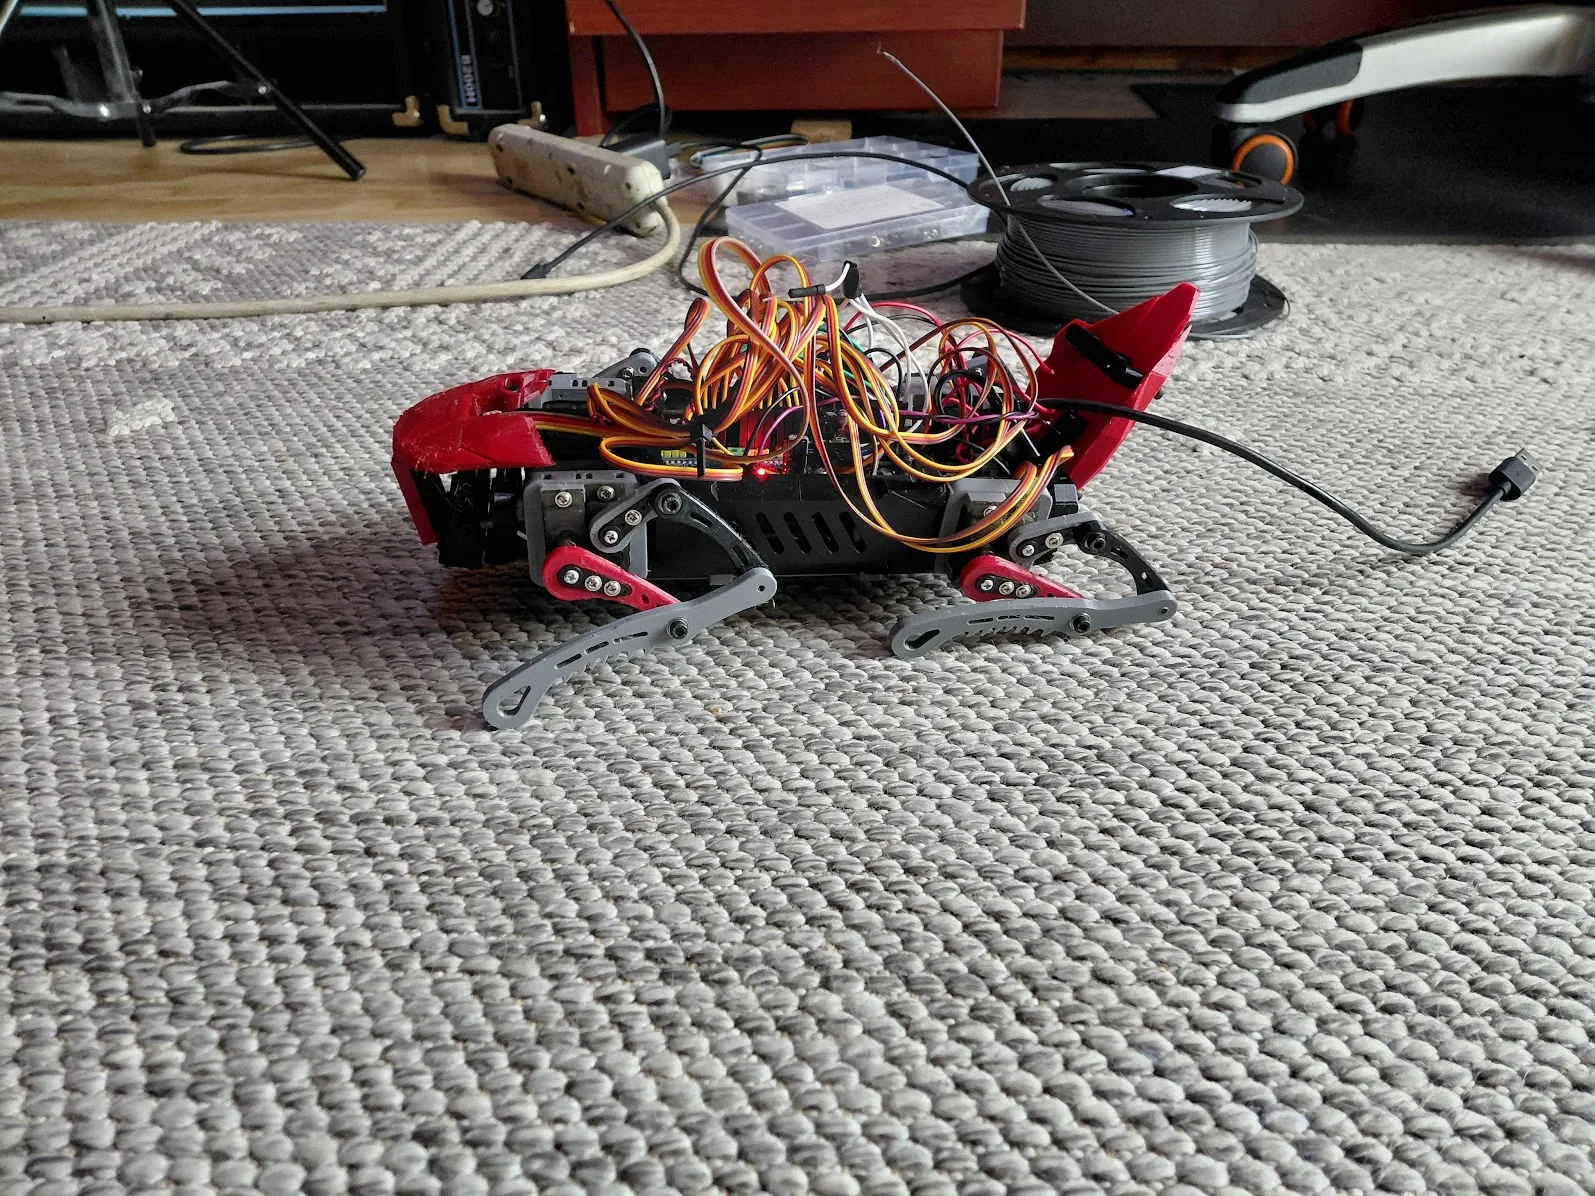
Photograph ·
On the floor
The assembled prototype resting low on the carpet during development.
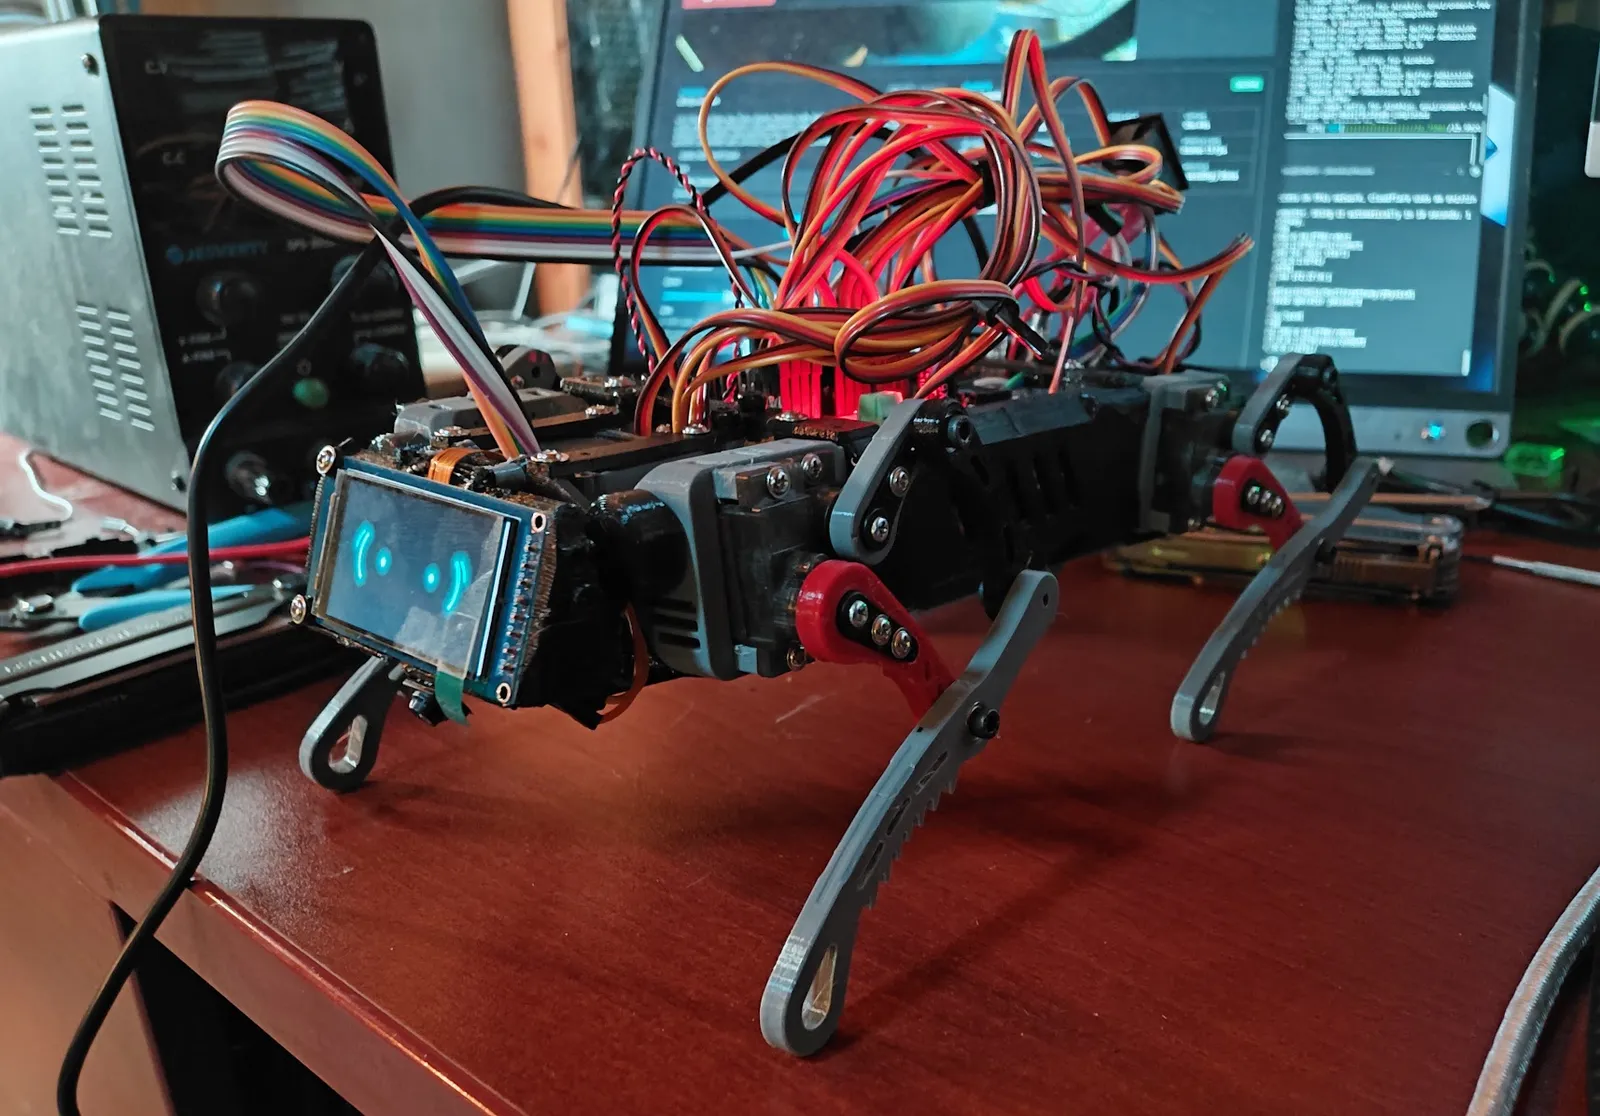
Photograph ·
The October walking build
The uncovered twelve-servo prototype on the bench, with its illuminated face and exposed wiring.
Photograph ·
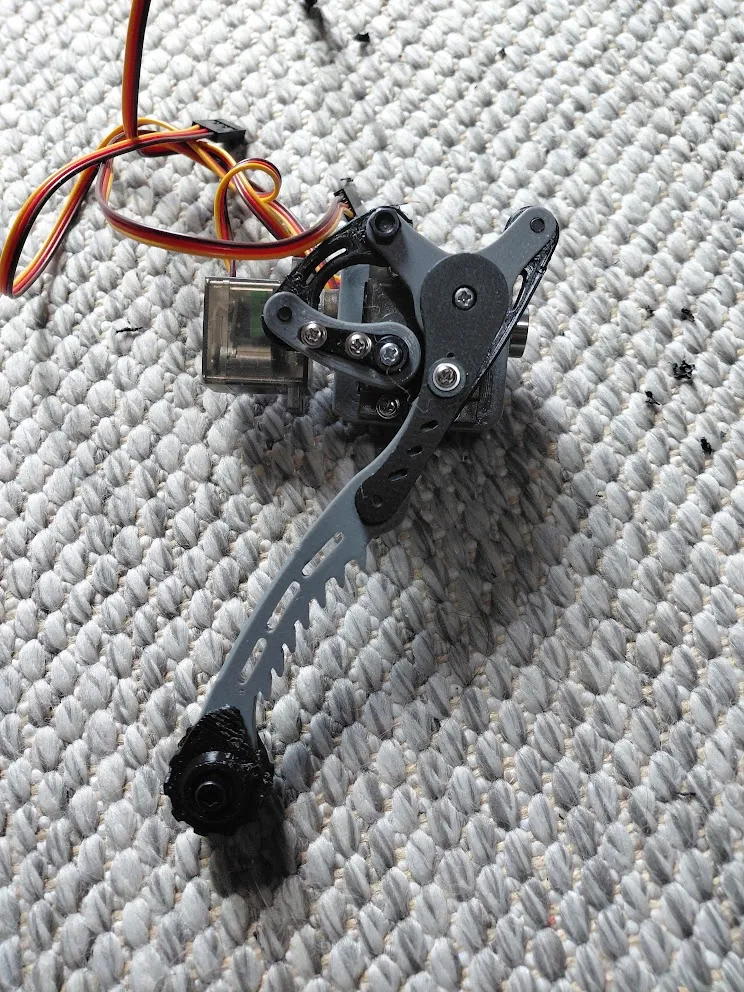
Printed leg prototype
A physical leg mechanism photographed from another angle before the later body revisions.
Photograph ·
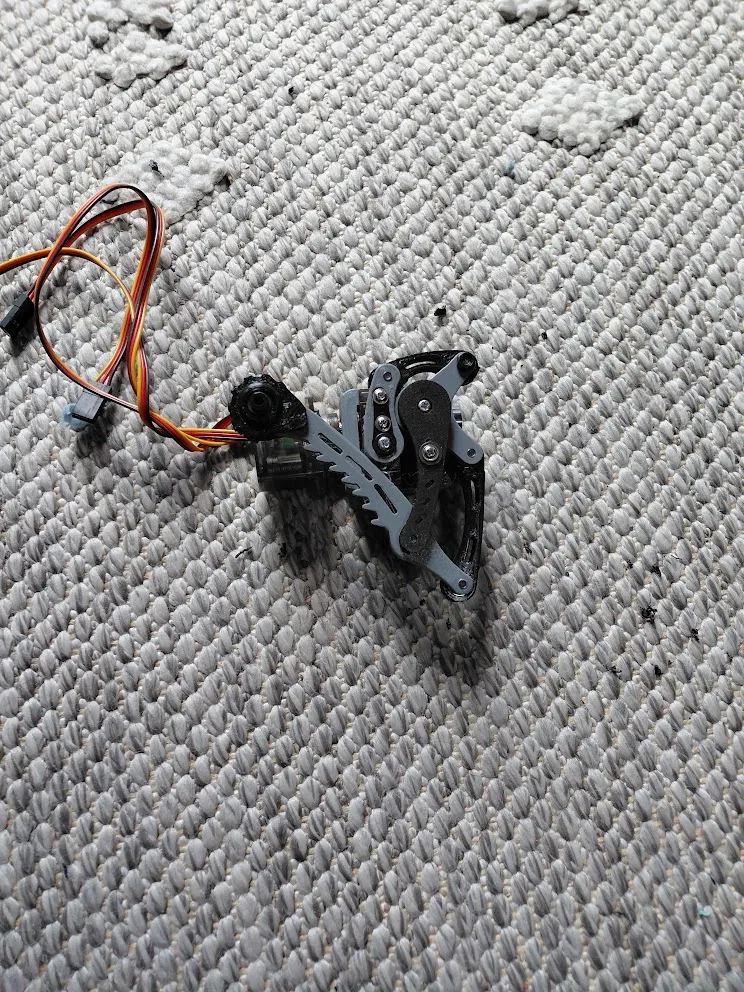
Printed leg prototype
A physical leg mechanism photographed from another angle before the later body revisions.
Photograph ·
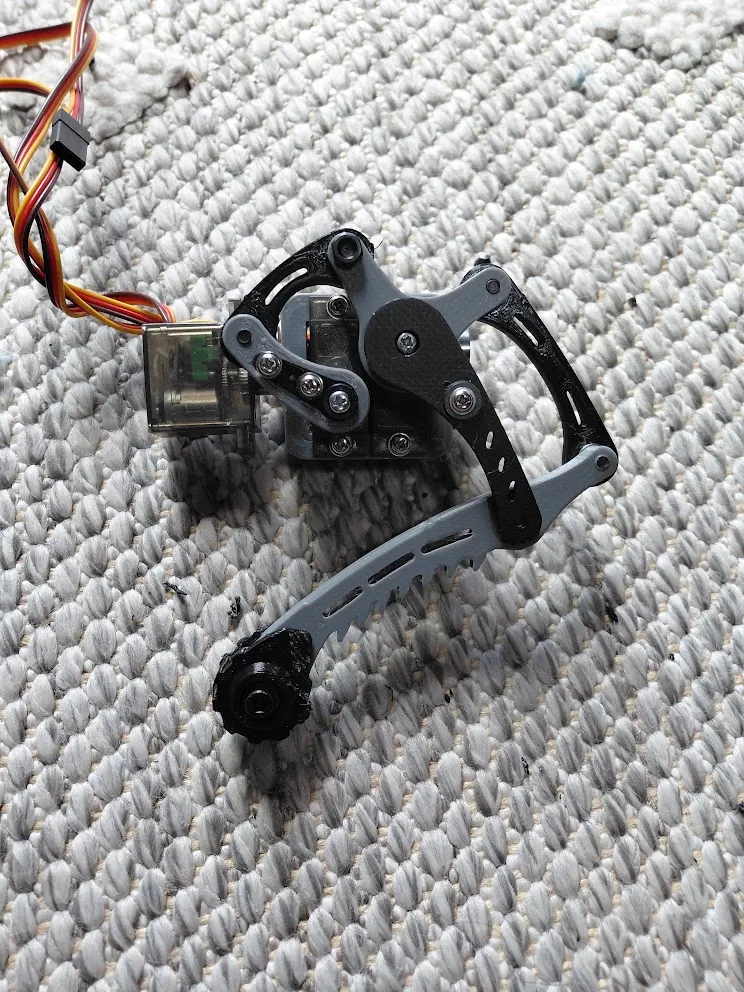
Printed leg prototype
A physical leg mechanism photographed from another angle before the later body revisions.
Photograph ·
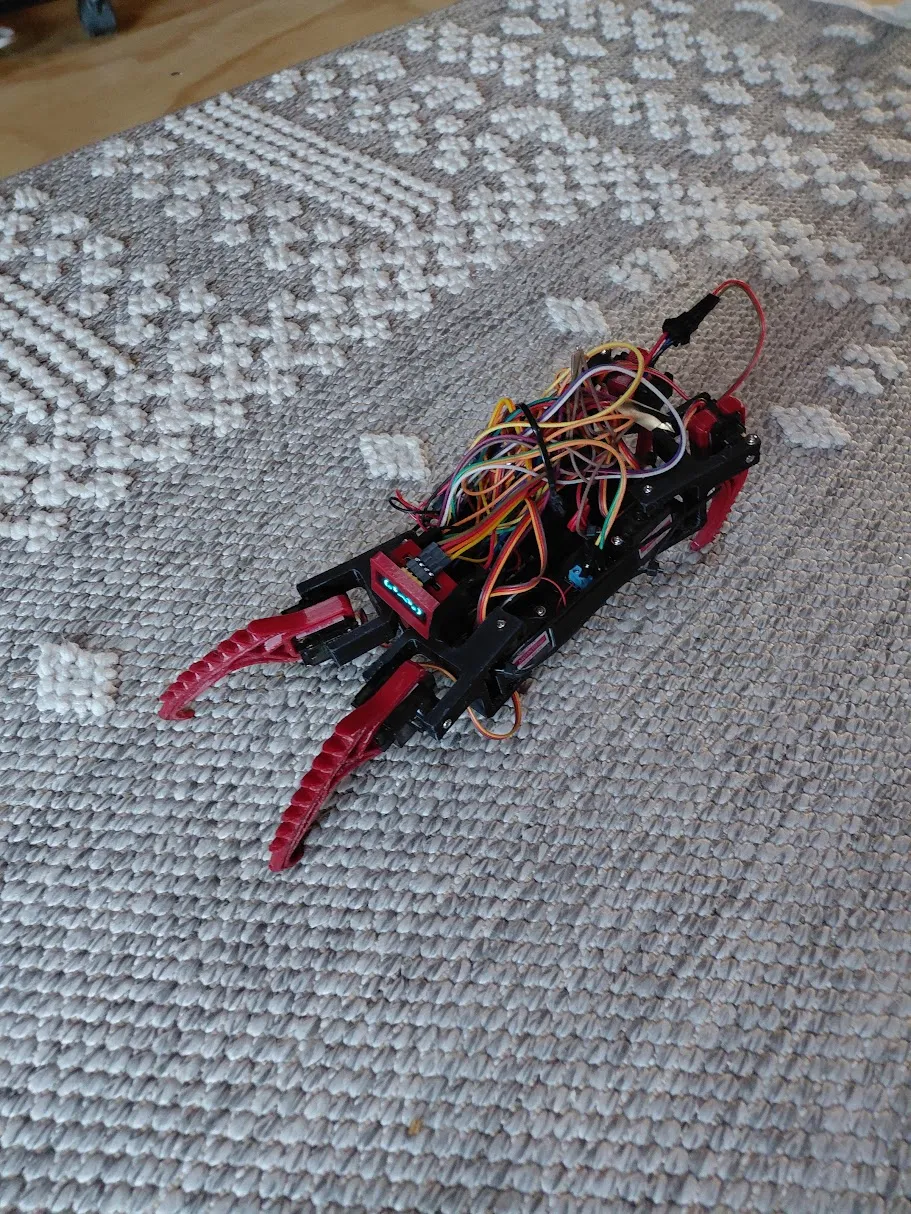
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
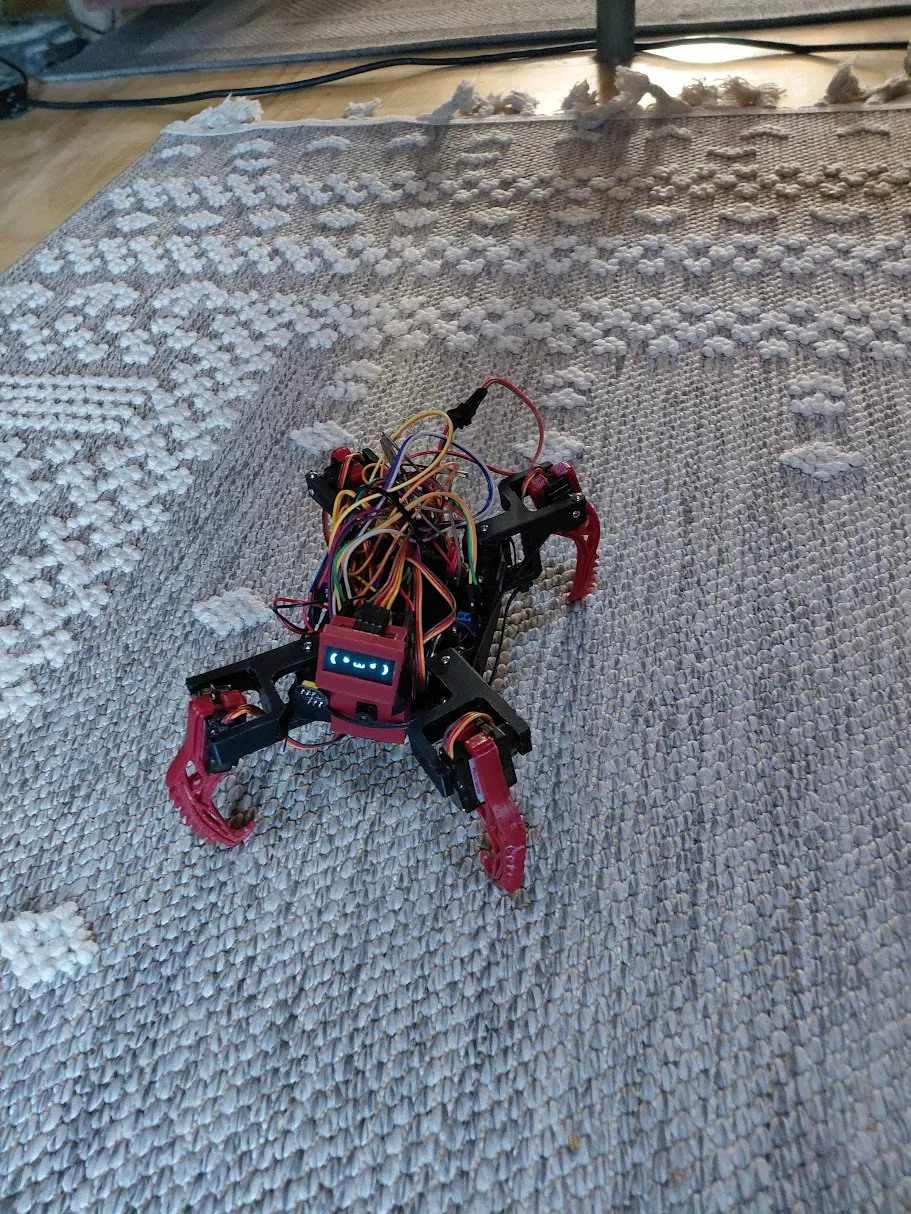
Photograph ·
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
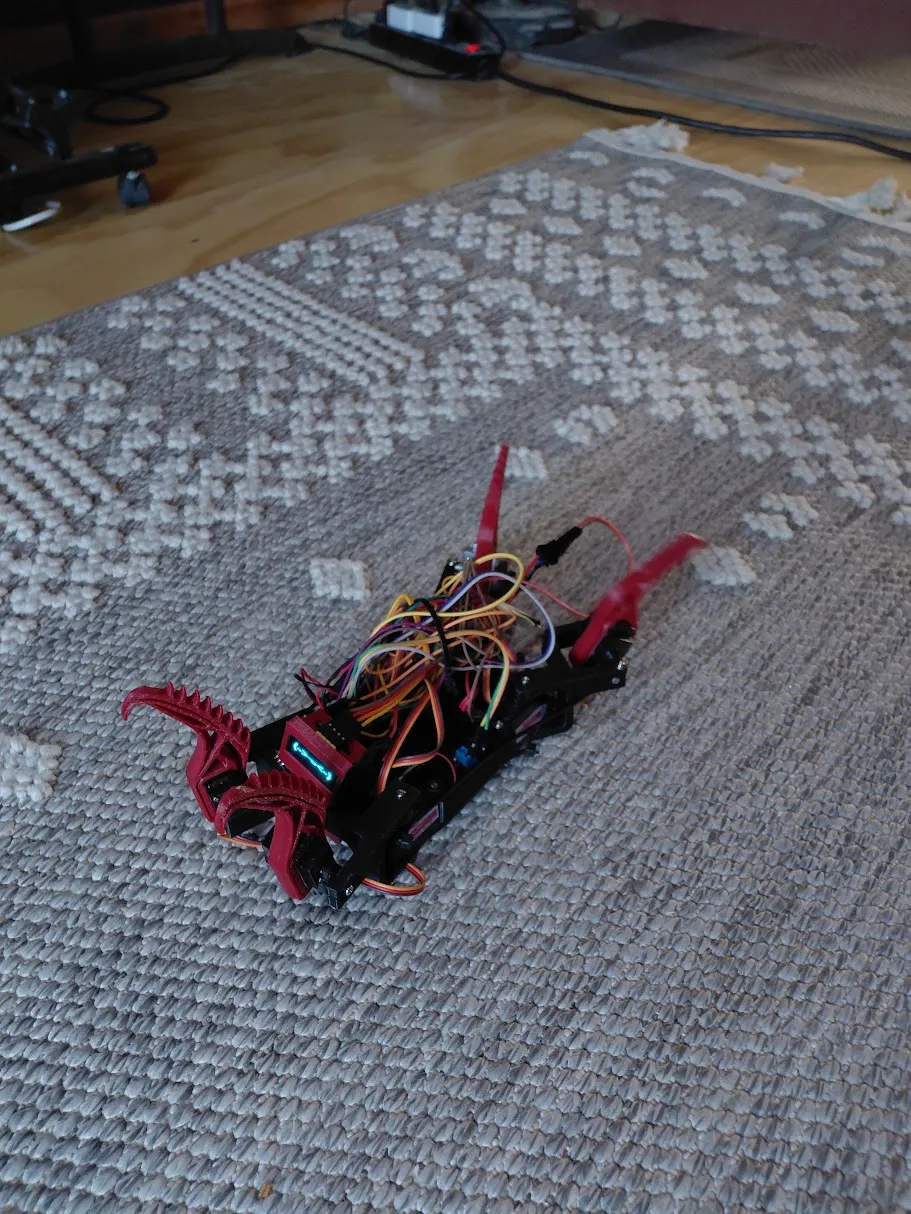
Photograph ·
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
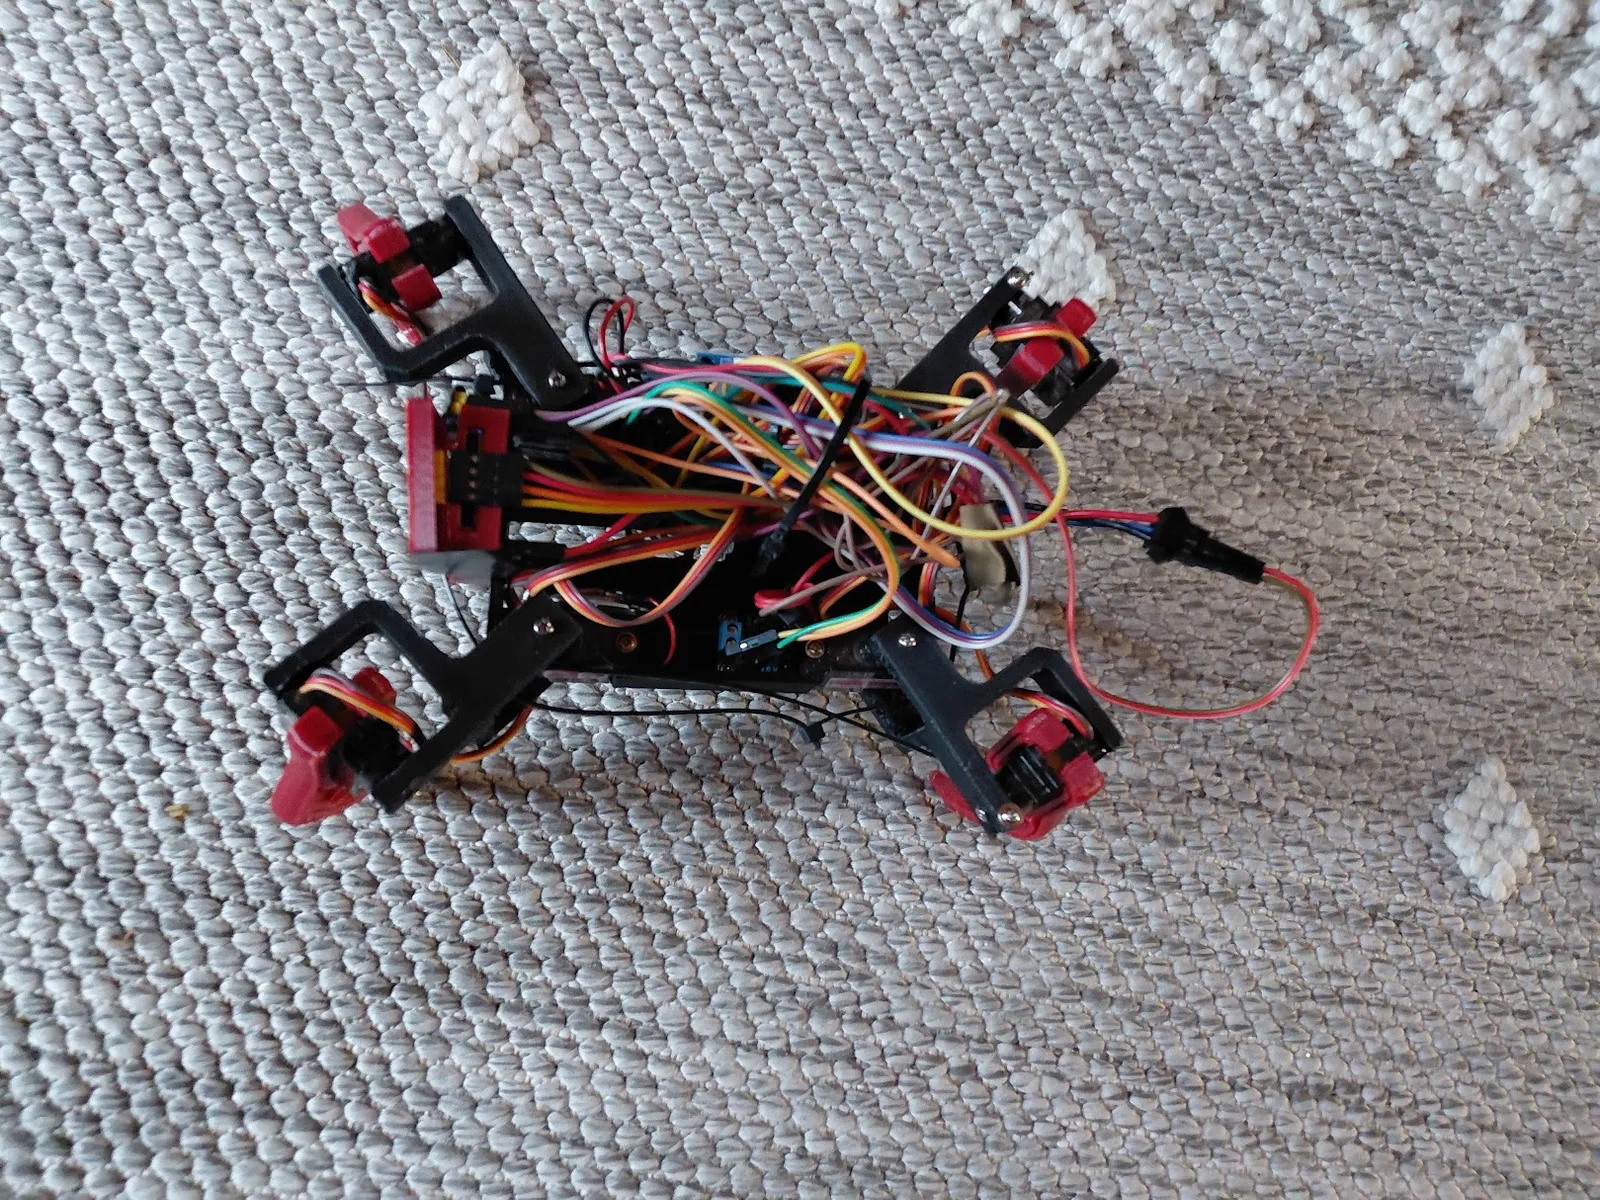
Photograph ·
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
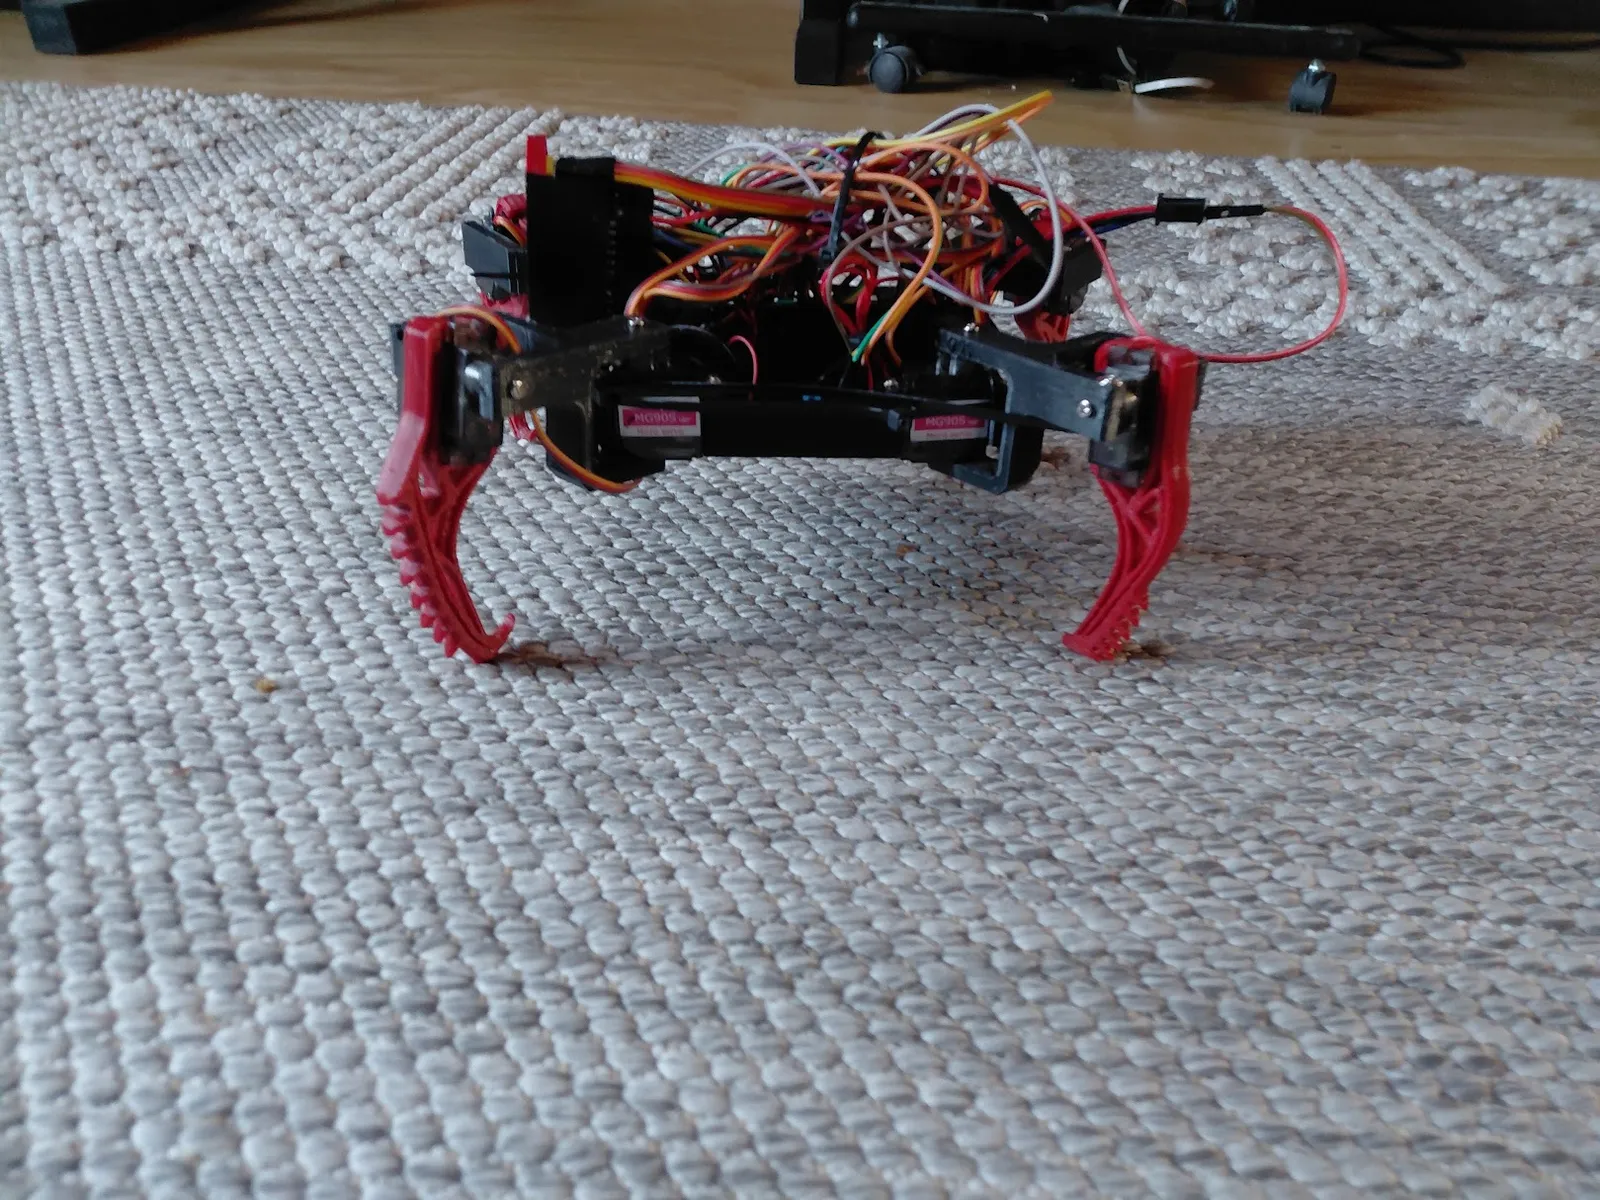
Photograph ·
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
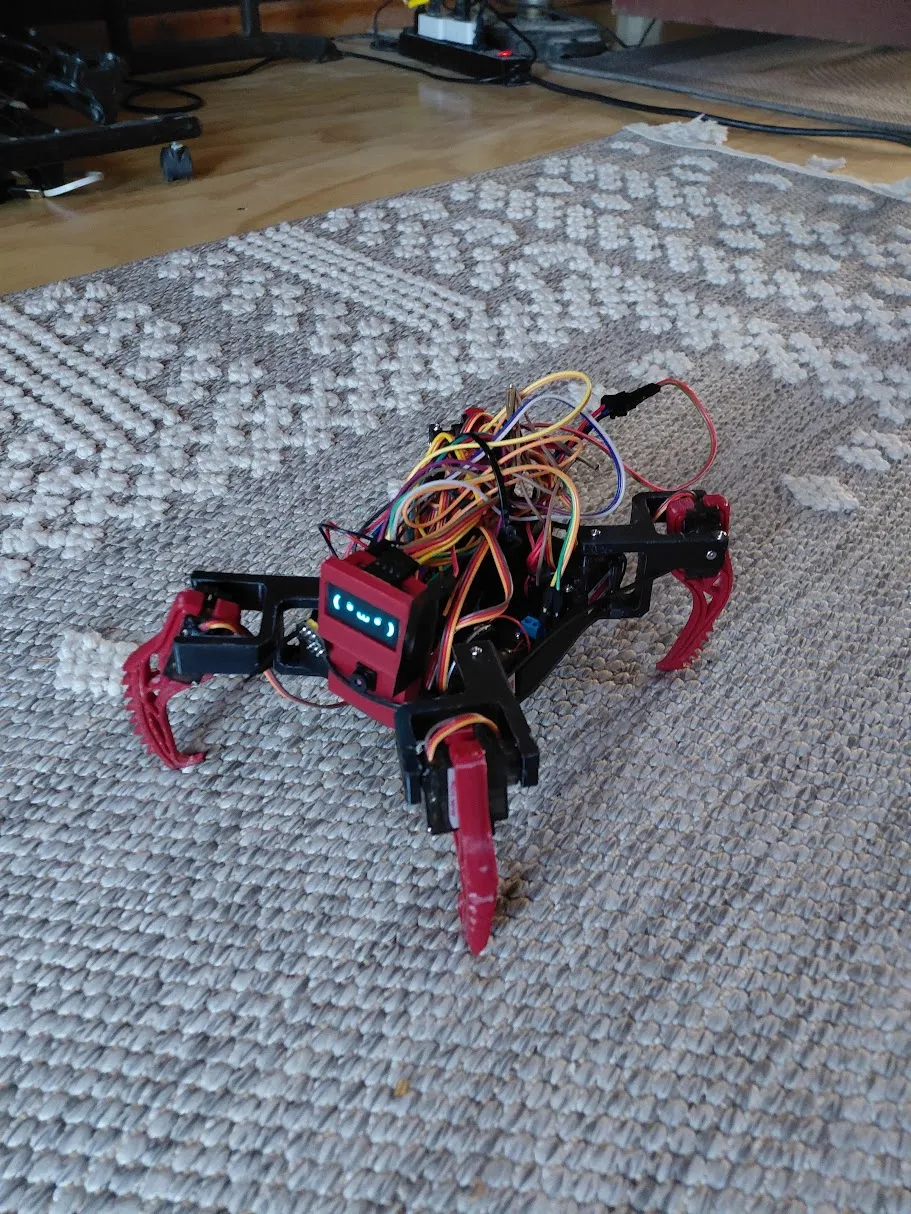
Photograph ·
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
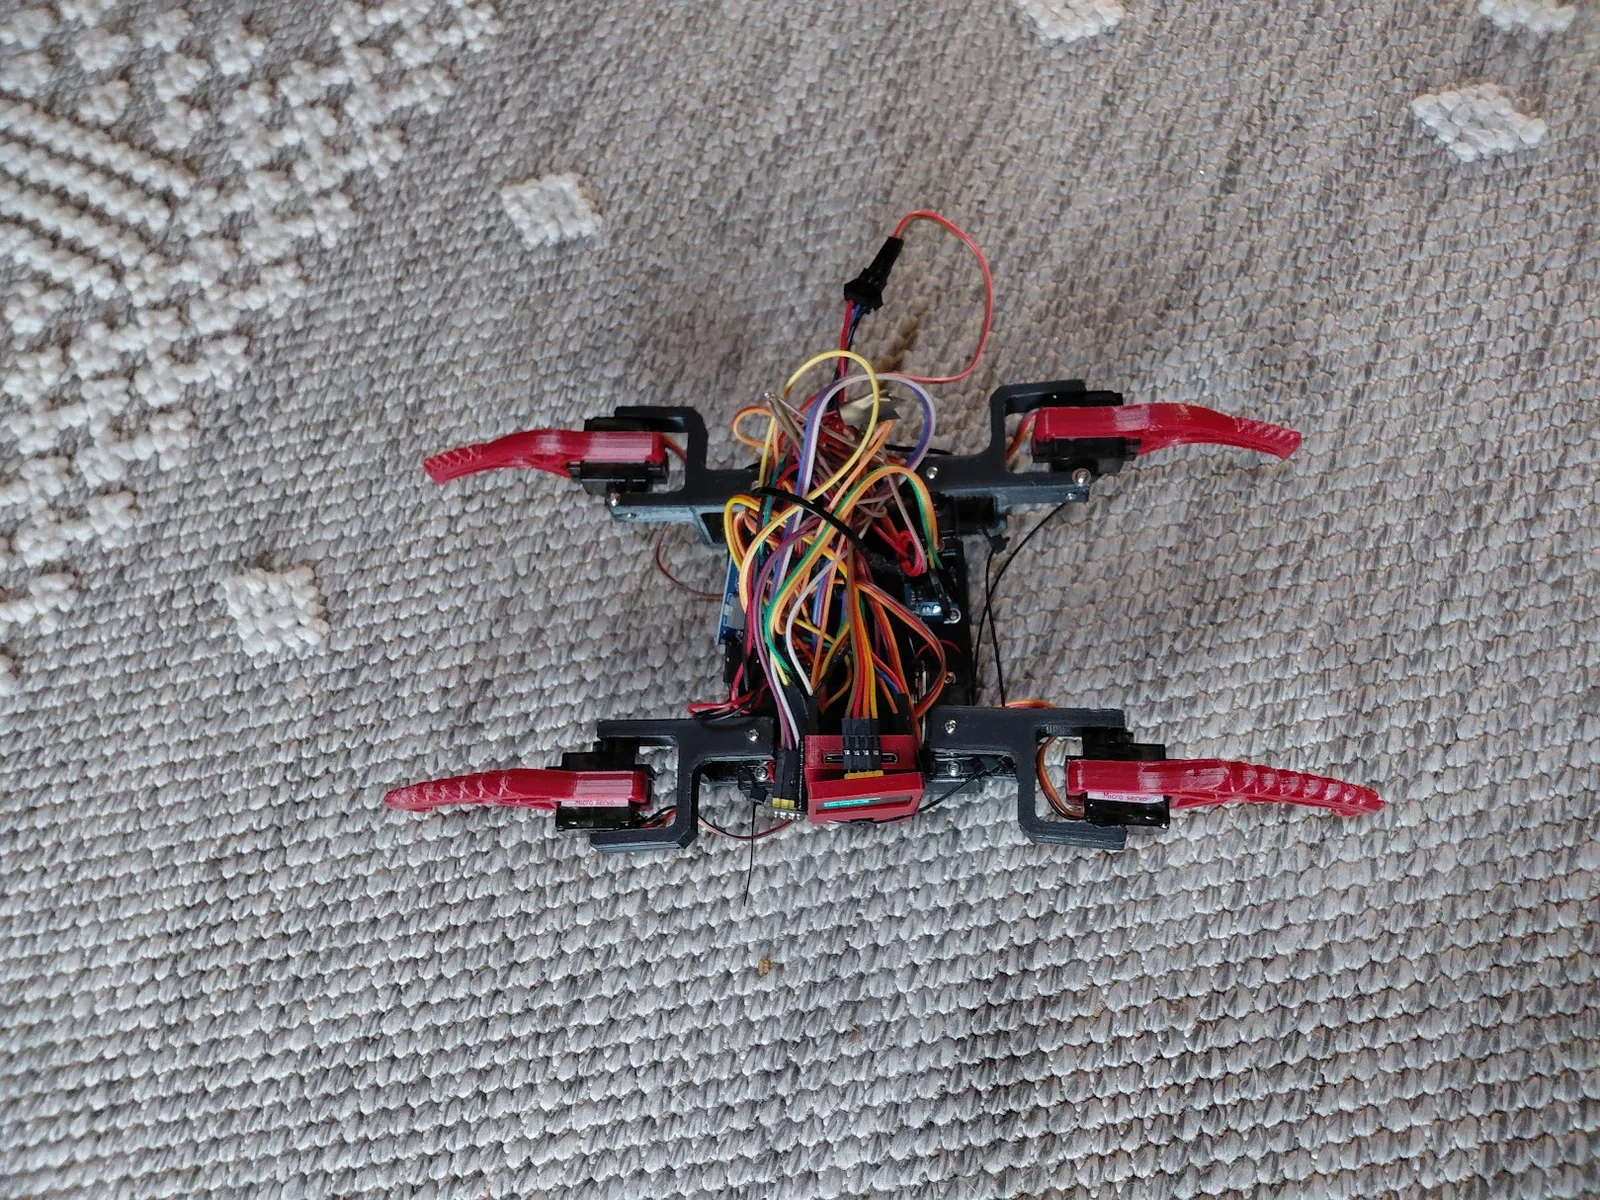
Photograph ·
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
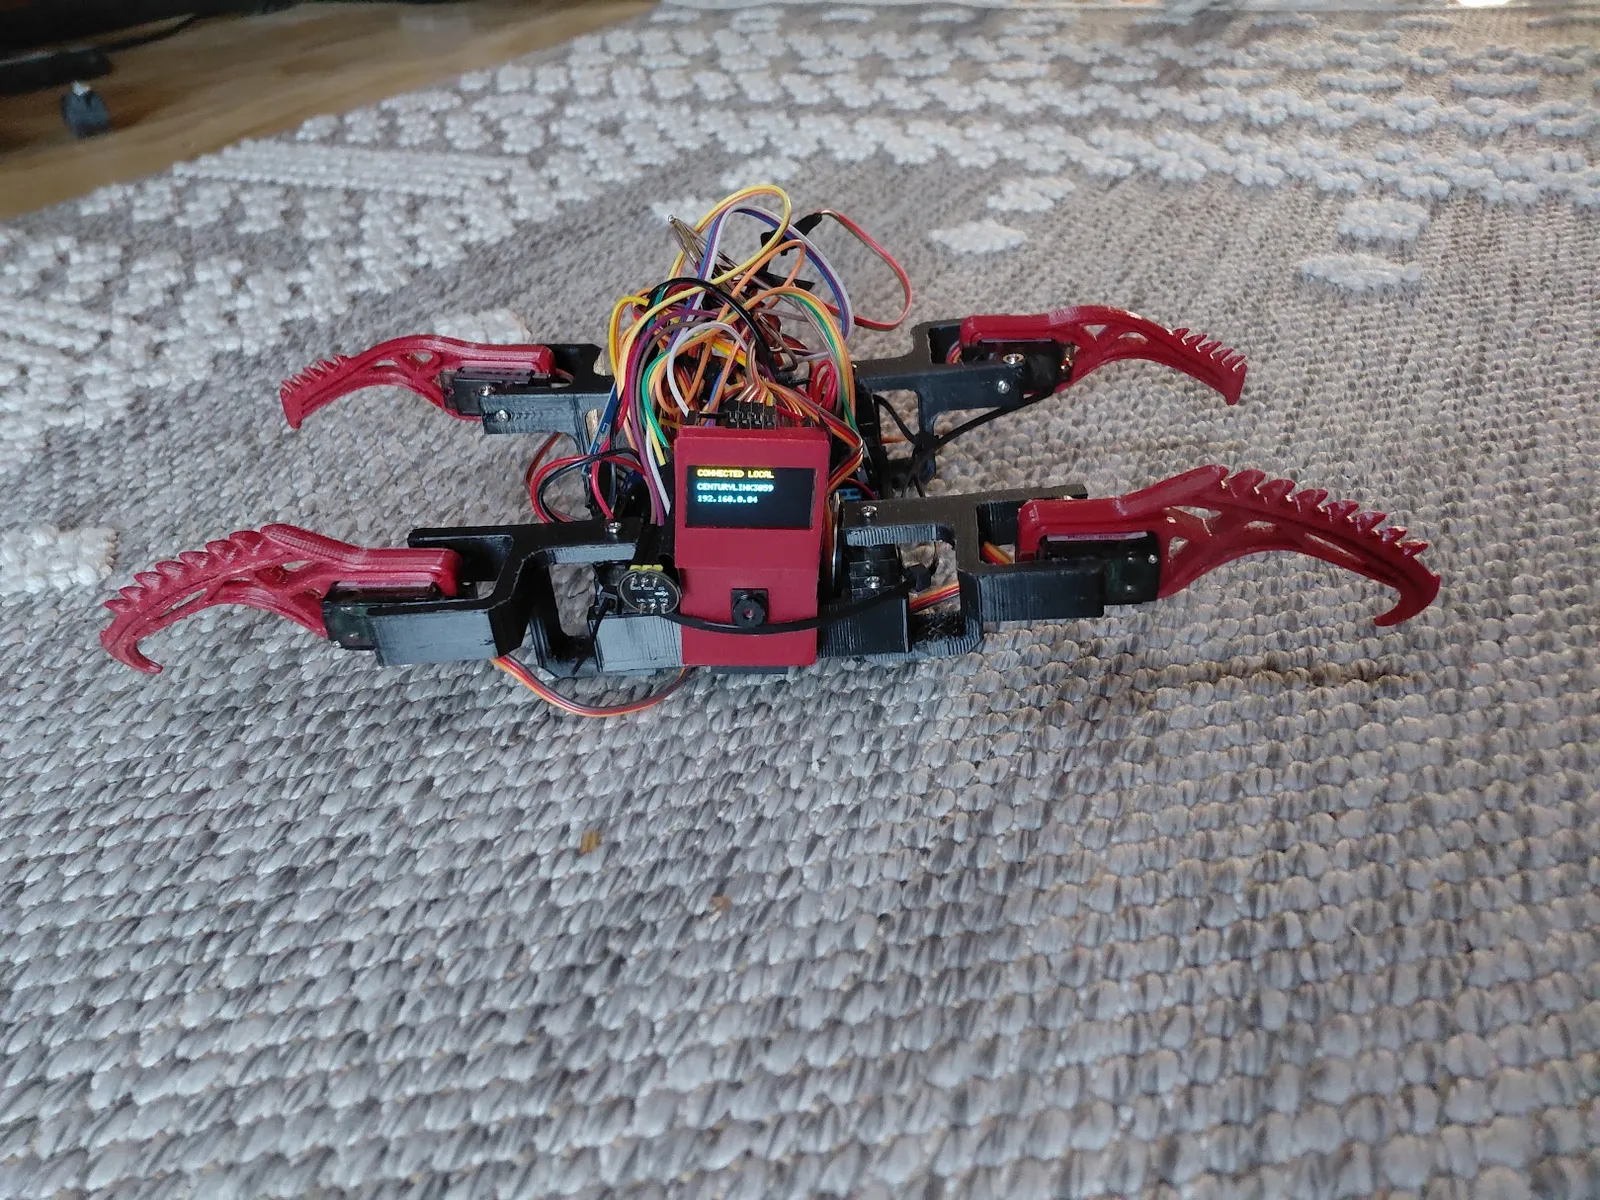
Photograph ·
Early physical prototype
The early red printed robot on the carpet, with its mechanisms and wiring visible.
The physical robot on video
Bench experiments and floor trials, including the adjustments along the way.
Physical footage · Undated
Floor test and manual adjustment
Physical footage of the prototype on carpet, including manual handling and adjustment. Recording date is not established; this is not evidence that the latest gait is qualified.
Download MP4 · 1:45 · 9.3 MBPhysical footage ·
Early electronics bench test
Physical footage of the early electronics, servos and display on the workbench.
Download MP4 · 0:23 · 3.5 MBInside the design
Earlier Blender assembly and leg studies. These show modeled geometry, not the current physical assembly.
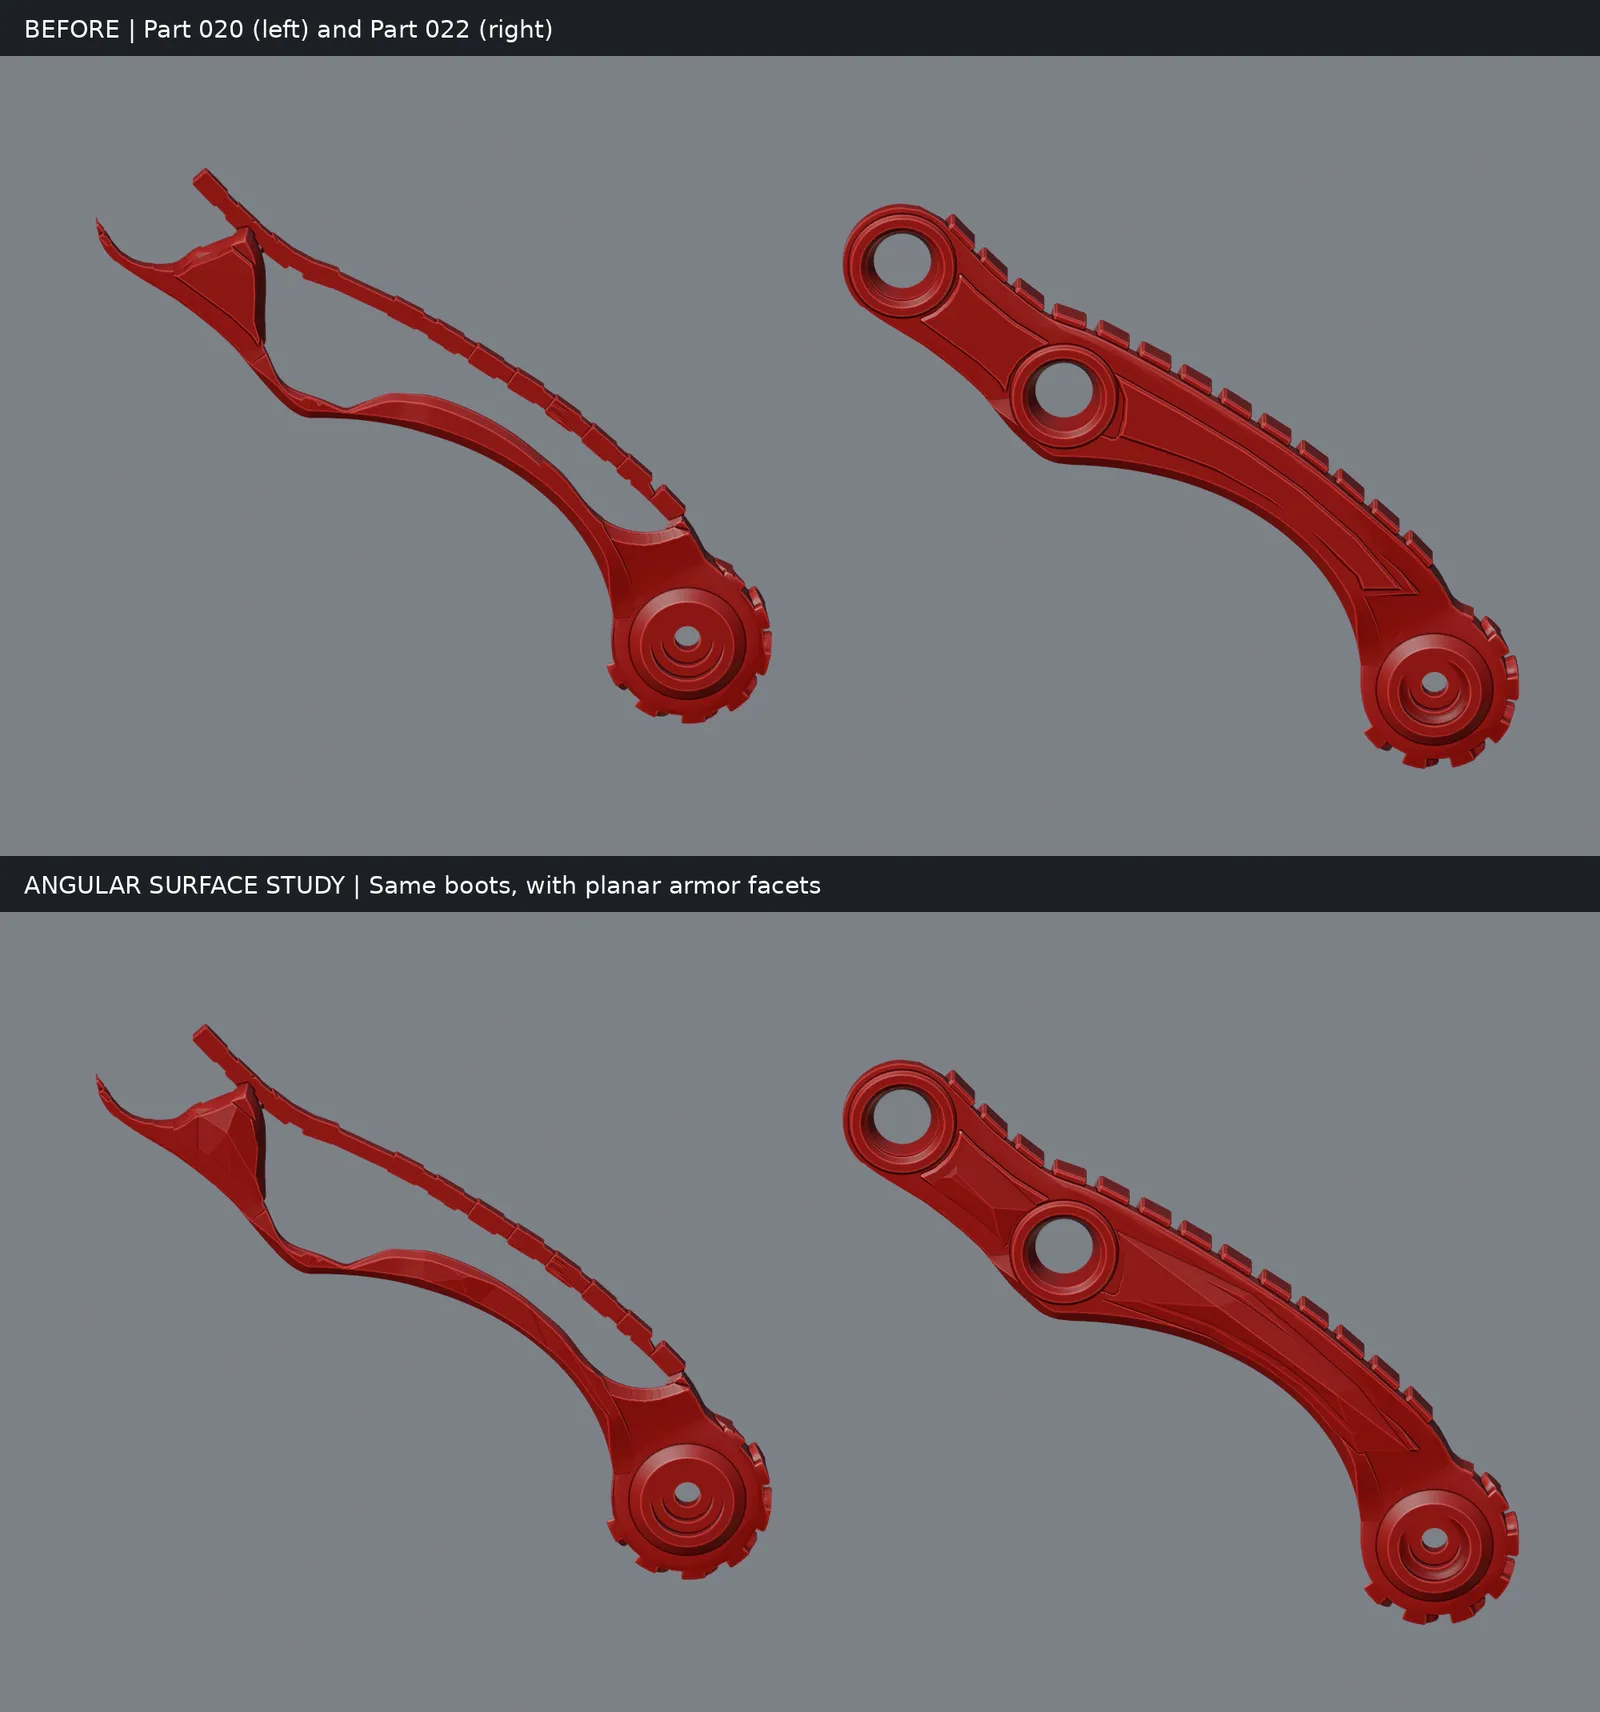
Blender study · Undated
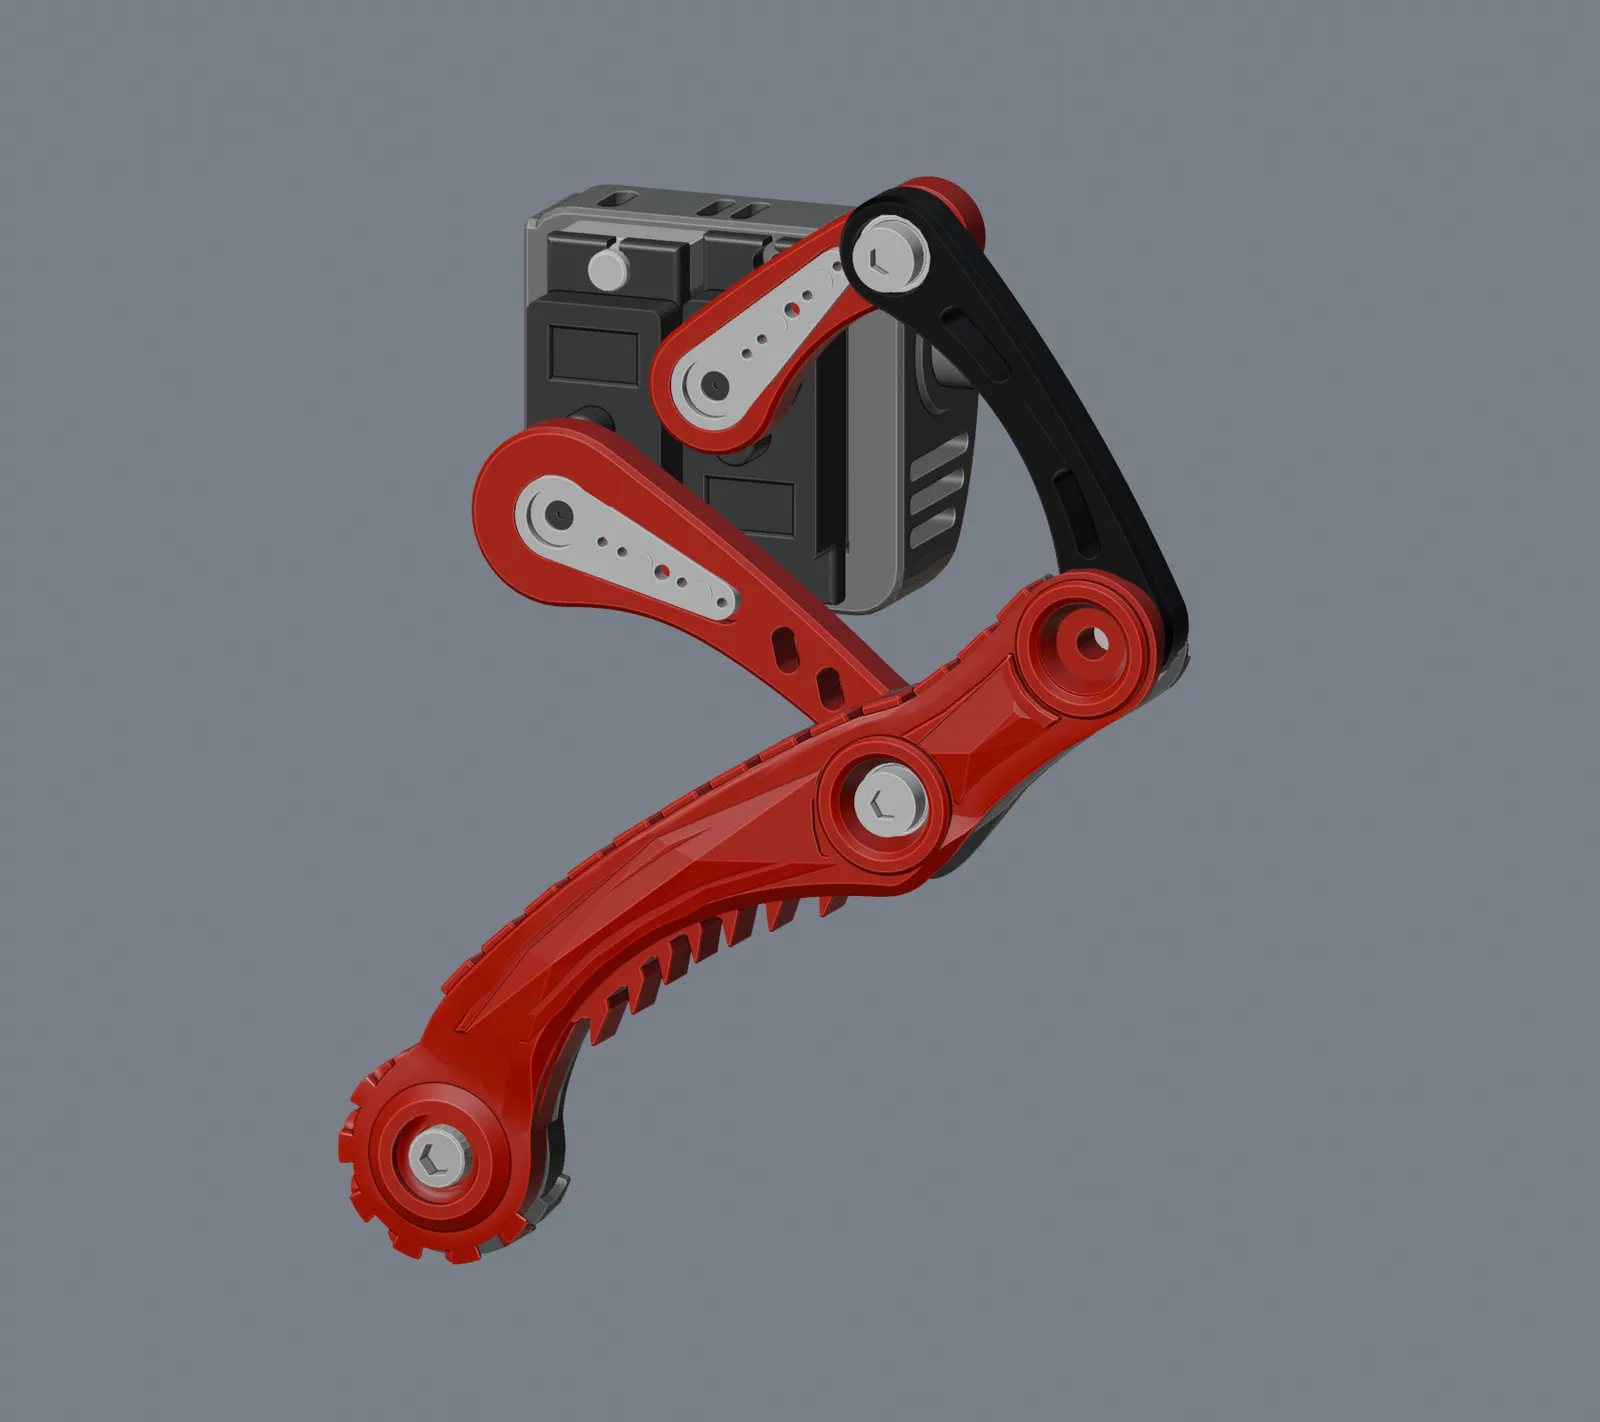
Boot angular comparison
Blender boot and leg design study; capture date is not established. This is a modeled assembly.
Blender study · Undated
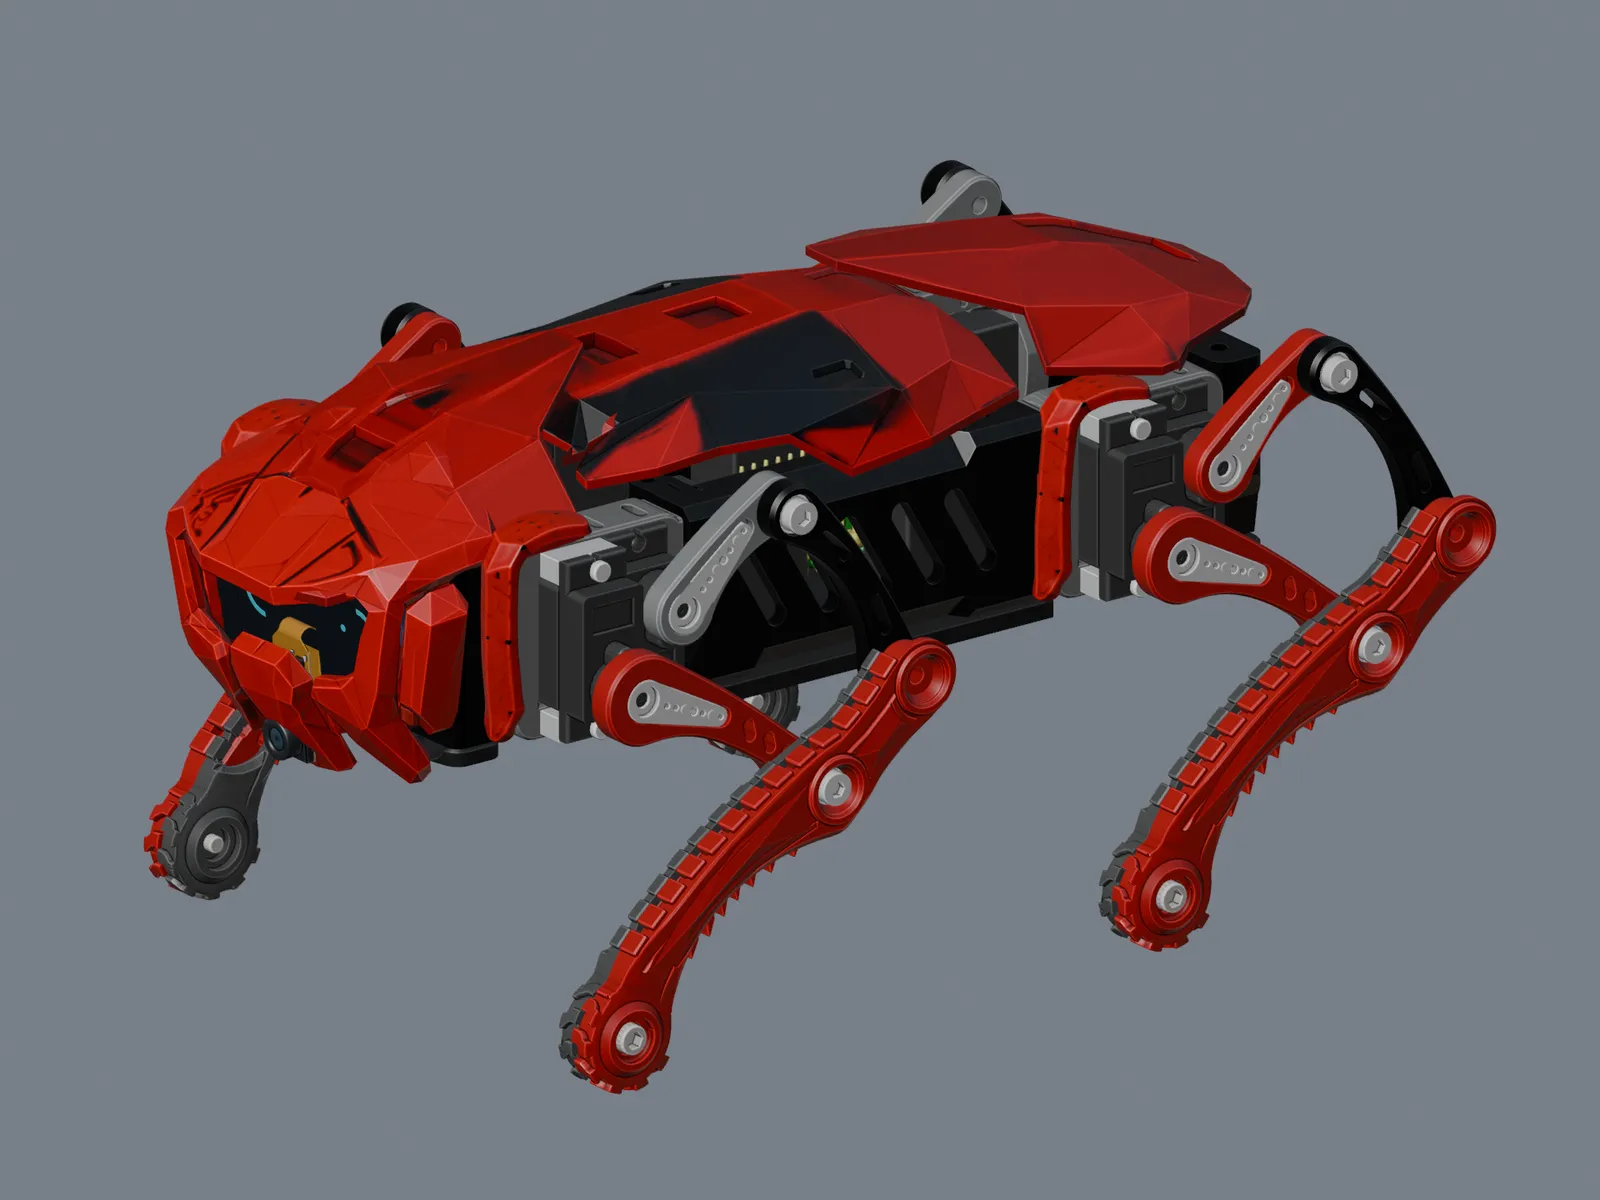
Boot angular leg
Blender boot and leg design study; capture date is not established. This is a modeled assembly.
Blender study · Undated
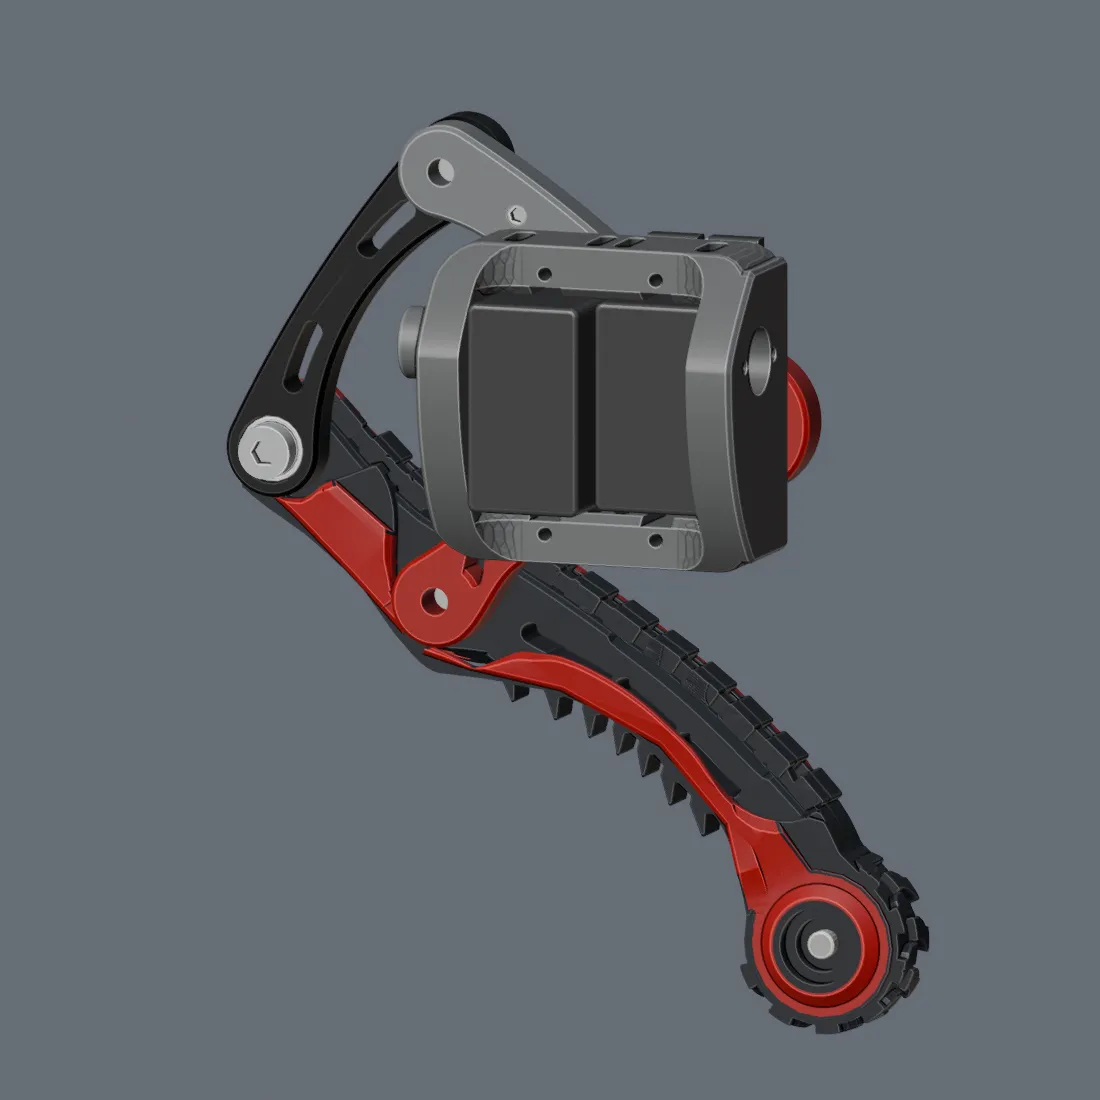
Boot angular robot
Blender boot and leg design study; capture date is not established. This is a modeled assembly.
Blender study · Undated
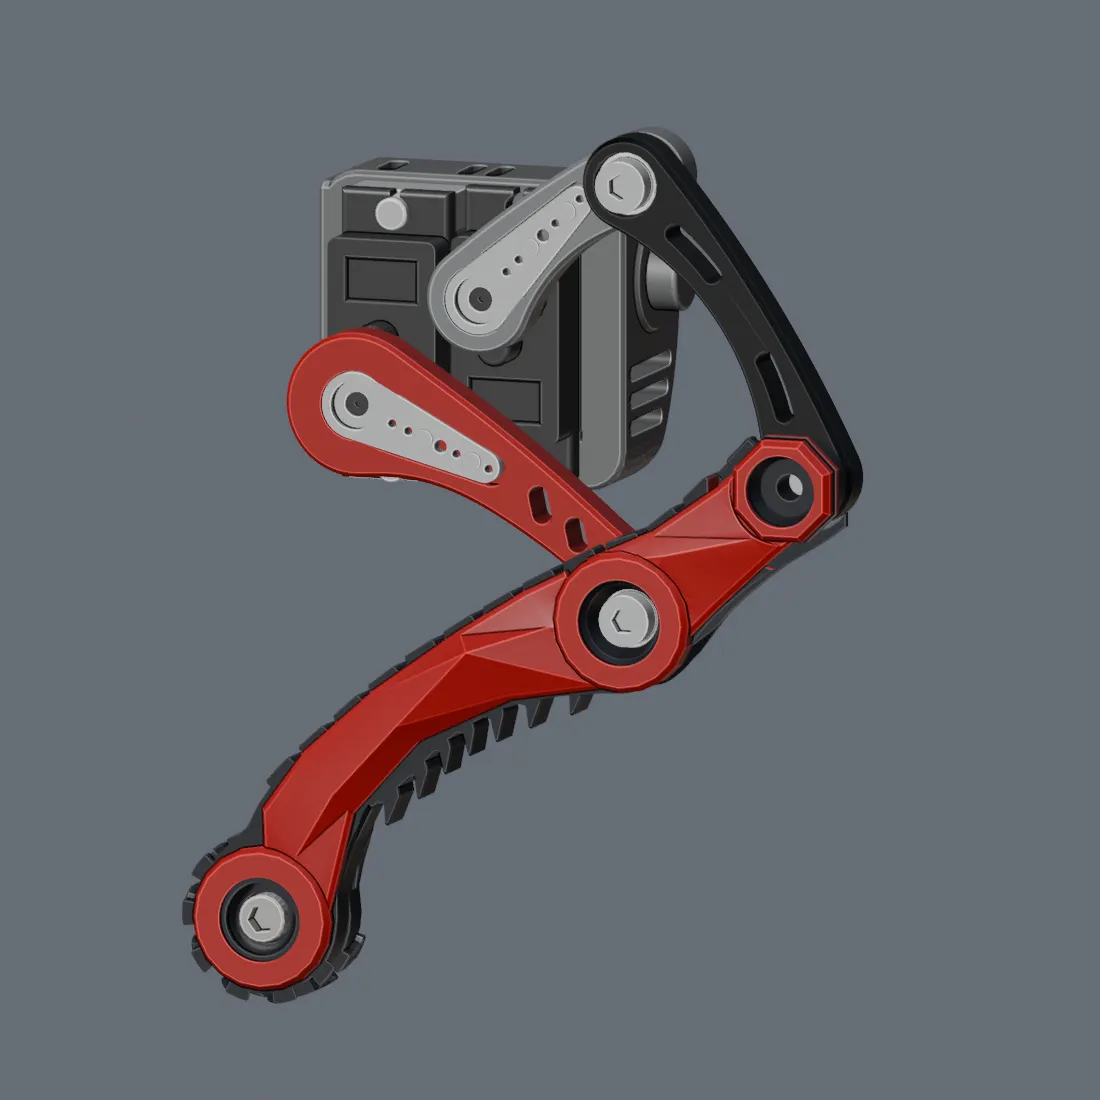
Boot replacement inner
Blender boot and leg design study; capture date is not established. This is a modeled assembly.
Blender study · Undated
Boot replacement leg
Blender boot and leg design study; capture date is not established. This is a modeled assembly.
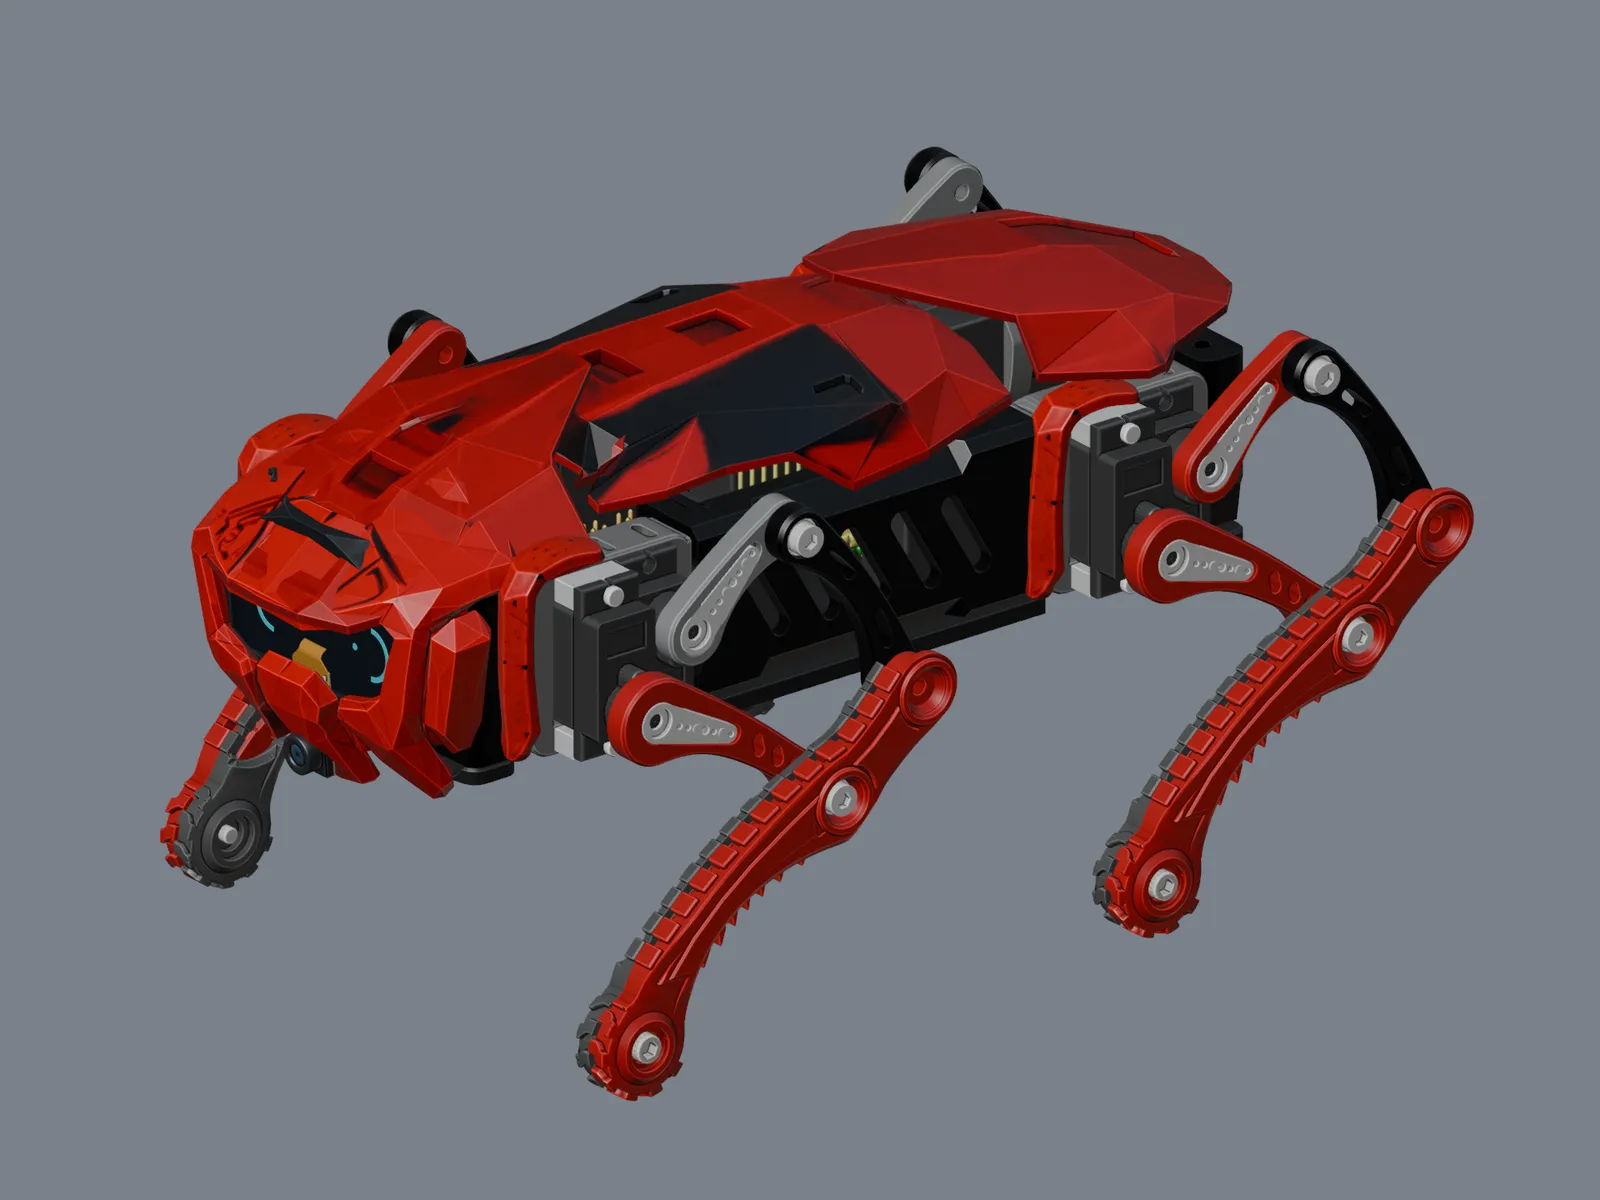
Blender study ·
Front quarter
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
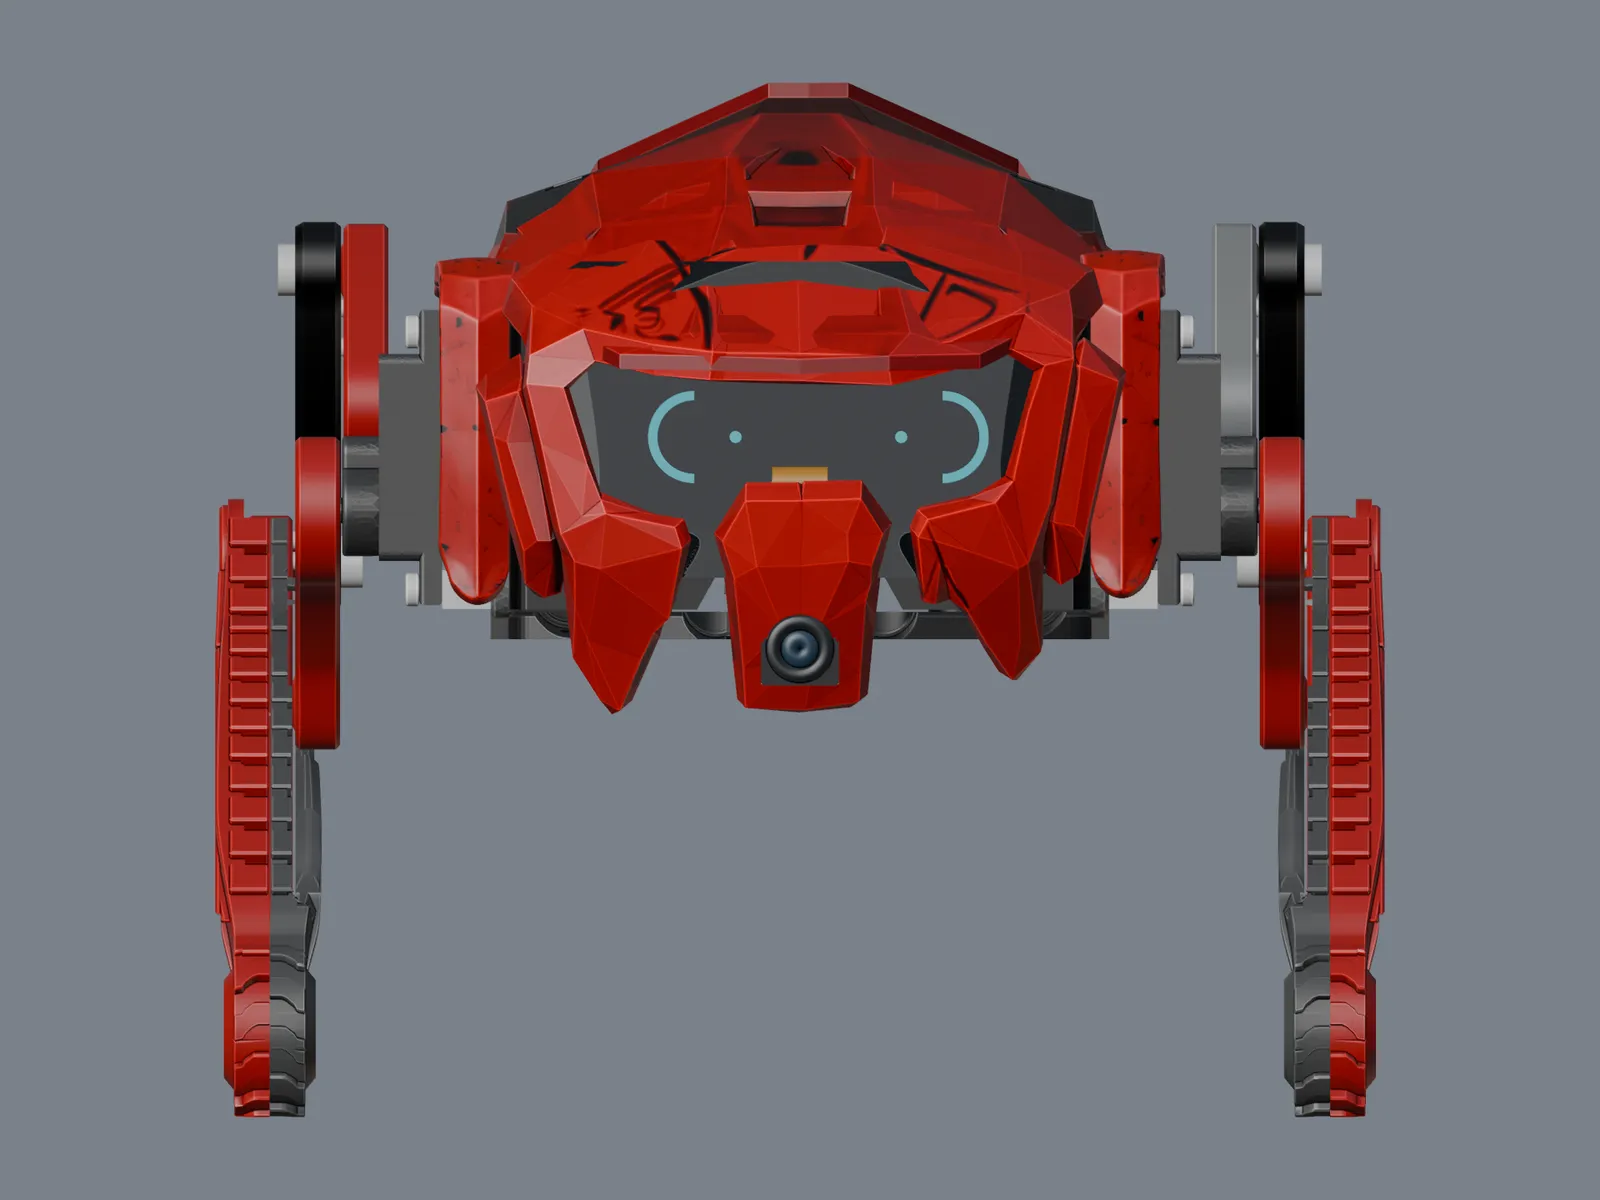
Blender study ·
Front
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
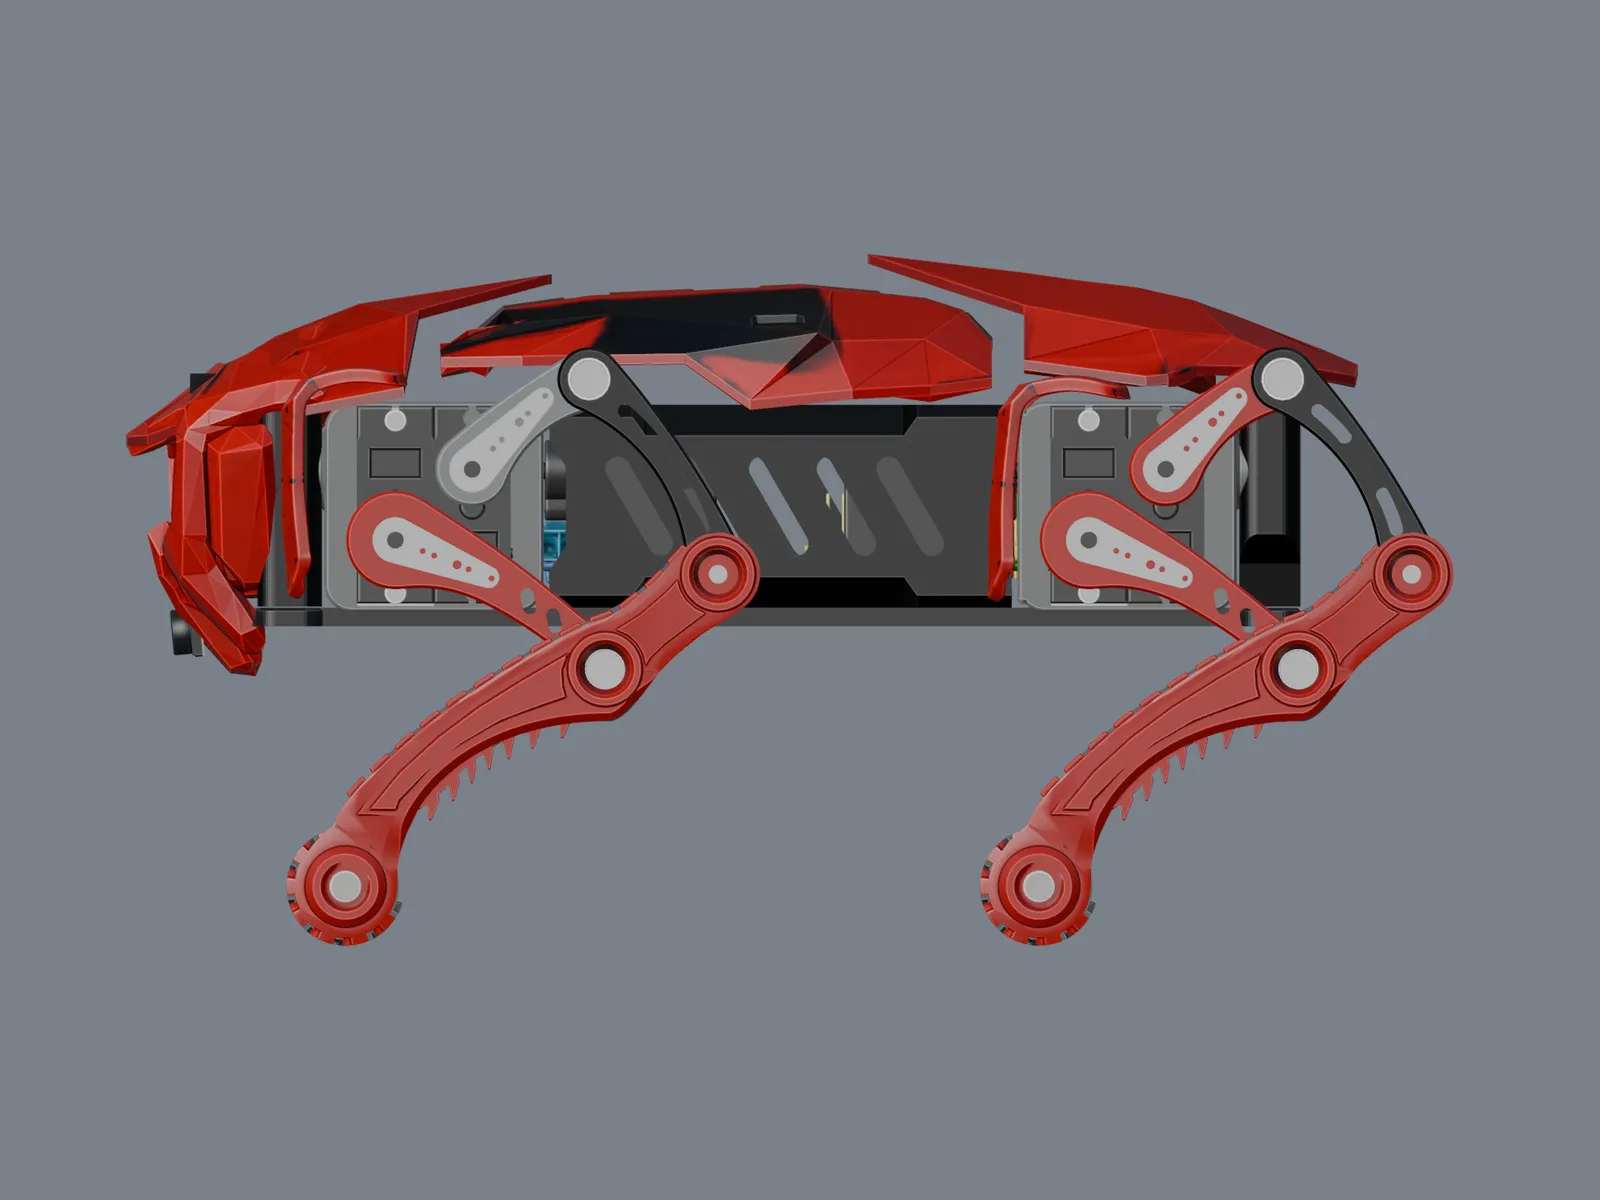
Blender study ·
Left side
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
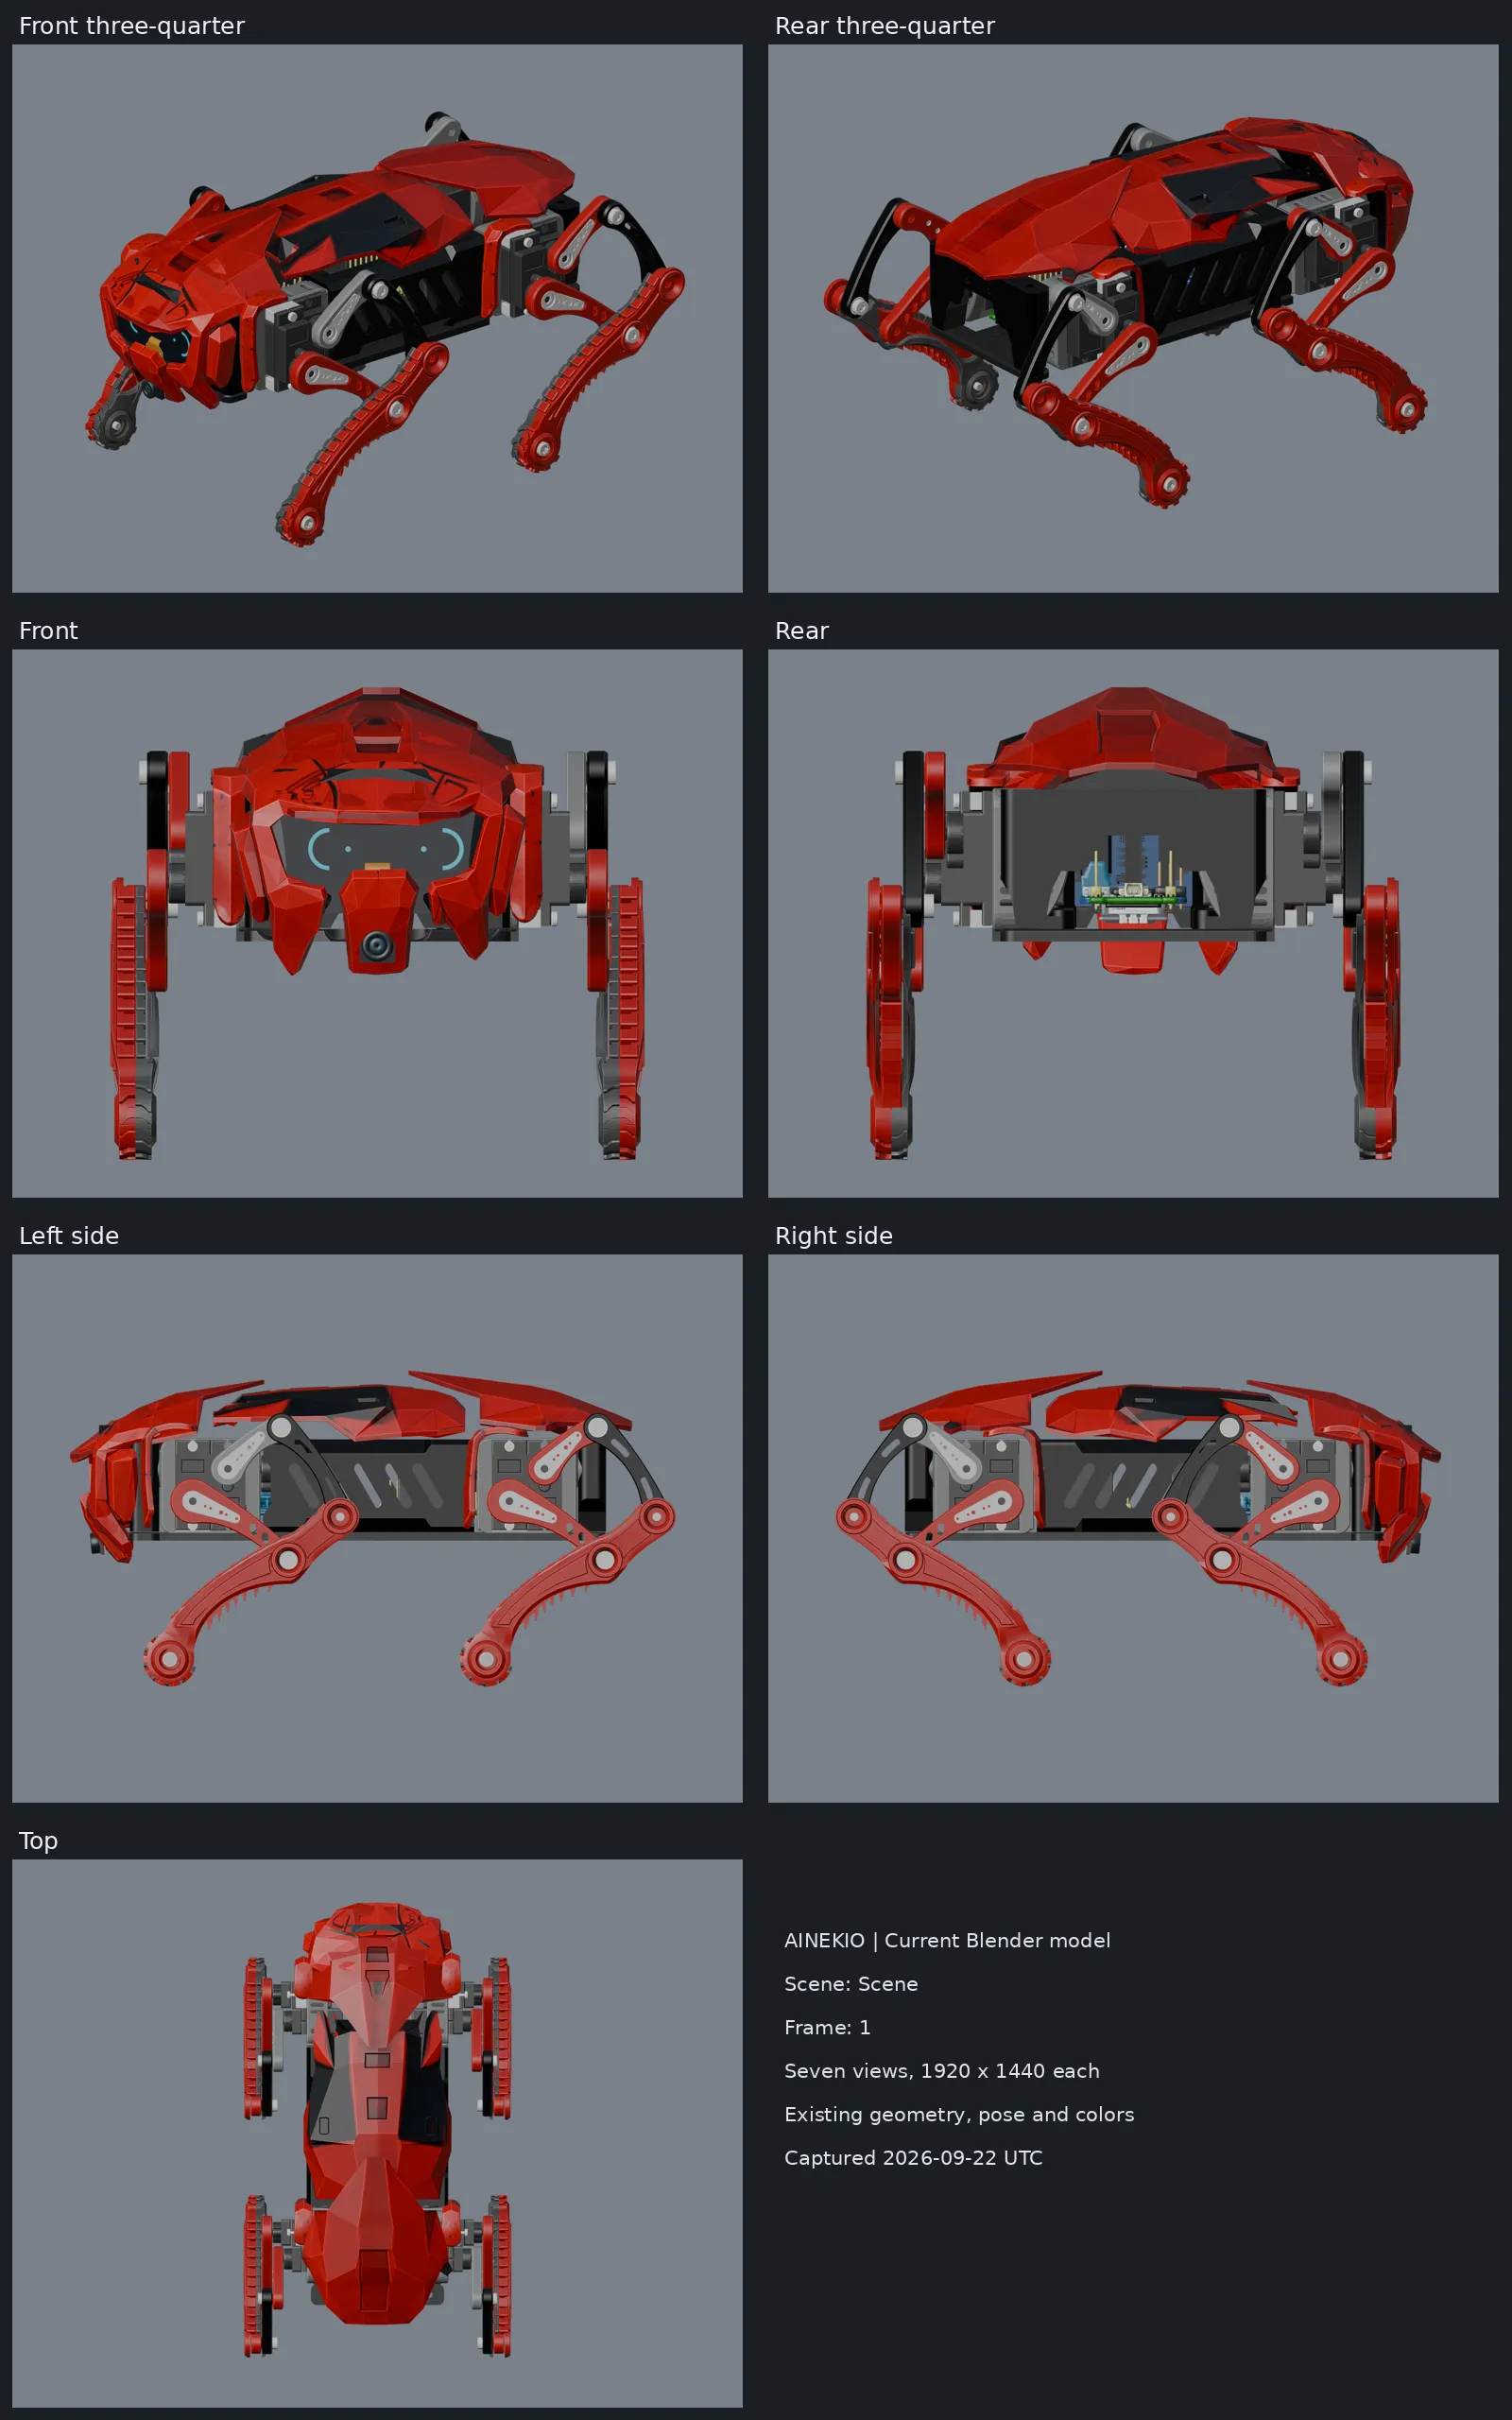
Blender study ·
Overview
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
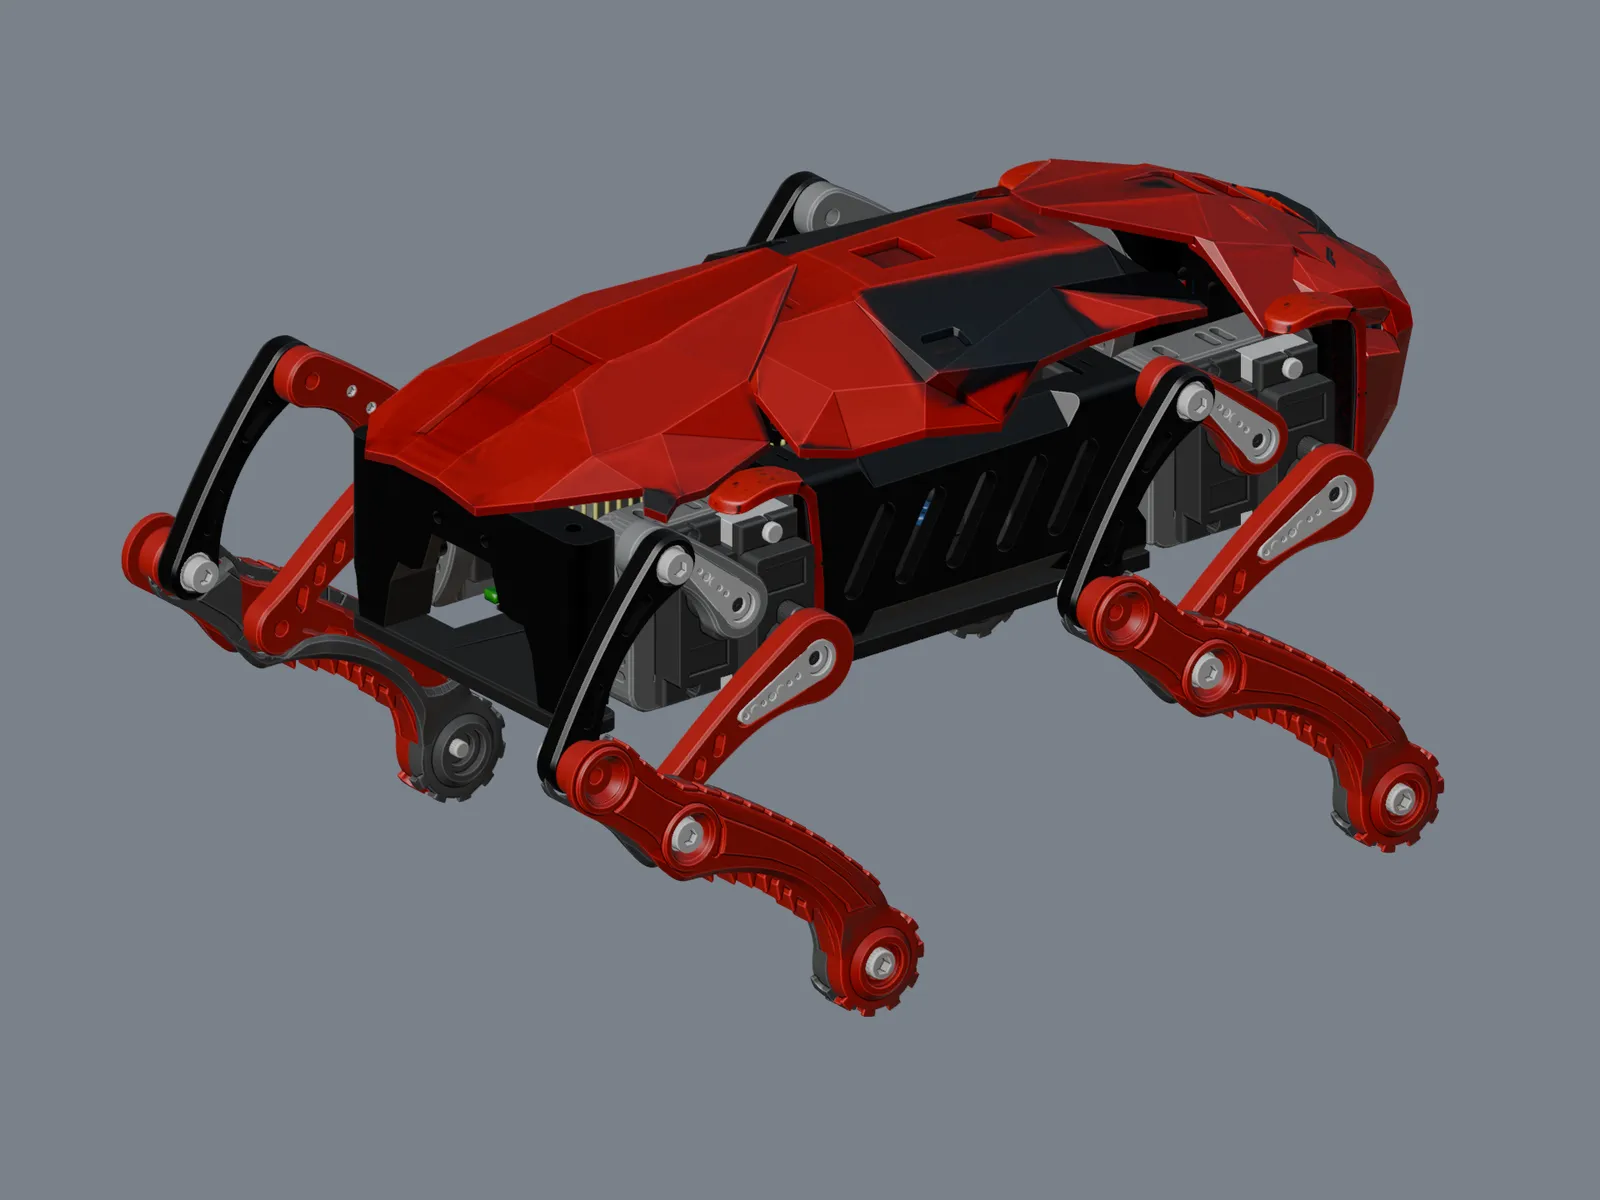
Blender study ·
Rear quarter
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
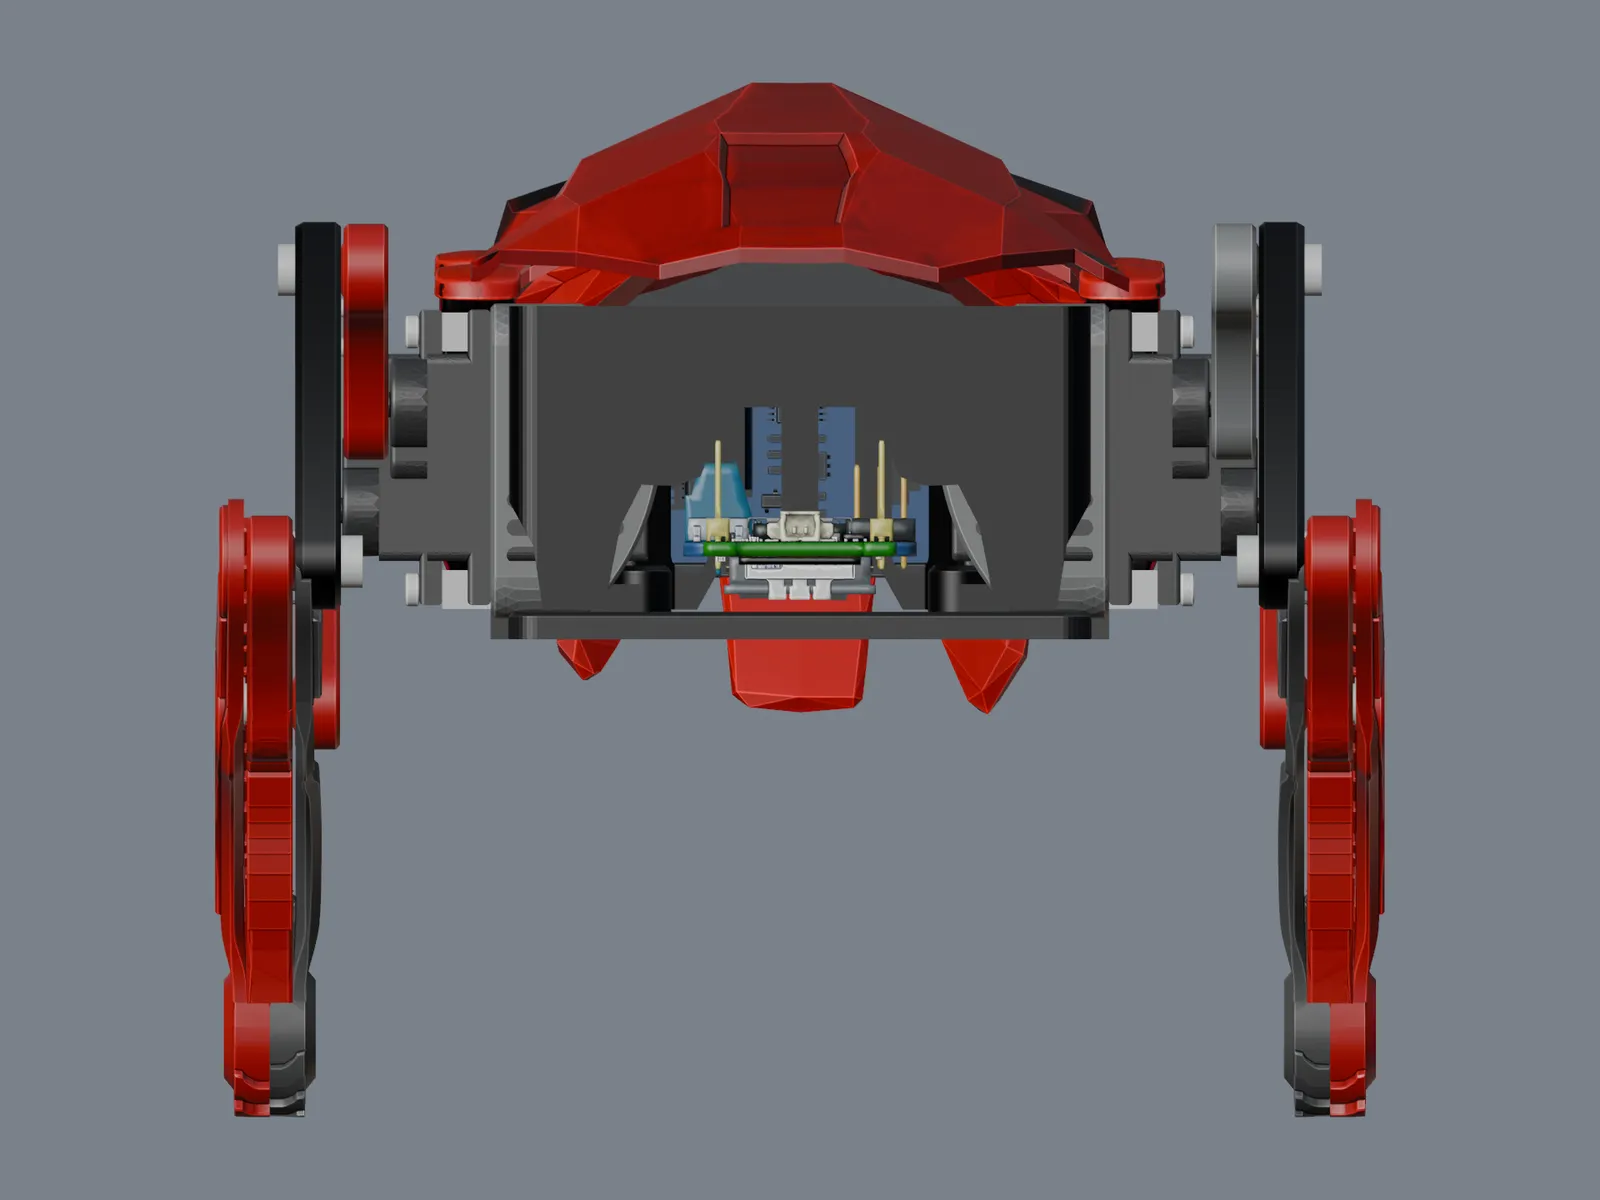
Blender study ·
Rear
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
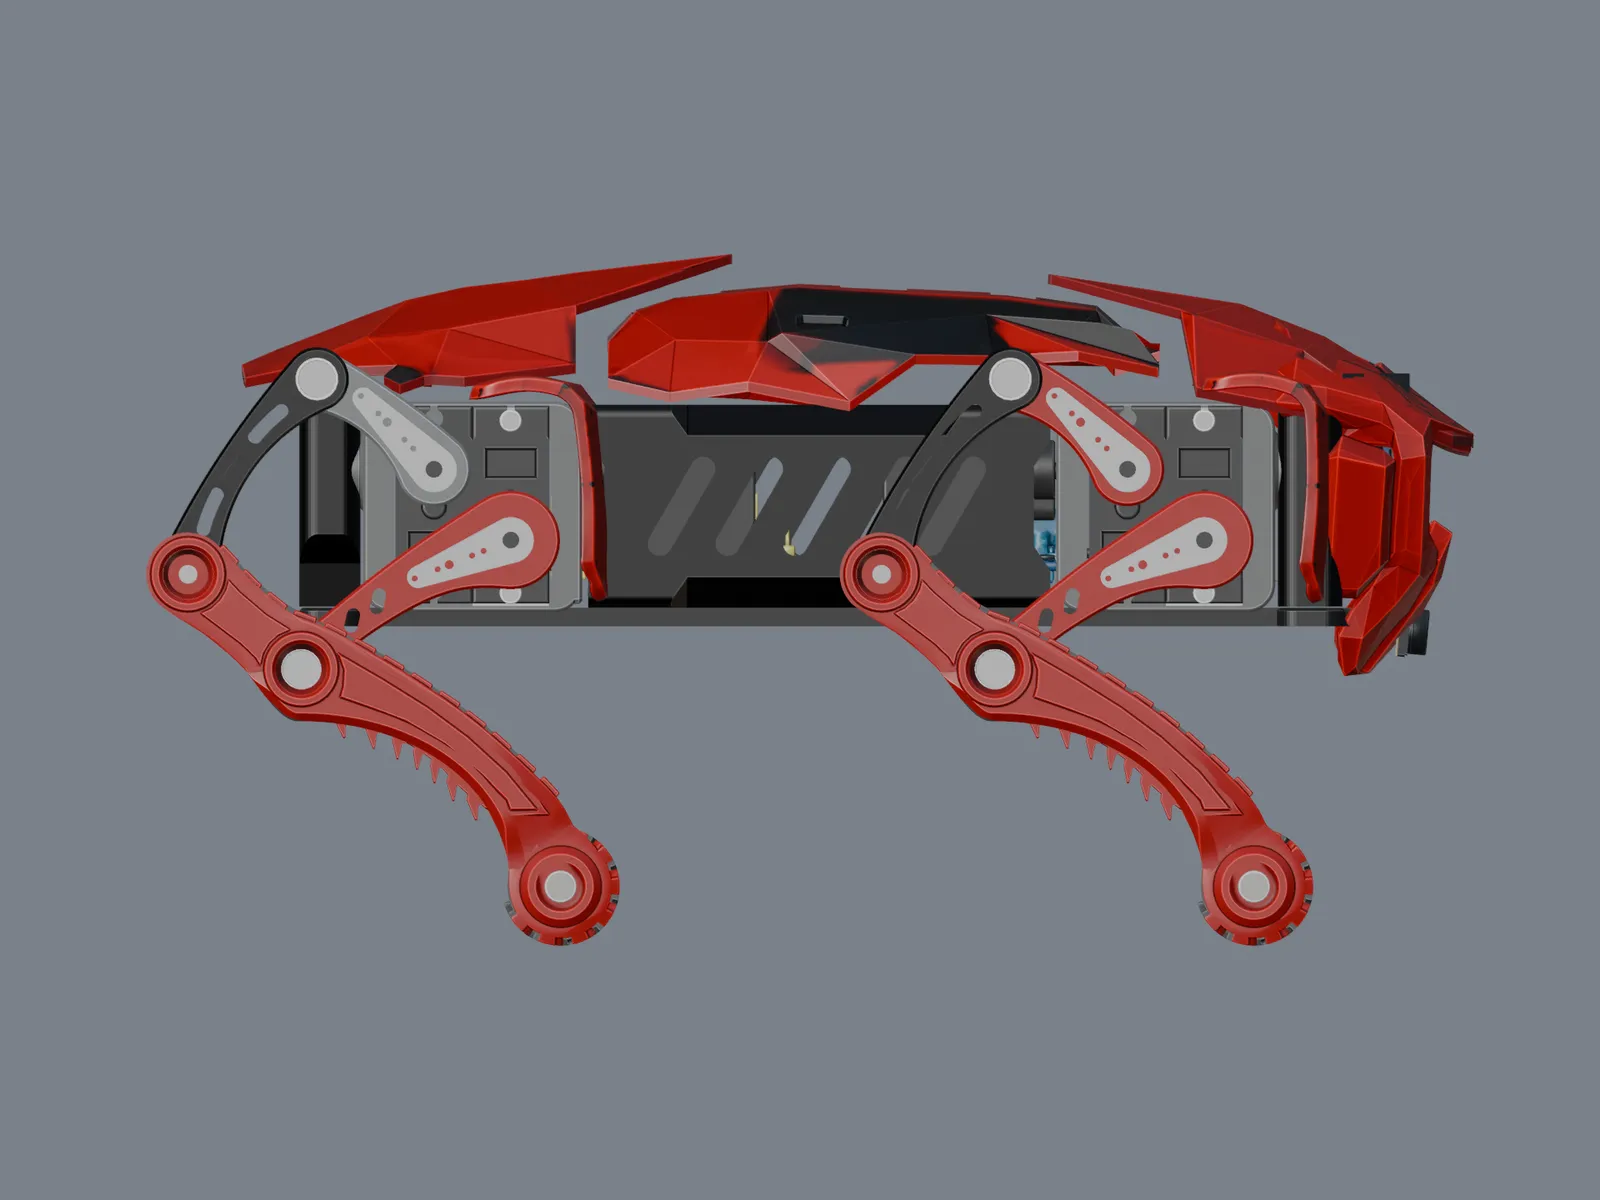
Blender study ·
Right side
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
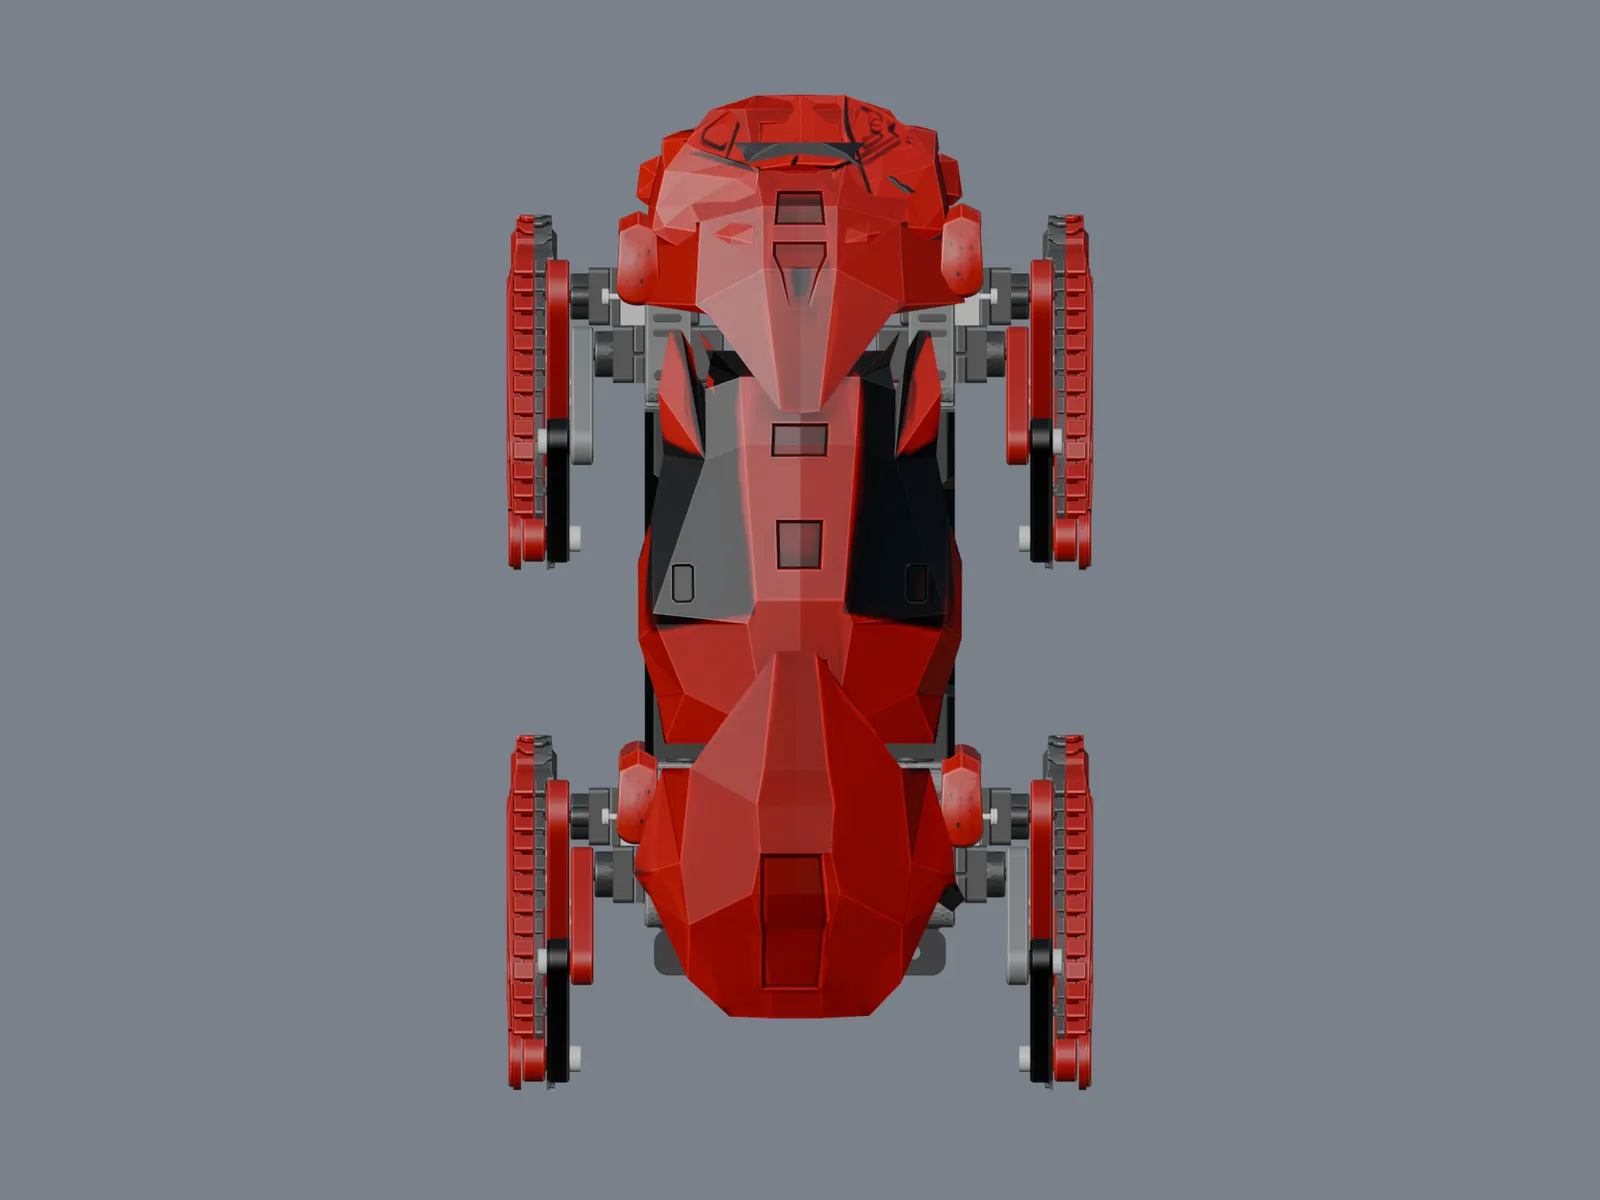
Blender study ·
Top
September 22 Blender assembly study; this predates the October feedback-servo rebuild.
Motion studies
Blender animations make the intended movements easier to see. Physical walking remains under development.
Blender animation ·
33 motions in Blender
A four-minute Blender motion showcase at 2× playback. The labeled chapters show modeled poses and gaits from the earlier library, not physical robot performance.
Download MP4 · 4:10 · 15.9 MBBlender animation · Undated
Variable gait study
A short Blender animation of the red robot and its changing leg motion. Recording date is not established.
Download MP4 · 0:07 · 0.7 MB