V2 · 12 servosDated experiment
Shorter Carriers, the Same Repertoire: Reworking 23 Motions
The 35 mm carrier candidate has a complete offline motion library, with explicit changes to foot placement, reduced Upright reach and unresolved servo travel.
Published 5 min read
October 8: The lighter robot stands, walks, and responds to commands.
A stronger lifting arrangement without losing the character
The printed chassis could not stand on the MG90 servos. Alongside removing weight and changing the battery plan, I have been revising the legs in Blender. The aim is more lifting capability and quicker movement from the servos I am keeping. The replacement parts are still printing; the revised robot has not passed a physical standing test.
The October 5–6 work now includes a complete offline candidate for all 23 named motions. That matters because the robot needs to keep its gestures as well as its walking motion. The new linkage changes what those poses require.
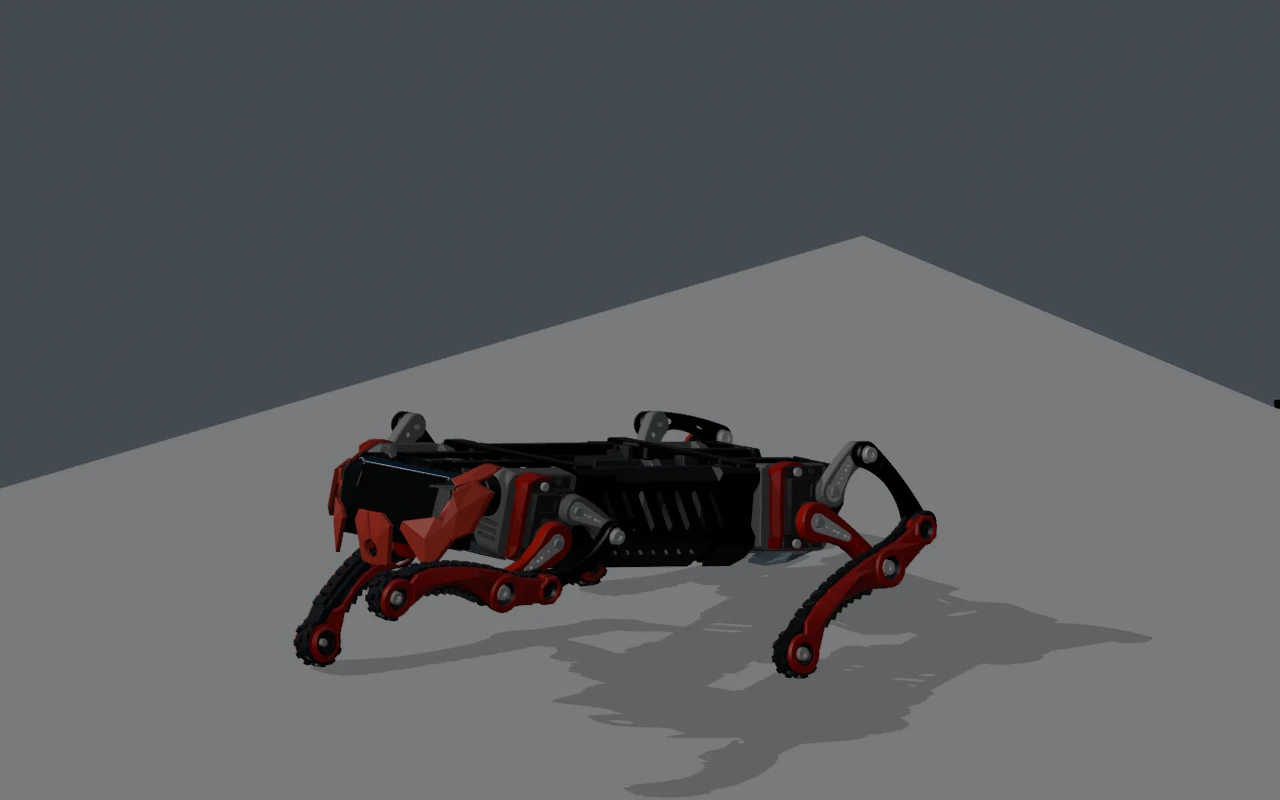
Geometry, side by side
These dimensions compare the shared software model at commit 13fc3e4 with
the new experimental model. They are model dimensions, not a measurement of
every link currently installed on the printed robot.
| Dimension | Shared model | October 5–6 candidate | Change |
|---|---|---|---|
| Carrier | 40 mm | 35 mm | −5 mm |
| Crank | 24 mm | 20 mm | −4 mm |
| Pickup radius | 24 mm | 28 mm | +4 mm |
| Connecting rod | 38 mm | 38 mm | Unchanged |
| Distal leg | 55 mm | 55 mm | Unchanged |
The candidate is identified as compact-35-20-28-38-55-visible-20261005.
It lives in a separate development package and Blender scene. The handoff
explicitly records that the active shared model was not replaced and this
candidate was not installed in firmware.
My estimate of approximately 20% more lifting force is a design estimate, not a measured result from these motion checks. The carrier reduction itself is 12.5%; it should not be relabeled as a measured 20% change in either travel or force. The whole linkage and its changing poses still need to be tested.
Preserving the motions, recording the compromises
Thirteen clips preserve their original body trajectory, foot positions in the horizontal plane and full-sole height: Celebrate, Curious, Cute, Dance, Freaky, Lay Down, Sad, Shake, Shrug, Stretch, Surprised, Swim and Worm. Crouch uses the native inverse-kinematics planner with the same targets, including its −35 mm terminal body translation.
Other movements needed explicit changes:
| Motion | Retained behavior | Change in the compact candidate |
|---|---|---|
| Sit | Body trajectory, timing, contact sequence and supporting-sole orientation | Rear landings move about 5.584 mm forward |
| Wave | Seated three-wave sequence and return to standing | Uses the revised Sit |
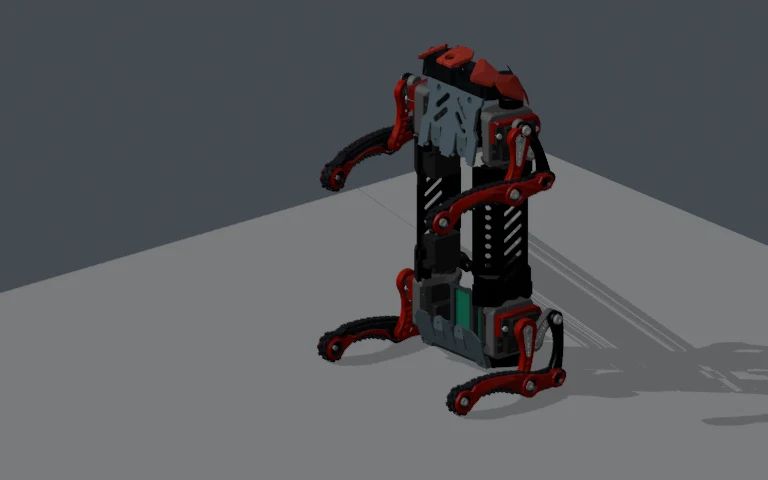
| Upright | Sit entry, two front steps and full −90° body rise | Refitted body path; selected forelimb reach falls from 90.339 to 76.585 mm |
| Rest | Step timing, final boot orientations and chassis lowering | Landings move about 5.018 mm forward |
| Bow / Nod | Foot paths and original timing | Body translation adjusted by as much as 5 mm |
| Pushup | Five repetitions and timing | Body translation refitted by up to 4.767 mm |
| Play Dead | Remaining sequence and timing | Front slide endpoint moves about 7.158 mm rearward |
| Point | Original carrier angle, boot orientation and extension timing | Pointing boot displaced by 5 mm because the carrier is shorter |
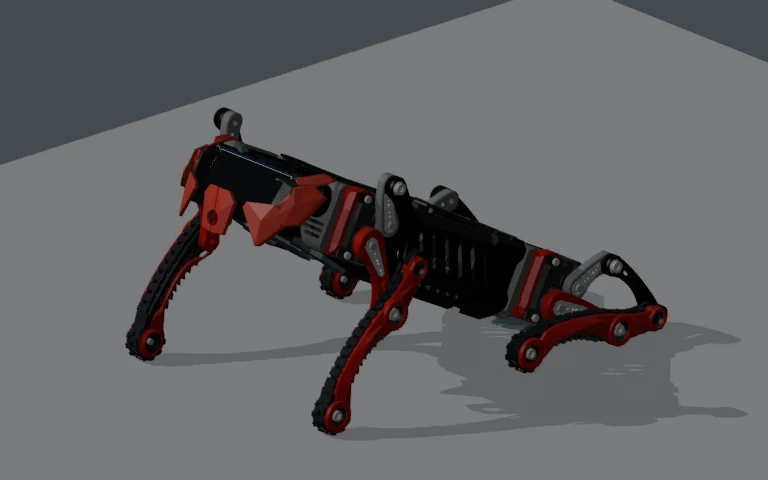
Upright is being kept as an experimental, best-effort motion. Its 76.585 mm reach describes this selected fit, not the maximum reach of the mechanism in every direction. The original extension would require a different linkage branch, and the retained fit reaches an input dead center. On October 6 I chose to continue with the rest of the library while keeping these limitations visible.
What the checks establish
The final library contains 31,031 source/preview samples. The recorded native sampler checks cover all twelve joints at 62,517 timestamps. Forty-six nonsequential Blender poses agree with the native forward-kinematics calculation to within approximately 0.000027 mm. The saved scene was reopened and checked.
Those results establish agreement between the motion data, software calculation and Blender scene. They do not establish that MG90 servos can carry the load, that the body avoids every collision, or that the robot balances.
The native test record is six passes out of seven. v2_upright still fails
its historical requirement for more than 90 mm forelimb reach. That assertion
has been retained as comparison evidence; the reduced-reach experiment is not
being described as a clean test pass.
There is also a servo-travel problem to resolve. Across Upright and Bow, the front cranks require approximately 243.868° of combined travel. The provisional mapping covers 225° over its 400–2,900 μs reference interval. Simply shifting the center cannot fit that span. Actual usable shaft travel has not been measured; these reference values are not installation instructions.
Continuous gait work remains connected to this study
The earlier continuous-motion candidate checked 70 planner cases, retaining the intended foot targets, phase/contact schedule and shared motion clock. The October 6 library then completed the named gestures that were still missing from that earlier handoff.
Separately, the committed controller now uses a 96 mm full Walk sweep, 8.85 mm Walk lift and a −8 mm body offset. Continuous Crawl uses a −22 mm body offset, an 18 mm sweep and 4 mm lift. Crawl and the named Crouch gesture are different motions; their offsets should not be interchanged. A shared joint speed limit can stretch automatic motion timing while preserving the planned path. Requested cadence is therefore not proof of achievable loaded speed.
The next evidence needed is the revised printed assembly: actual mass, usable servo travel, standing ability and movement under load. That will determine which of these modeled gains survive the physical build.
Record behind this entry
The committed model and controller notes
provide the baseline. The local October 5–6 records are
docs/gait-research/linkage-motion-parity-20261005/handoff.json and
docs/gait-research/seated-support-20261005/, particularly its README,
library-handoff.json, library-native-check.txt and library-travel.json.
These experimental files were local development artifacts at review time.
The review manifest records their hashes and image origins. The dimension comparison CSV contains the five dimensions above. This entry continues the gait development journal.
Shorter Carriers, the Same Repertoire: Reworking 23 Motions
https://ainek.io/posts/2026-10-06-compact-linkage/