V2 · 12 servosDated experiment
Shell Printing, Weight Changes, and a 4 A Supply
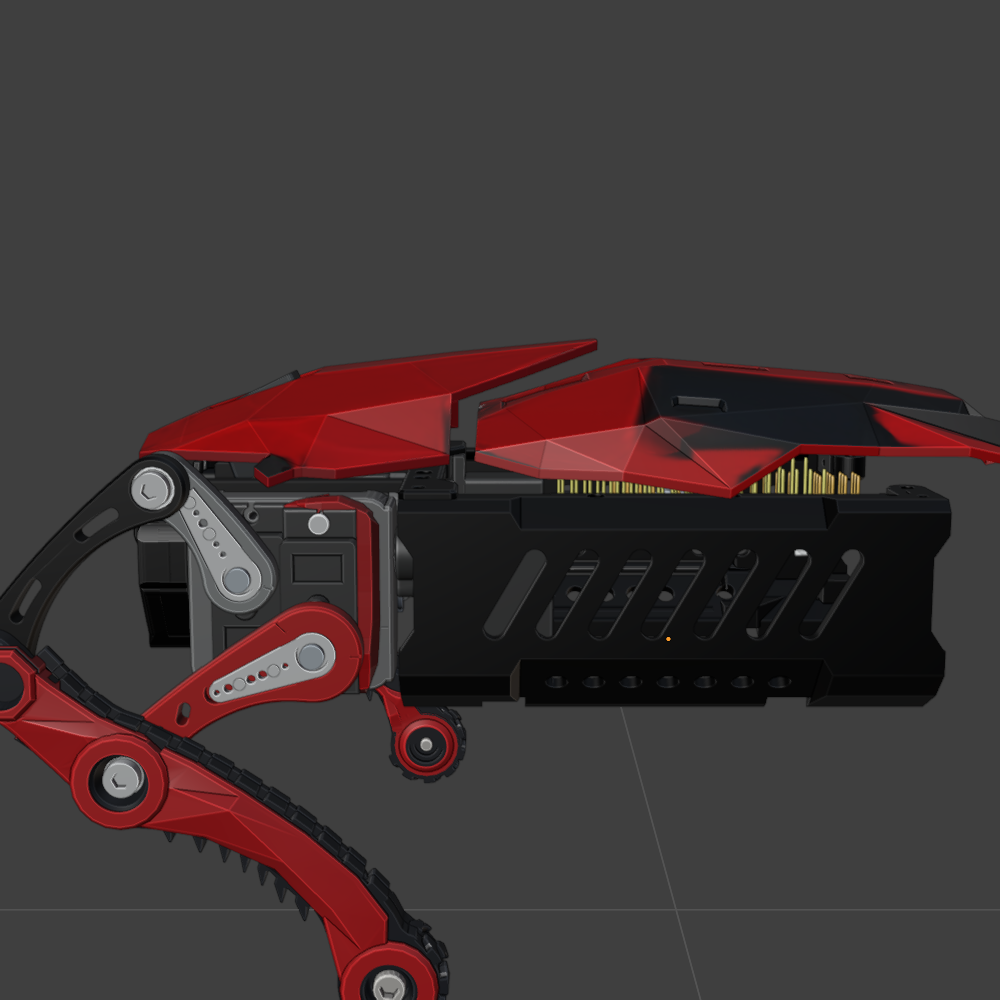
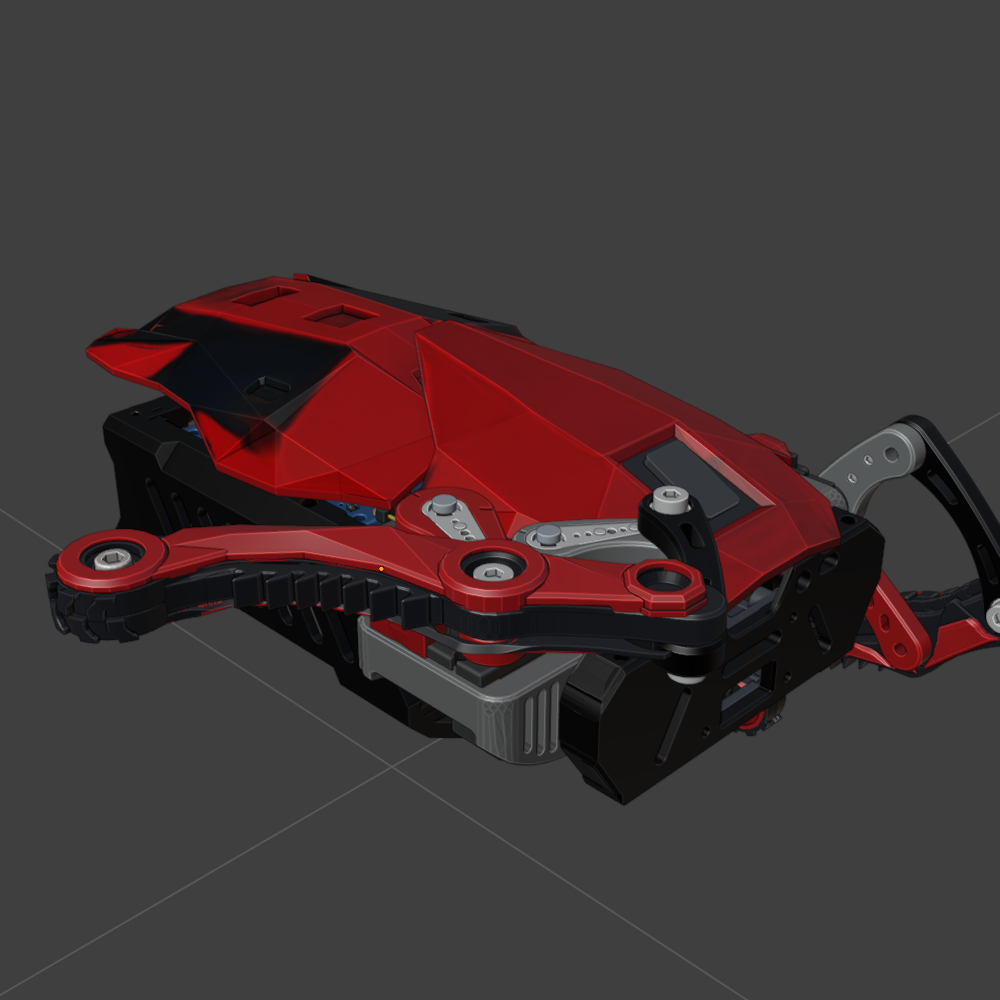
Exterior printing has begun. Follow the Blender shell and camera-mount exports, the new power-supply direction, and revised foot placement for Lay Down and Play Dead.
Published 3 min read
Printing the exterior
I have begun printing the exterior shell, made further weight modifications, and switched to a 4 A power supply. Alongside the physical build, I have started integrating YOLOE and done extensive work on MetaHuman’s node workflows and trained Qwen 0.8B intent and task models.
The robot could stand, walk and respond to commands on October 8, without the carapace. Shell fit is next; Active Operator remains untested.
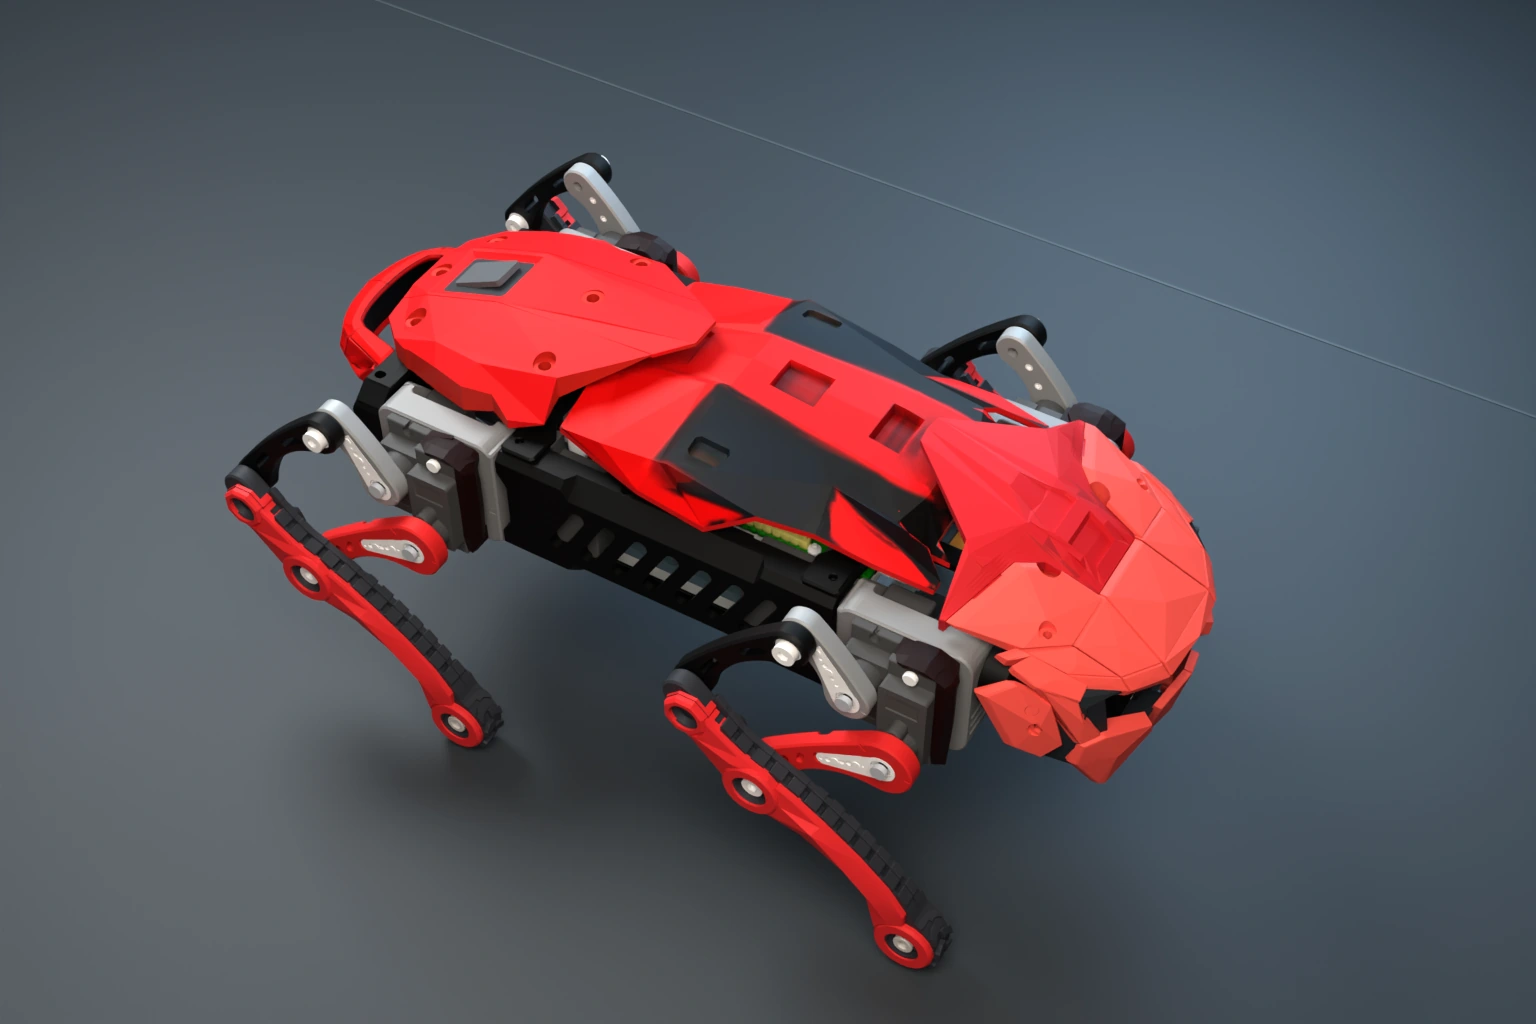
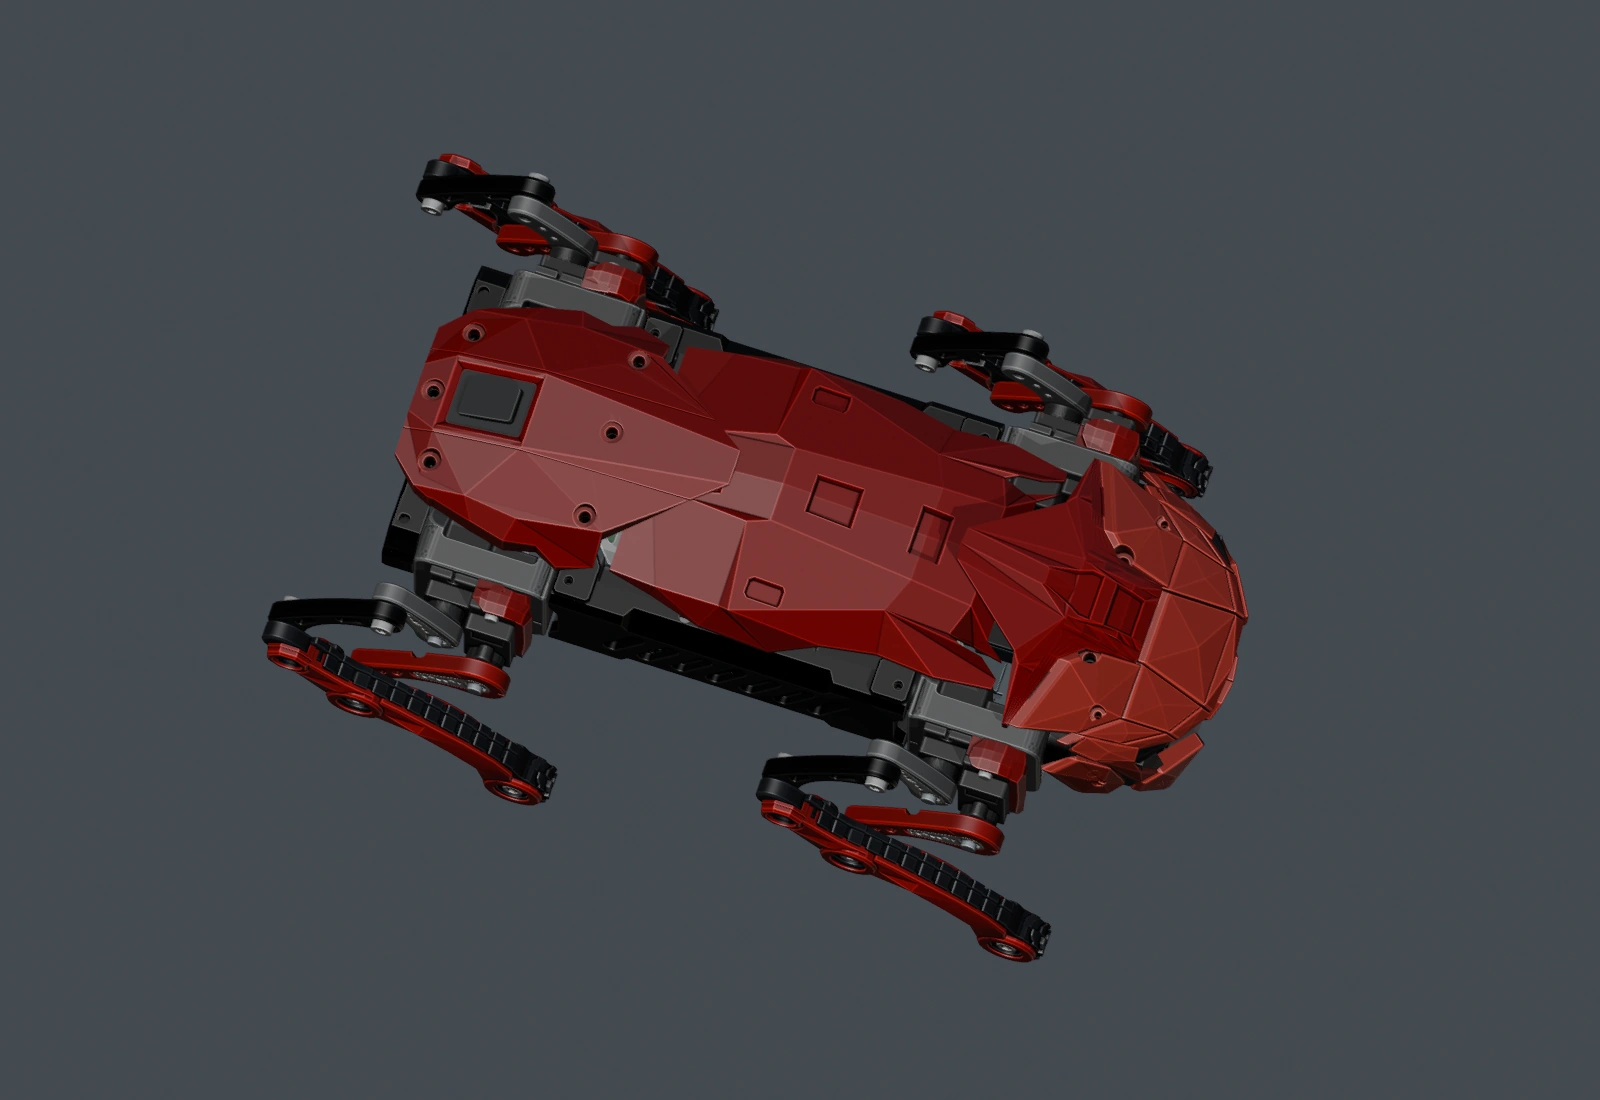
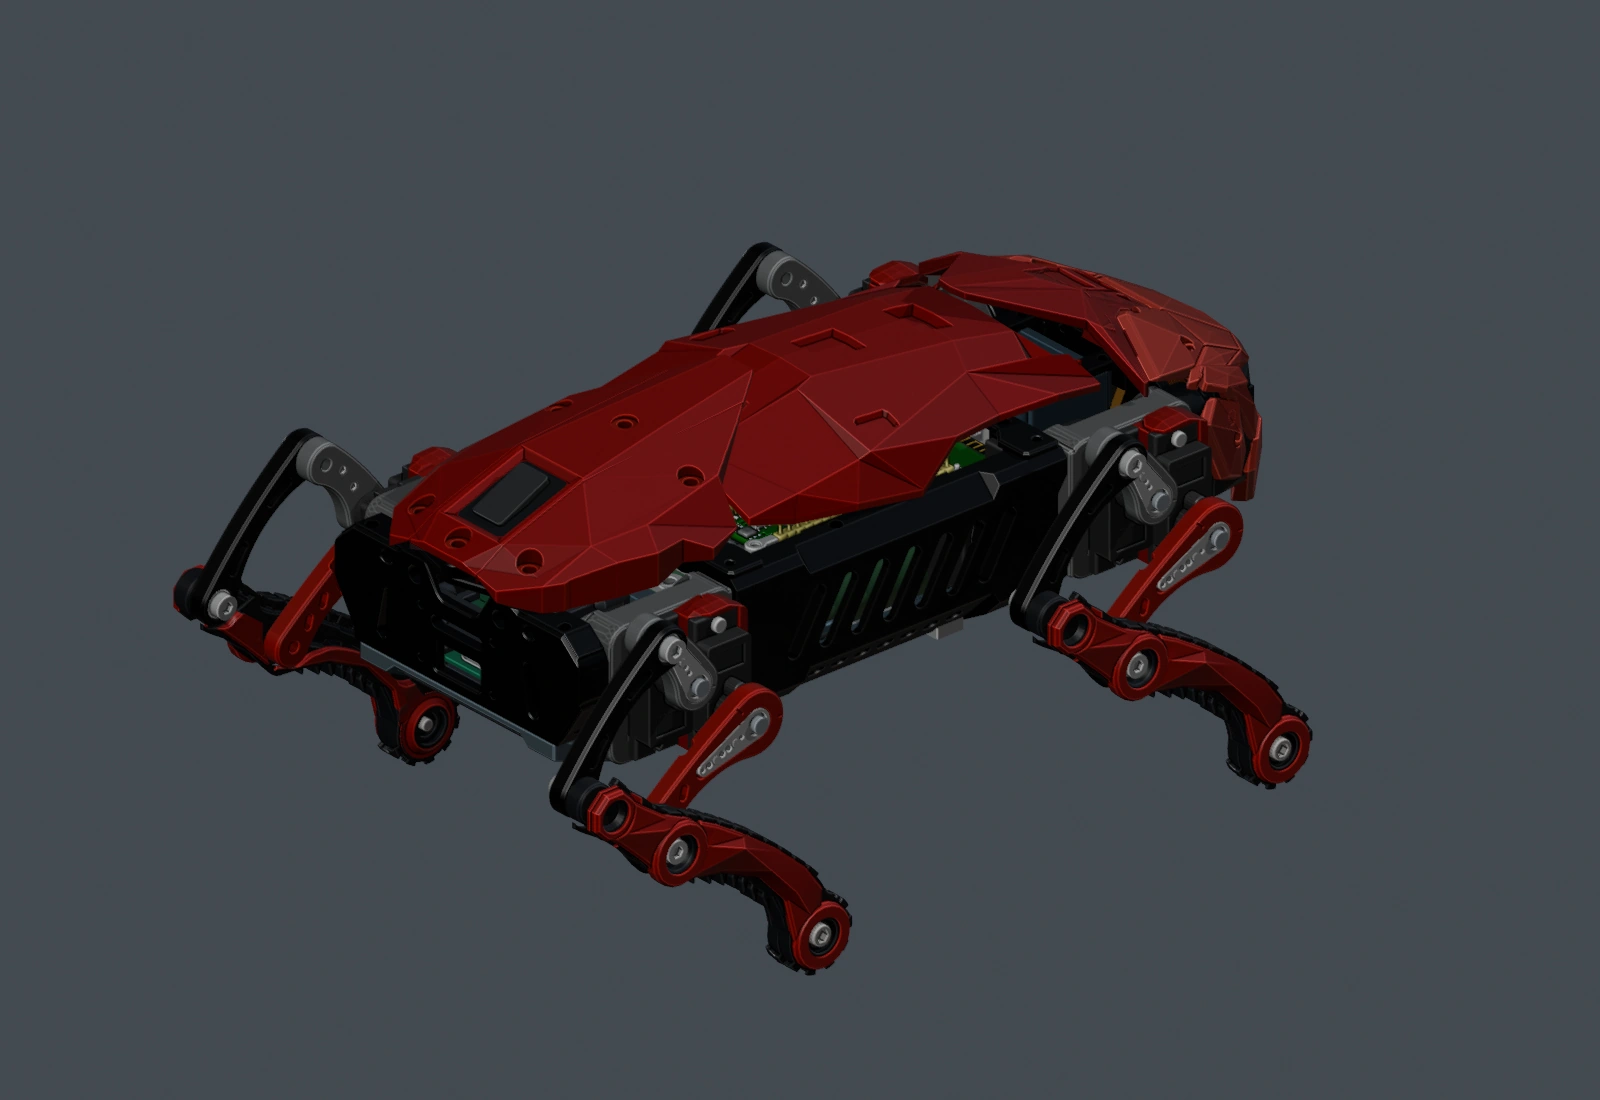
Wireless Blender assembly, neutral stance.
From exposed chassis to shell components
| Build area | October 8 record | October 12 progress |
|---|---|---|
| Exterior | Carapace not attached; exposed wiring in the photograph | Exterior printing has begun; front and rear shell export sets are available locally |
| Weight | Earlier approximately 20% improvement remained an estimate | Further weight reduction; assembled mass not yet measured |
| Power | Batteries and onboard charging boards were the intended replacement for the heavy bank | Switched to a 4 A power supply |
| Camera/display packaging | Camera carrier and longer front tray were local work | Camera cradle, split chin pieces and revised LCD-carrier exports |
| Movement | Standing, walking and command response reported | Local Lay Down / Play Dead entry and recovery paths revised; physical qualification remains separate |
Still to record: supply voltage, rail wiring, current draw, and the final battery arrangement.
Earlier October 10 shell reference
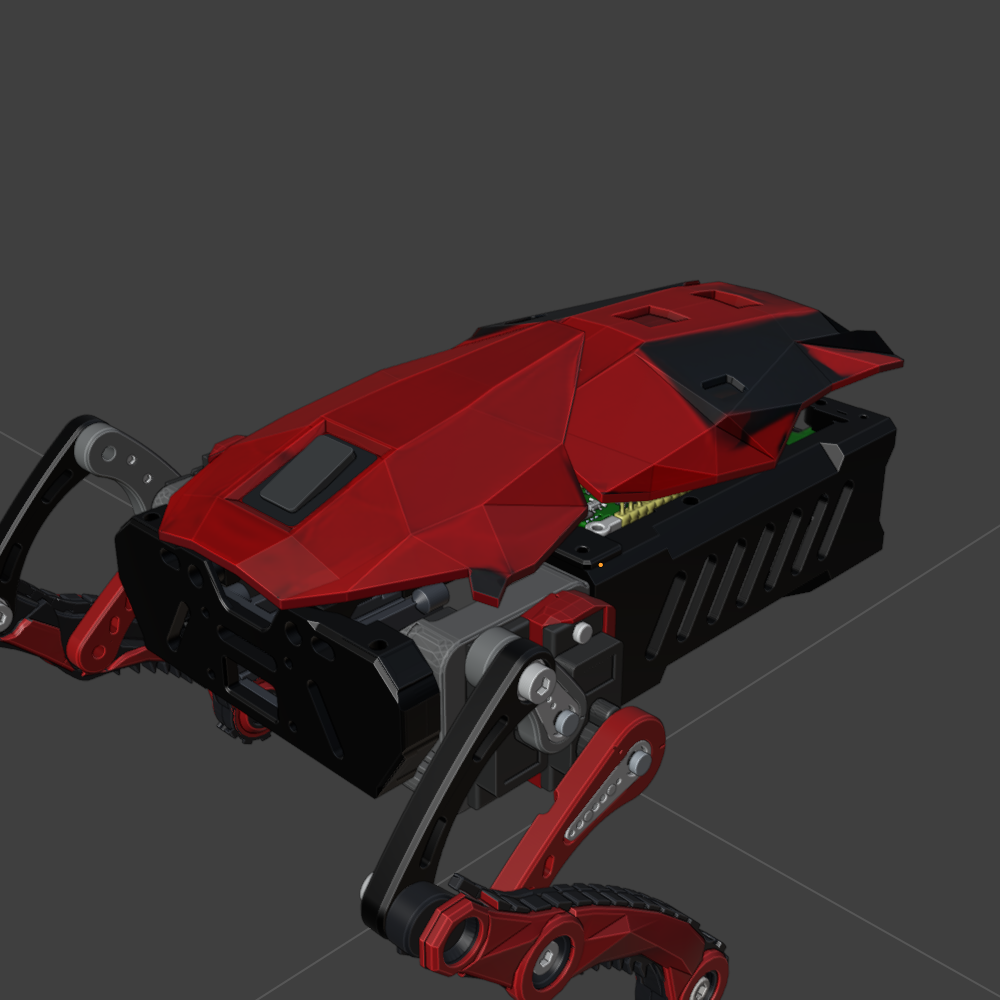
The Blender print record
All modeling is done in Blender. The source folders contain these dated sets:
| Export set | Files in this snapshot | Purpose / iteration |
|---|---|---|
| Front shell | 15 STLs | Upper visor; paired temple, side-shell and cheek-fang pieces; paired side/cheek keys and flush pins |
| Rear compact arch | 8 STLs | Left, center and right arch; front/rear saddles; M3-named rear panel and left/right braces |
| Camera cradle | 4 STLs | Camera cradle, LCD carrier, left chin and right chin |
Download the 27 prototype STLs. October 9–12 exports, including alternative revisions. Mating fit, print settings, and fastener lengths still need checking. File manifest.
The robot repository also has local rear-helmet, rear-visor and updated center support exports. These are separate from the three folder sets in the download.
Lift each foot before lowering the body
The local motion authoring now gives Lay Down and Play Dead individual lift-and-place steps before lowering the body. The generator specifies an 8 mm lift, 0.8 seconds per initial foot placement, then 2 seconds of body lowering. Both sampled clips retain a seven-second authored duration and the original start and terminal references. Runtime speed settings can change playback duration.
The sampled files show a useful reduction in peak joint speed:
| Offline quantity | Lay Down: previous → revised | Play Dead: previous → revised |
|---|---|---|
| Authored duration | 7.0 → 7.0 s | 7.0 → 7.0 s |
| Peak joint speed | 216.36 → 137.59°/s | 308.62 → 156.16°/s |
| Lowest modeled sole height | −0.067 → approximately 0 mm | −0.240 → approximately 0 mm |
| Minimum modeled body clearance | 0.15 → 0.15 mm | 0.15 → 0.15 mm |
| Hardware qualified / collision checked | No / no | No / no |
The P4 source retraces the grounded clip in reverse before entering a new named motion, with a short alignment segment. Hardware testing of this recovery is still pending.
Download the before/after validation data or continue through the gait journal.
The software side of the build
The YOLOE entry follows the move from person-only detection to search and selected targets, including the live chair tracking result and the camera recovery problem. The MetaHuman entry records the trained intent/task split, workflow changes and why a later candidate was rejected.
Sources: October 12 build notes; Blender exports and captures;
local motion source and validation records at Ainekio commit 436c035 plus
uncommitted changes. Exact reviewed hashes are in the
source manifest.
Shell Printing, Weight Changes, and a 4 A Supply
https://ainek.io/posts/2026-10-12-shell-power-and-motion/