Ainekio’s build journal: an eight-servo original and a twelve-servo companion in development, with measured servo feedback, a rebuilt body and learning from real walking.
The rebuilt body: a new face, measured standing and powered continuity
New photographs show Ainekio's revised face and shell. Ground repair, final-pass Stand verification and connection-loss handling improve the body-control foundation.
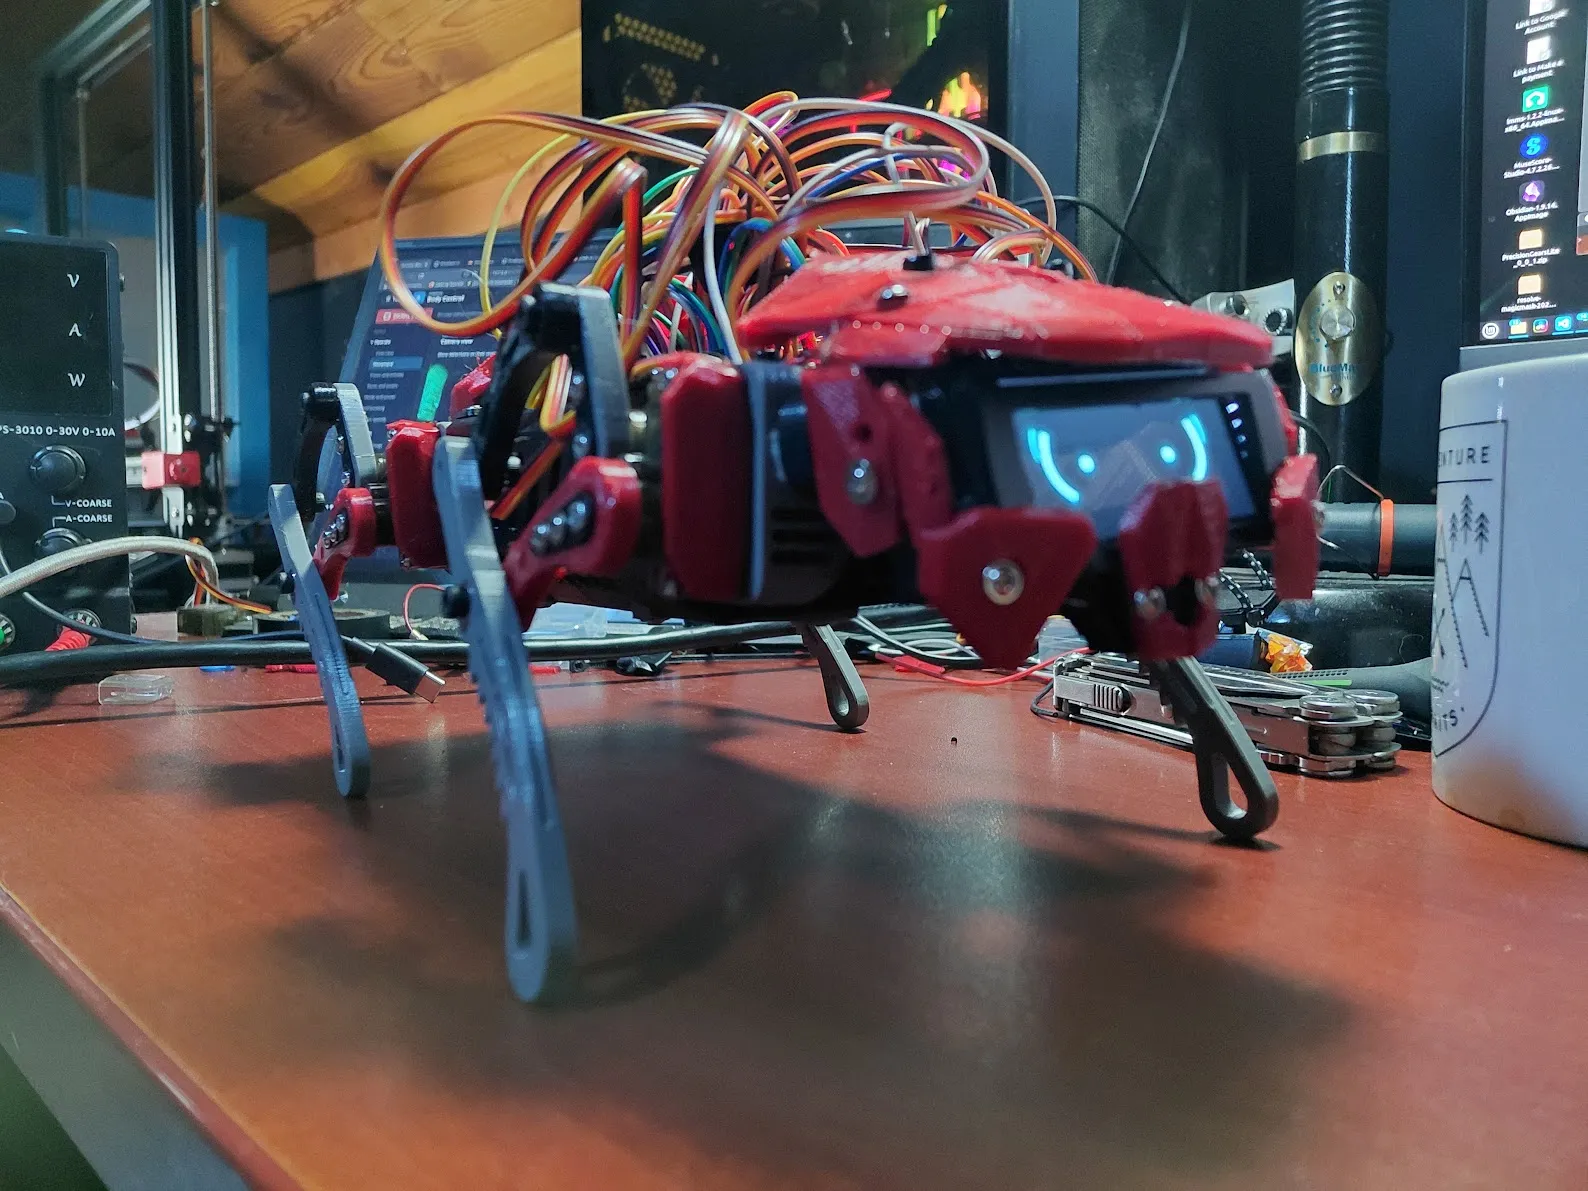
The October 21 photographs show the robot assembled again, with red parts
surrounding its face, four linkage legs and exposed wiring above the body.
The latest design exports include bezel, chin, cheek, temple, side-guard and
rear-shell revisions. The photographs establish the visible assembly; they do
not establish that every exported part has been printed or fit-tested.
The wide color display now uses brighter pupils and swept cyan side lights.
Thinking, listening, speech and motion expressions share the firmware renderer;
Body Control’s previews come from that same renderer.
CAD measurements led to a fifteen-pixel horizontal correction, followed by
layout refinements around the bezel opening. The core face is wider and lower;
small decorative marks were removed or repositioned to keep meaningful features
visible. These are model and pixel-layout checks, with installation records for
the October 20 face revisions. They are not a measured physical alignment tolerance.
Current renderer previews, not recordings of the physical LCD. The photograph above shows the assembled display.
A small precomputed mask supplies the permanent side-light shape while the eyes
and expression elements remain procedural. This reduces repeated geometry work
without storing complete animation frames. Desktop timing improved in an earlier
layout comparison; the latest layout has not been remeasured on the P4, so those
desktop numbers are not a robot CPU-performance claim.
Standing uses a completed movement and its actual result#
The Stand implementation changed substantially after the feedback-servo rebuild.
The October 20 Stand revision executes complete authored movement passes and
checks the final target when verification is enabled. That revision also removed
intermediate joint-arrival waits from named motions, custom sequences and recovery
paths. The newer, not-yet-qualified gesture executor is described separately below.
Valid measured shortfalls can select another corrective stepping pass toward
the same standing goal. Holding and initial completion share that goal’s
comparison instead of independent mechanisms disagreeing and releasing the
supporting servos. Stop, replacement movement and calibration retain their
existing ownership.
Feedback quality proved just as important as planner logic. During one failure,
the robot was visibly standing while the analog readings were near or below
their calibration minima. After the owner repaired a ground fault, distinct
joint readings returned.
On October 20, Stand verification was temporarily enabled with the existing
400 µs arrival tolerance. The command completed with measured verification.
Across 65 subsequent snapshots over 19.22 seconds, all twelve joints remained
inside that configured tolerance; the largest absolute filtered error was
175.74 µs. No corrective replans or output faults occurred.
The owner confirmed that the robot stood correctly and remained steady without
the previous jerking. This validates that particular Stand-and-hold trial.
It does not qualify obstruction recovery or prove long-term standing stability.
The original saved settings—Stand verification off and jam protection off—were
restored afterward.
Missing feedback does not mean successful arrival#
The subsequent installed firmware distinguishes completing an authored
trajectory from verifying the resulting position. If post-command readings are
unavailable, it can finish the movement, retain powered targets and return
position not verified. It does not invent arrival or treat an unusable
signal as proof of a jam. Usable observations can resume measured correction.
Body Control exposes feedback health and fourth-wire millivolts and can send
fault/restoration notices through the existing event bridge. Those notices do
not issue a stop or release. The fourth wire is a position signal; the hardware
still does not measure servo-rail voltage, motor current or temperature.
Earlier connection-loss handling could disable the PCA9685 directly and drop
powered supports. The 0.8.113 installation record confirms the revised local
motion ownership is on the robot: finite motions continue, while an open-ended
gait receives its existing graceful Finish request and retains its final powered
hold. Reconnection does not replay stale commands or invent missing results.
Native checks cover finite motion and continuous-gait loss, including separation
between old and new sessions. Installation and boot are recorded; a deliberate
physical disconnect-under-motion test remains outstanding.
The combined image also includes revised gesture timing: travel follows joint
distance at the configured speed while intentional holds retain their authored
timing. Installation alone does not qualify every gesture’s clearance or behavior.
The inspected 0.8.115 working tree adds an arrival-aware player for named
gestures. Travel uses half the configured joint speed, with final-approach
deceleration for Sit, Rest and Crouch; authored repetitions and holds are retained.
It writes each target and checks calibrated feedback before advancing
or consuming the following hold. Time spent reaching a target does not consume
the next movement or its intended pause. Terminal completion follows measured
arrival; missing or untrusted feedback keeps the current target commanded and
reports waiting. Stop and replacement commands remain available asynchronously.
This changes gesture sequencing relative to the October 20 intermediate-wait
removal. The gesture documentation records simulated-lag checks, while physical
acceptance and installation of this revision are not established by the reviewed
records. It must not be presented as the behavior already demonstrated on 0.8.113.
Configurable rest is prepared, not yet verified on the robot#
A newer source/build feature adds Lay down after inactivity in Body Control’s
Mode and power section. Its initial default is three minutes; zero disables it.
The robot owns the saved setting. Active motion and speech defer rest, and the
normal Lay Down retains powered outputs and accepts new commands.
The October 20 record explicitly leaves installation and the physical three-minute
observation pending. It is separate from MetaHuman’s Semi Auto inactivity setting.
The inspected source has advanced to 0.8.115-p4-gesture-arrival; the latest
installation confirmed by the reviewed journal is 0.8.113-p4-link-motion.
A source version is not proof of a newly flashed image.
The source snapshot records the gait
journal, face documentation, firmware owners and twenty-three local prototype
exports inspected for this update. Current status
keeps installed, tested and pending work separate.
The rebuilt body: a new face, measured standing and powered continuity