V1 + V2Build reference
Ainekio: Project Overview
Meet Ainekio, a robot familiar combining conversation, personality, memory, perception and physical action, with two body designs and a continuing build journal.
Published Updated 5 min read
Ainekio
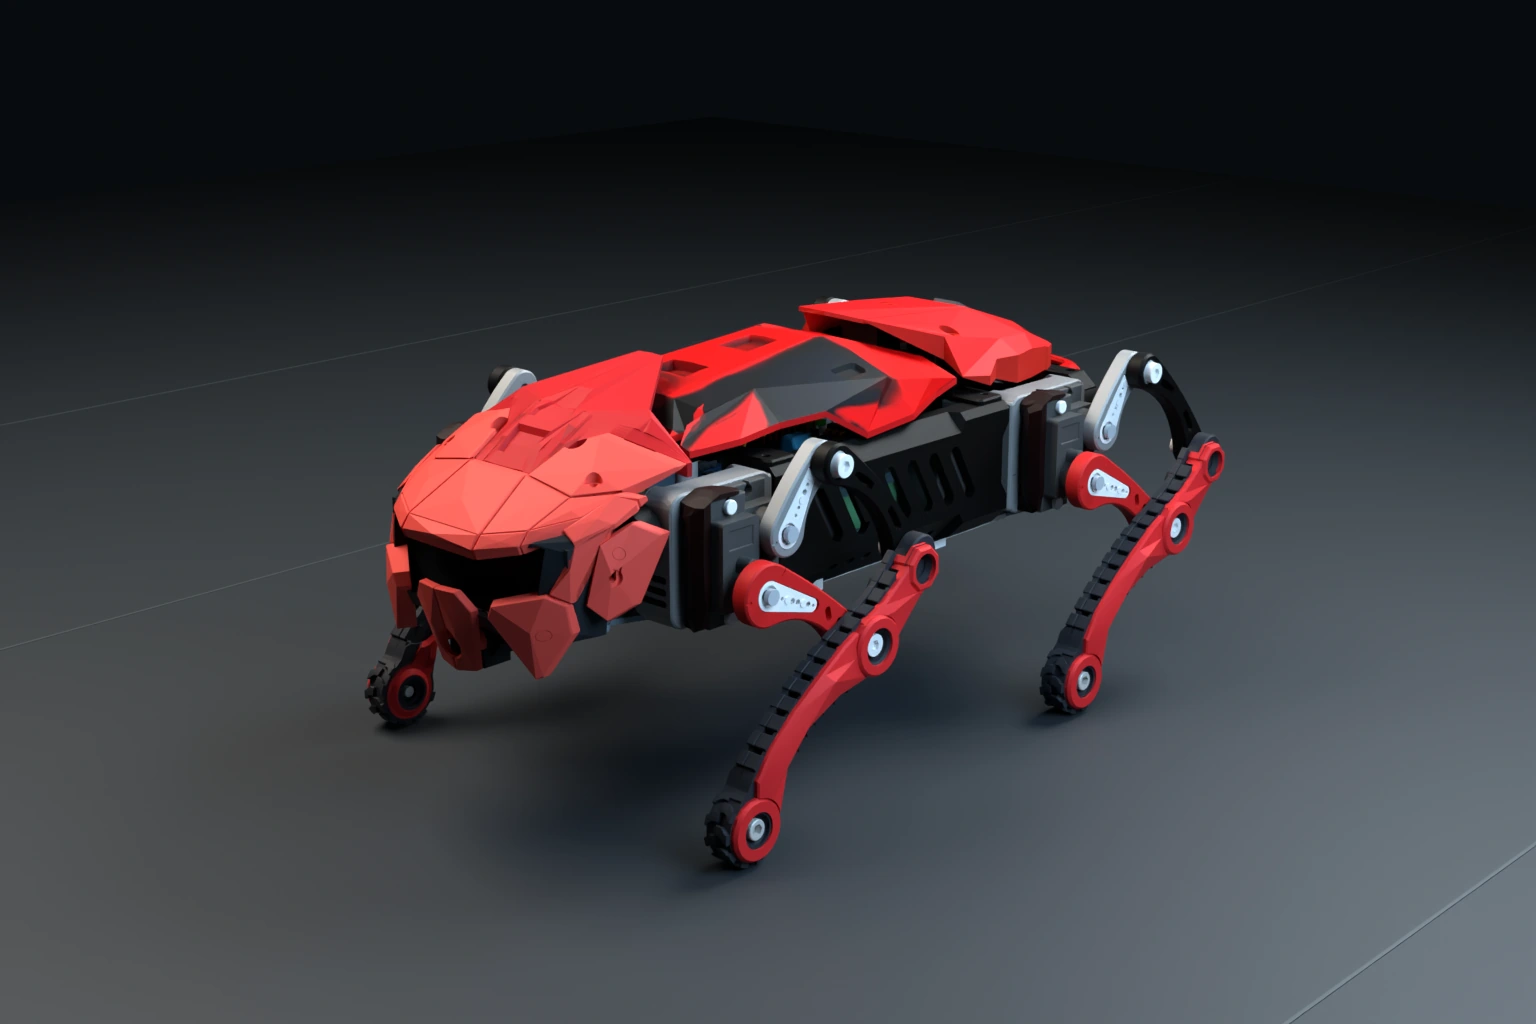
Ainekio is my four-legged robot familiar project. The body has a camera, microphone, speaker, and display. MetaHuman OS handles conversation, memory, perception, and task planning; the body controller handles motors and movement limits.
Project intent
Ainekio is being built as a persistent companion with a recognizable personality and continuity between interactions. The aim is to converse, notice the surroundings, remember useful experiences, express itself, choose activities and improve through reviewed learning. A request should carry through actions and corrections without losing its objective.
Understanding the companion
| Function | Its part in Ainekio |
|---|---|
| Conversation and personality | A consistent identity, with words and expression appropriate to the situation |
| Perception and expression | Camera, listening and body sensing connected to speech, faces and supported movement |
| Memory | Recent context and longer-term experiences that can inform later interactions |
| Goals and autonomy | Respond to requests, act on configured triggers, or choose and pursue activities according to the selected mode |
| Inner activity | Reflection, dreams, daydreams and curiosity, retained as internal content with its origin identified |
| Learning | Review experience and corrections, train specialist skills or conversational personality, then evaluate the changes |
These describe the intended connected experience. Components are implemented and under test, but reliable recall, sustained autonomy and the complete learning loop remain unfinished. Meet Ainekio as a companion for a plain-language explanation of how the functions fit together; the status page records the latest results.
The two builds
| Original V1 | Current V2 | |
|---|---|---|
| Servos | Eight MG90S; two per leg | Twelve; three per leg |
| Controller | ESP32-S3 | ESP32-P4 |
| Mechanics | Sesame-derived body | Redesigned chassis and compact linkages with sideways leg placement |
| Motion | Scripted poses and sequences | Freestyle-generated targets, measured arrival, shared gait solver and a retained manual motion library |
V1 remains supported. Design history and V1/V2 comparison.
October 27
Finite motion and recovery: a new workstation model runs each program once, with actual body events handling recovery. A supported stretch verified all nine targets. Generic stretch calibration, release choices and physical recovery remain in development.
October 26
- Freestyle motion training: editable examples, compact Q6A inference, measured shaft arrival and the latest Stand model’s results.
- Body, power and training stand: 650 g assembled mass, 2S battery/charger packaging, current linkage dimensions and downloadable stand parts.
- MetaHuman continuity: existing intentions and results stay connected; live Full Auto trials still stop short of sustained initiative.
Individual lift and sway corrections passed review. Reliable loaded standing, floor walking and autonomous activity remain the next experiments.
October 21
- Learning from real walking: loaded comparisons, host recording and optimization, separate Walk/Run policies, experimental visual progress and navigable learning history.
- The rebuilt body: new face/shell photographs, a successful ground-repair Stand trial, final-pass feedback and powered motion continuity.
- Faster reactions and recovery: a dedicated one-call tip/shake workflow, motion-aware events and repaired completion/reconnect behavior.
Walking quality, camera distance accuracy, grounded interpretation and reliable recall remain under development. The gallery now includes three October 21 photographs of the assembled robot.
October 18
- Feedback servos and a revised chassis: twelve modified servos and a multiplexer provide measured position alongside PWM commands. Calibration is complete; loaded standing and walking still need qualification.
- MetaHuman models and execution: trained 2B specialists, experimental 9B autonomy, activated monitor and task repairs, and current vision/recall limitations.
- See the robot: real photographs and videos, with dated CAD and motion studies clearly separated from the physical build.
October 15
- Companion systems: shared model categories, Active Operator, attributed memory, evidence-aware Desire review and a single Persona reply owner.
- Locomotion goals: distance, turn, approach, follow and visual endpoints use measured progress and the same gait’s Finish result; signed lateral support is installed, with physical accuracy still unqualified.
- Motion and leveling: revised Walk, Run, Crawl, Crab and seated Wave; level-reference, per-leg feedback and stationary gyro calibration controls. Installation is recorded through 0.8.52.
- 9B learning diagnostics: independent autonomy and persona fits completed; neither qualified for production after actual serving comparisons.
Task no longer inserts spoken steps between movements. Persona supplies the outward reply using selected task results. Grounded autonomous outcomes, reliable dream recall and loaded performance of the revised motions remain open.
October 14
- Body events: wake, tilt and rapid movement reach a dedicated model workflow; thresholds and the rapid-event interval are editable in Body Control.
- Startup and self-leveling: staged rise, saved response controls, a geometry calculator, and the October 13 report of 566 g at 5 V.
- Recording and Wi-Fi maintenance: SD video, downloads, staged firmware updates and robot logs, with a successful short controller run.
- Task model qualification: two candidates were tested against the earlier speech-step contract and were not deployed. The October 15 report records the subsequent contract revision.
Reliable wake/stretch behavior and loaded self-leveling are still unfinished.
October 12
I have begun printing the exterior shell, made further weight modifications, and switched to a 4 A power supply. Current work:
- Shell, power, and motion: Blender revisions, 27 prototype STLs, and revised Lay Down / Play Dead foot placement.
- YOLOE tracking: a stationary chair retained one track across eight frames; camera-stream recovery still needs work.
- Trained specialists: Qwen 0.8B intent/task models, node workflows, and a rejected goal-planning candidate.
The lighter robot stood, walked, and responded to commands on October 8. The build photograph shows it without the carapace. Later Active Operator component checks are recorded in the October 15 report; complete autonomous behavior remains unqualified. The roughly 20% weight and lifting-force improvements from the rebuild are estimates. The later owner-reported mass is 566 g; loaded gait performance and endurance still need measurement.
I dropped the heavy 10,000 mAh battery bank on October 6 in favor of separate batteries and charging boards. The final battery arrangement is still open.
Wired and wireless
Wireless is the current priority: Q6A offboard over Wi-Fi. Wired keeps the Q6A on the robot with a native USB connection to the P4.
The P4 now supplies live IMU evidence and configurable local balance correction. Loaded leveling and the robot ROS 2 adapter remain unqualified. A dated short Wi-Fi recovery run passed; sustained wireless reliability still needs testing.
Command path
- MetaHuman’s Work Coordinator admits the request and selects a supported action.
- The Environment Bridge passes it through Ainekio’s adapter and authenticated gateway.
- The controller checks movement limits and executes the command.
- Results return to MetaHuman’s task workflow.
Workflows retain requests, corrections, and results across waits and restarts. Gateway recovery reconnects delayed results to their original command without repeating movement. The September live run exposed stale goals; subsequent repairs have controlled-test coverage and still need connected-system testing.
Build notes
- Gait journal: geometry, ranges, motion data, and walking experiments.
- V2 parts and assembly: component revisions, print exports, and prototype photos.
- V1 hardware and S3 firmware.
- MetaHuman integration, autonomy, vision, and voice.
- Current status and development tracker.
V1 began with Sesame; V2 began by evaluating OpenHarmony Puppy leg geometry. The unsuccessful simulator experiment is retired; its July notes remain in the journal.
Ainekio: Project Overview
https://ainek.io/posts/project-overview/